

Investors & partners
Evidence before scale.
Baoqi Smart develops predictive decision intelligence for affordable, heterogeneous autonomous defense systems.
Product scope and evidence navigation. These figures are not revenue, customer or field-performance KPIs.
Inspect the evidence
Review the software.
Eight public scenarios explore one coordination architecture.
The entry point
Start with three.
One operator. Three affordable aircraft. A bounded path from software to hardware.
Coordinate different capabilities while accounting for mission value, cost, risk and replacement.
- Observe
- Allocate
- Reassign
- Review
Coordination is the product.
- Heterogeneous assets, shared mission roles
- Cost-aware allocation and reassignment
- Replayable decisions and human authority
Commercial direction: partner qualification and bounded integration pilots.
Inspect the decision workflow
STAGE 01
Capability PassportNormalizes what each available asset can currently do.
STAGE 02
Mission UtilityScores capability, time, cost, risk, health, endurance and link state.
STAGE 03
Role AssignmentForms mission teams from heterogeneous assets.
STAGE 04
Dynamic Re-planReallocates work after vehicle or communications failure.
STAGE 05
Evidence ReplayPreserves why decisions were made and allows deterministic review.
Proposed 90-day POC
Prove the next step.
Agree the platform, scope and acceptance criteria with an integration partner before starting.
Software evidence
- Public simulator and fixed-seed replay
- Heterogeneous fleet modeling
- Failure injection and role reassignment
- Benchmark and decision-event records
Three-aircraft integration
- Autopilot and edge-runtime integration
- Software- and hardware-in-the-loop checks
- Bounded physical-vehicle validation
- Documented review against agreed criteria
The POC is a proposed engagement, not a completed trial or guaranteed delivery. No physical flight or field-performance result is claimed here.
Current scope and planned engineering work
WORKING TODAY
- Deterministic simulator, public, no login
- Fixed-seed repeatability
- Heterogeneous fleet modeling, UAV and UGV
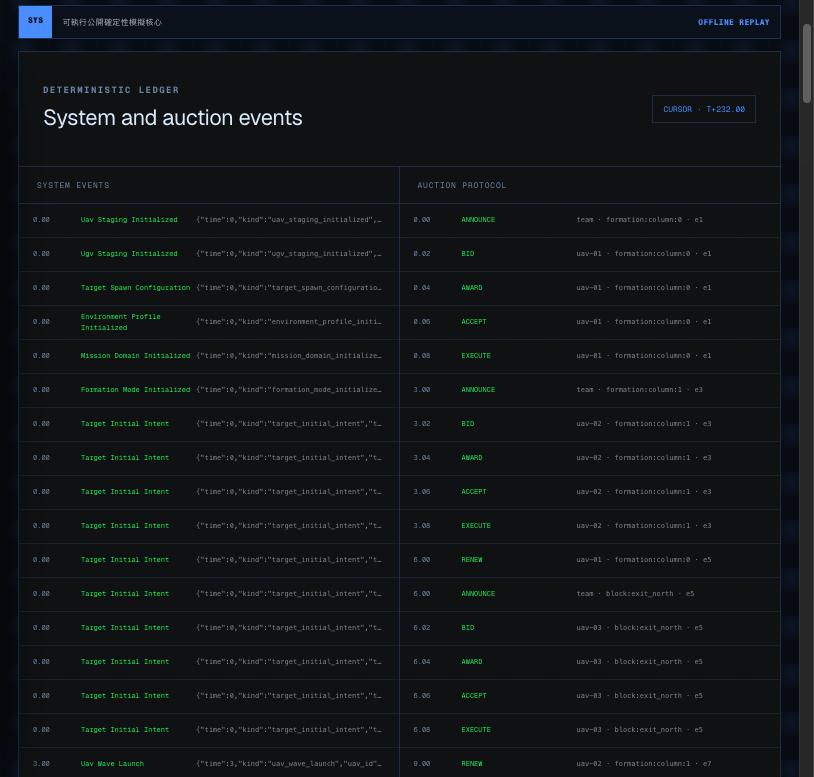
- Mission-role assignment via an explicit auction protocol
- Failure injection and N-1 replanning
- Replayable decision evidence
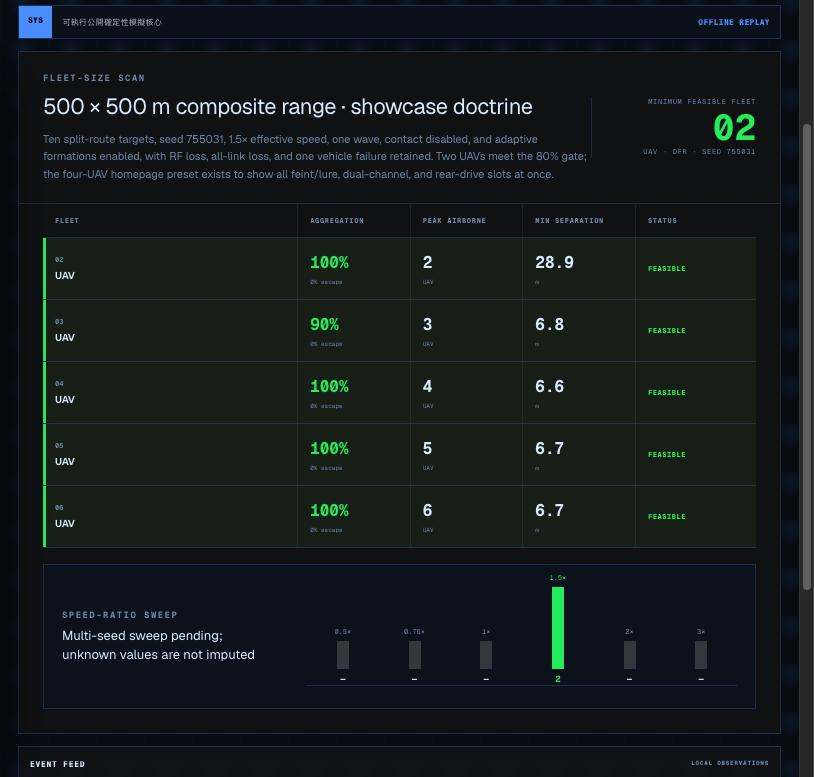
- Benchmark harness with fleet-size scan
- Deployed on Google Cloud Run
WHAT THIS ROUND FUNDS
- Integration with two autopilot stacks
- Software-in-the-loop (SIL)
- Hardware-in-the-loop (HIL)
- ARM / Jetson edge runtime
- Two to three physical vehicles
- Authorized field validation
- A robotics / autonomy technical cofounder
Valuation, terms and cap table are discussed directly.
Execution & team
Built on shipped software.
AI workflows
Customer operations with explicit human approval and a shared production core.
Operational memory
Structured interviews, retrieval and personal digital-twin workflows.
Wenteng Chang
Founder-led R&D, product architecture and partner development.
Previous deployments and founder background
CHATPRESS · IN OPERATION
Multi-tenant AI-native operating layer: shared core, workflow engine, explicit human-approval gate, Customer 360 record, live customer-facing use.
TWINS · IN PILOT
Personal digital-twin system built on behavioural interview data, structured positions, memory retrieval and style adaptation.
DEPLOYMENTS
Ninja Taiwan Academy and YizongTW run on the shared production core as real operating businesses.
Baoqi Smart Technology is a lean, founder-led R&D company with a sole founder. Wenteng leads product definition, system architecture, prototyping, validation design, commercialization and partner development. Background spans semiconductor, networking and product management, computer-vision products, and founding and operating a physical training academy. We are actively recruiting a robotics / autonomy technical cofounder.
Validation boundary
Claims you can inspect.
Current evidence is software simulation. Physical integration, certification and field deployment remain separate validation steps.
Engineering scope and validation boundaries
- SHEEPDOG has no combat history and no field deployment.
- There is no regulatory or defence certification.
- SIL, HIL and physical vehicle integration are not built yet.
- SKY MECH has a supplier-reviewable P0 CAD and fabrication package, but has not been fabricated, flown, or validated. SKY MESH multi-node operations remain a modeled concept.
- LLMs are not used as an unconstrained real-time flight-control loop; the digital-twin core is advisory only, with no motor or actuator command path.