

SKY MECH / SKY MESH
Altitude is a resource you can pre-position.
SKY MECH P0 is a 6.0 m tethered helium prototype combining an external load harness, four nominal 100 W solar modules, serviceable sensor/relay pods, and two foldable visible-light observation gliders. Multiple nodes are intended to form a distributed SKY MESH coordinated by SHEEPDOG.
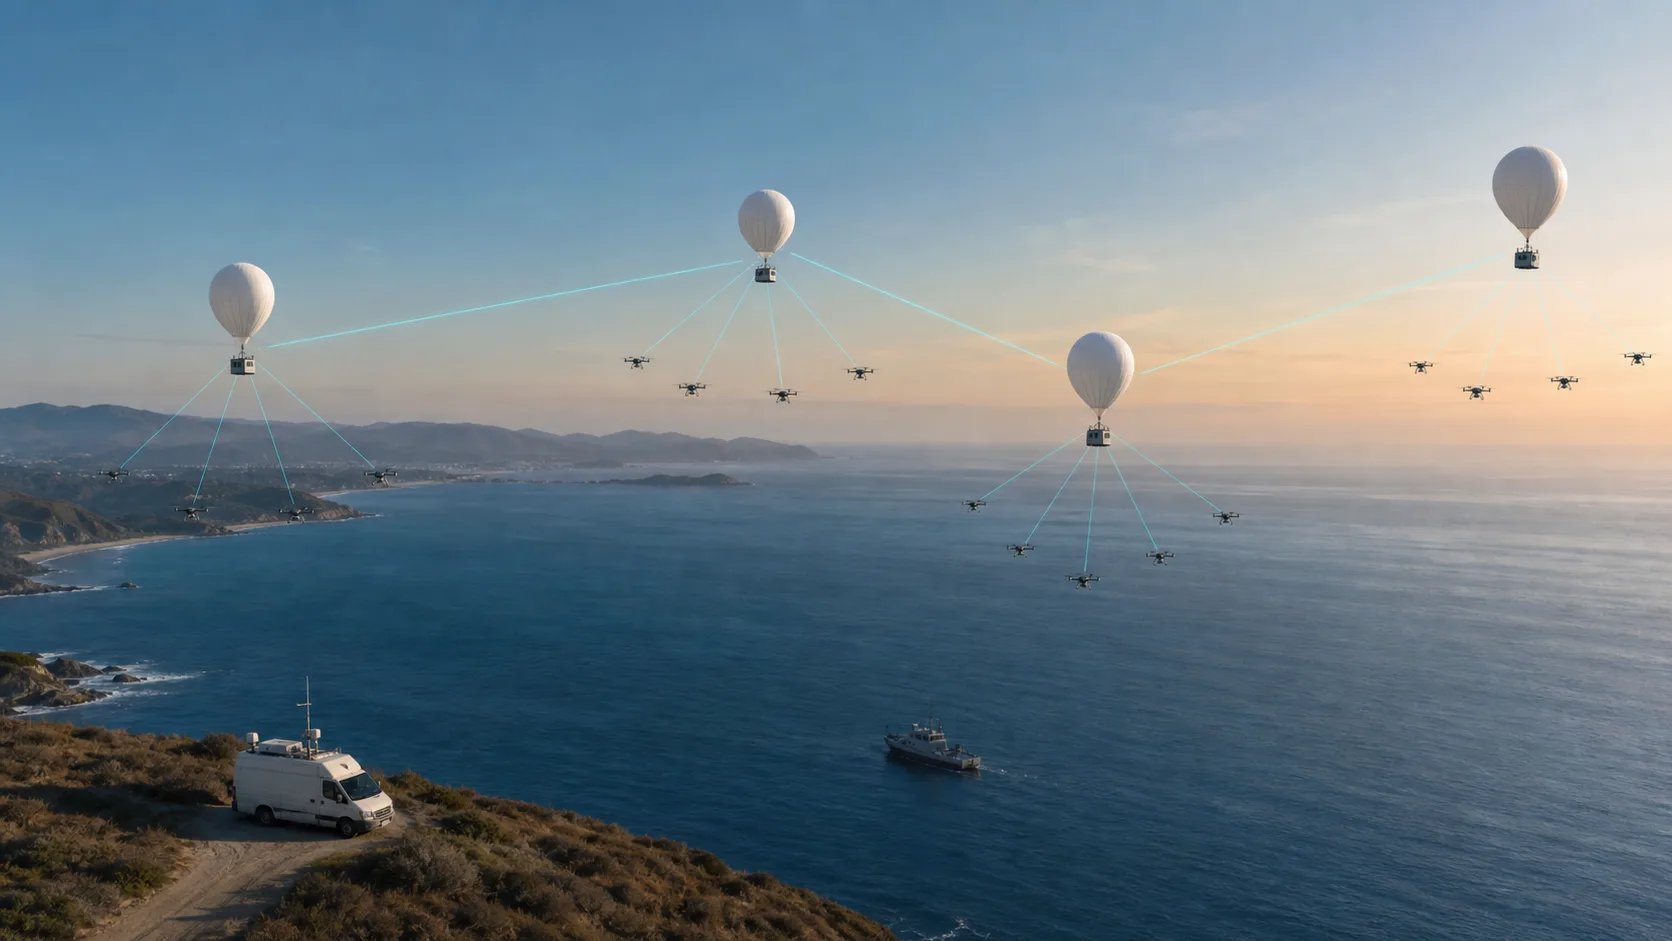
P0 prototype fabrication release
Not a render. A traceable prototype fabrication package.
The P0 release turns the SKY MECH node into supplier-reviewable geometry: 10 A3 drawing sheets, 9 DXF cutting files, 13 STEP geometry re-import checks and a 35-line BOM. It is intended for RFQ, first-article discussion and controlled tethered proof-of-concept work.
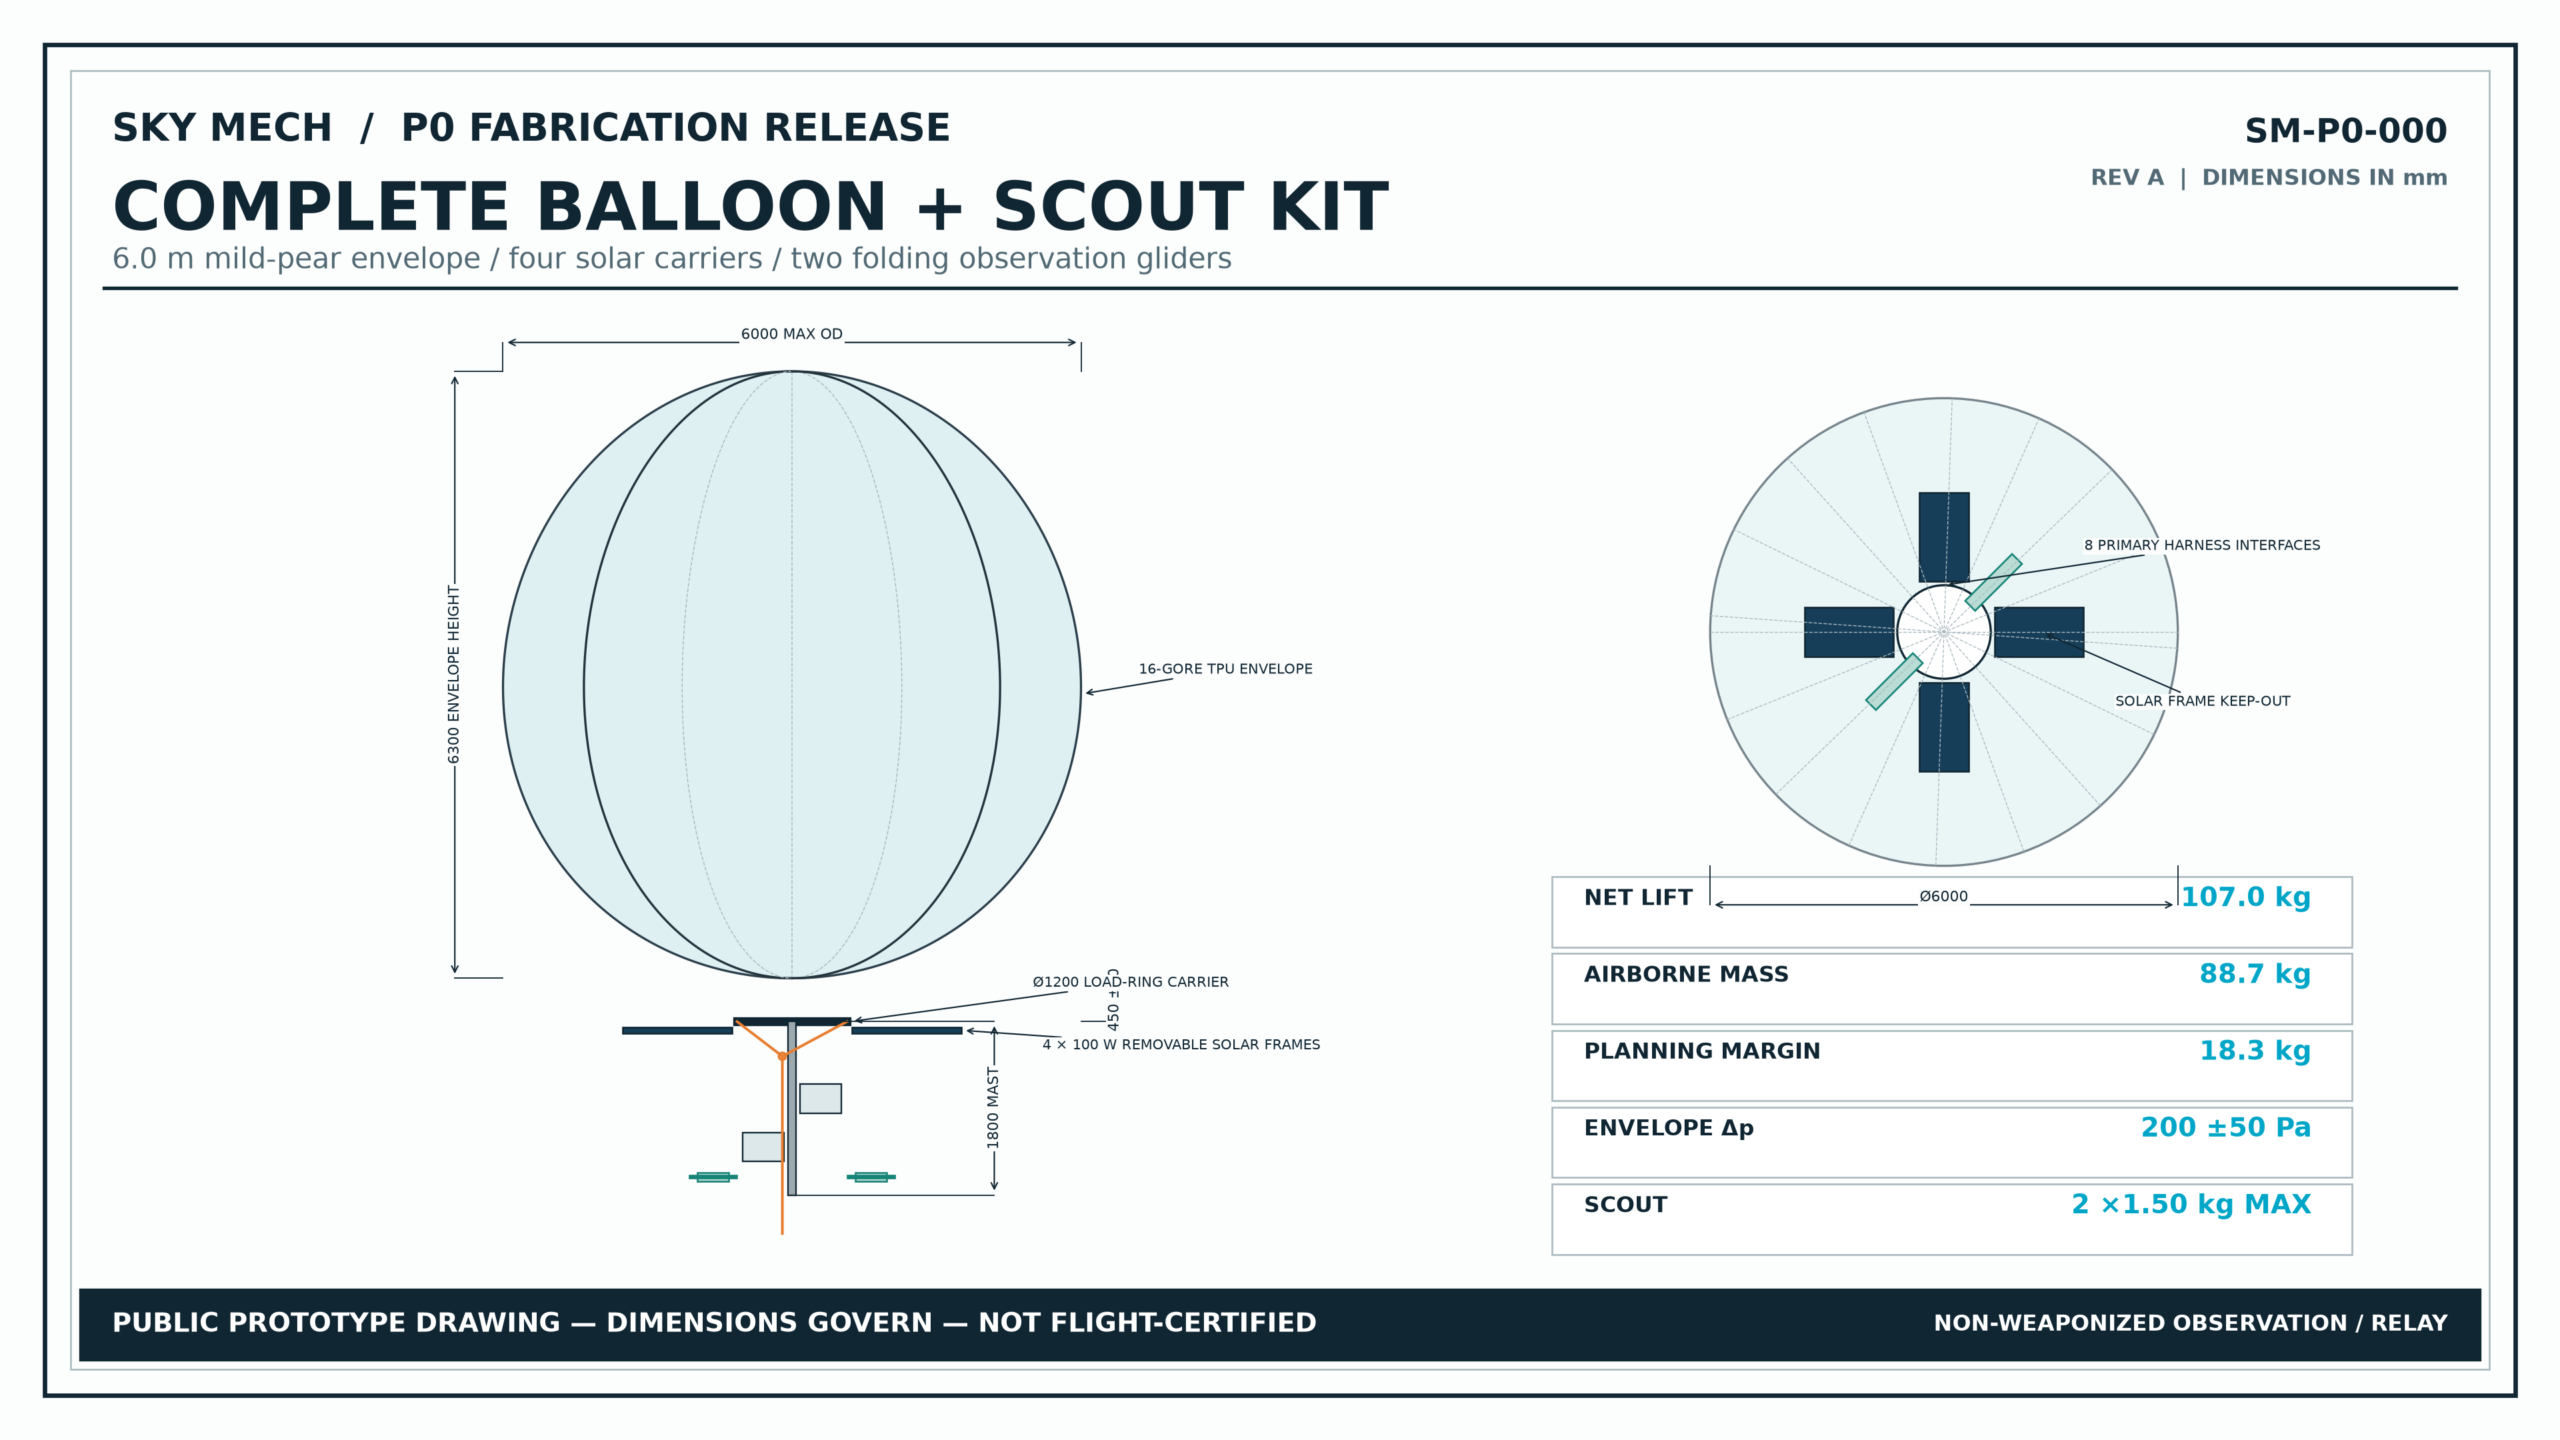
Complete balloon + scout kit
6.0 m tethered envelope, external load harness, serviceable pods, four nominal 100 W solar modules and two foldable observation gliders.
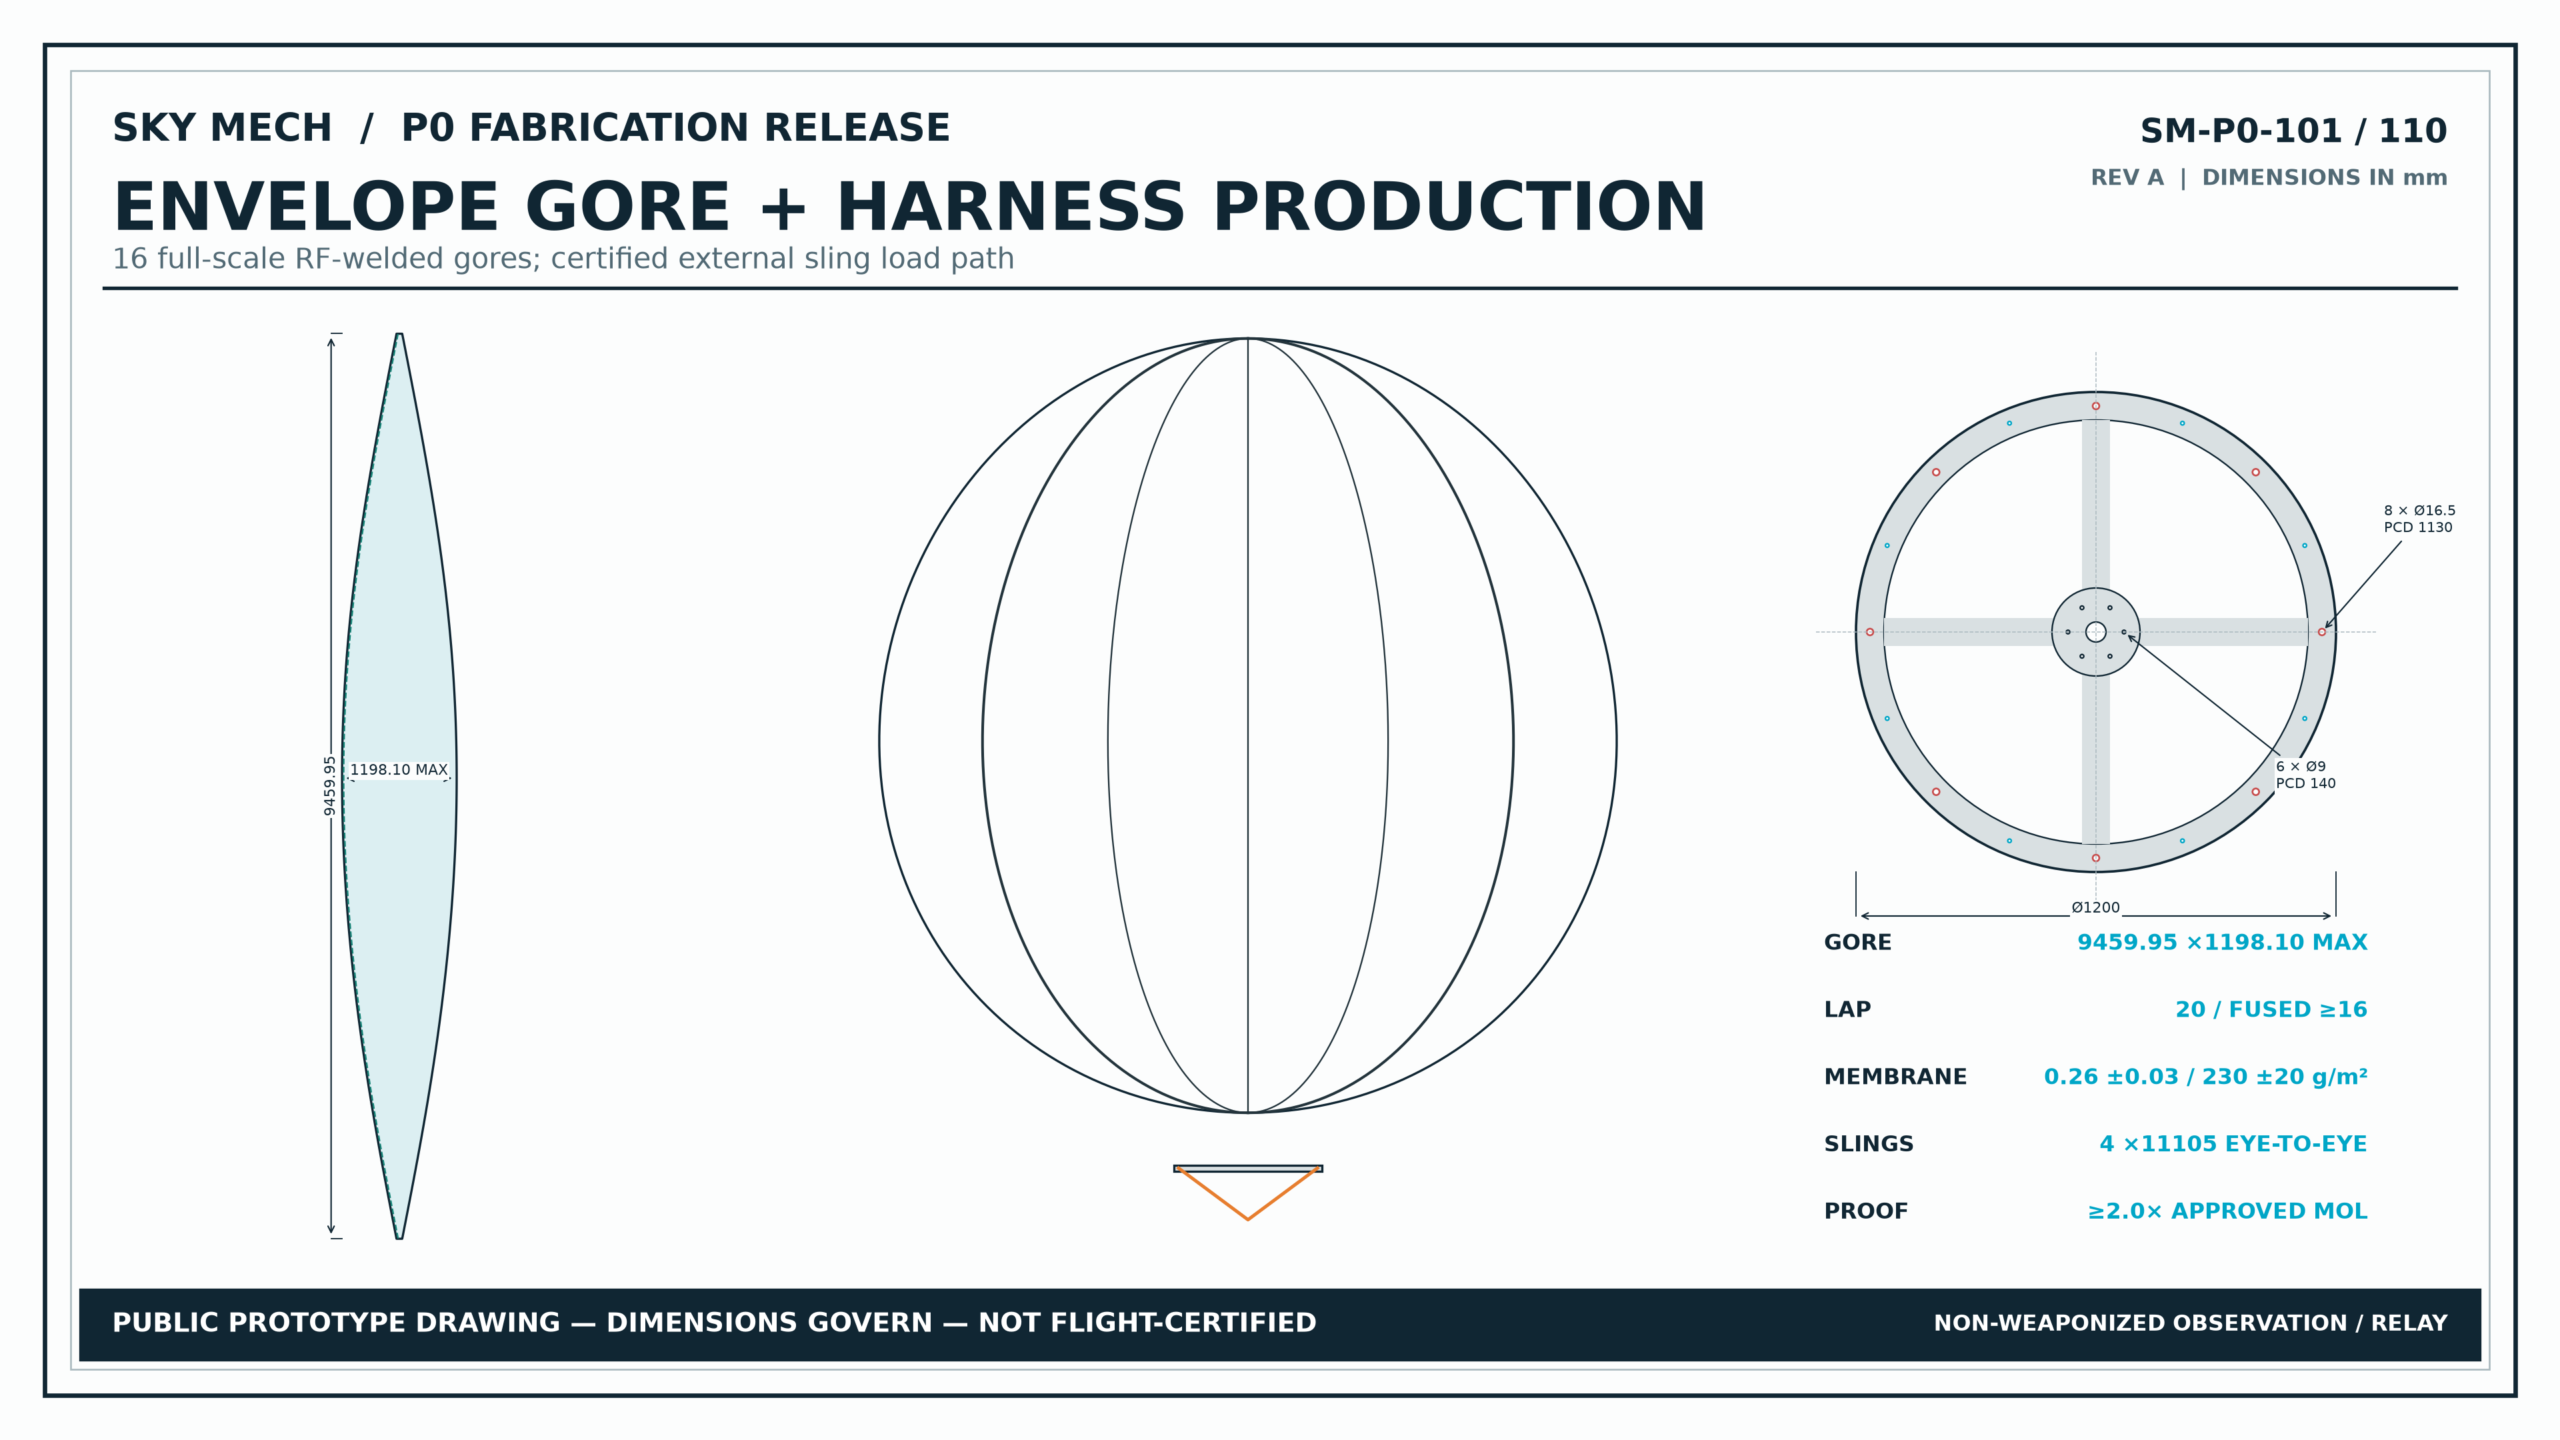
Cut patterns and load paths
Sixteen full-size gores, 20 mm RF seam allowance, interface reinforcement and an eight-leg external harness route.
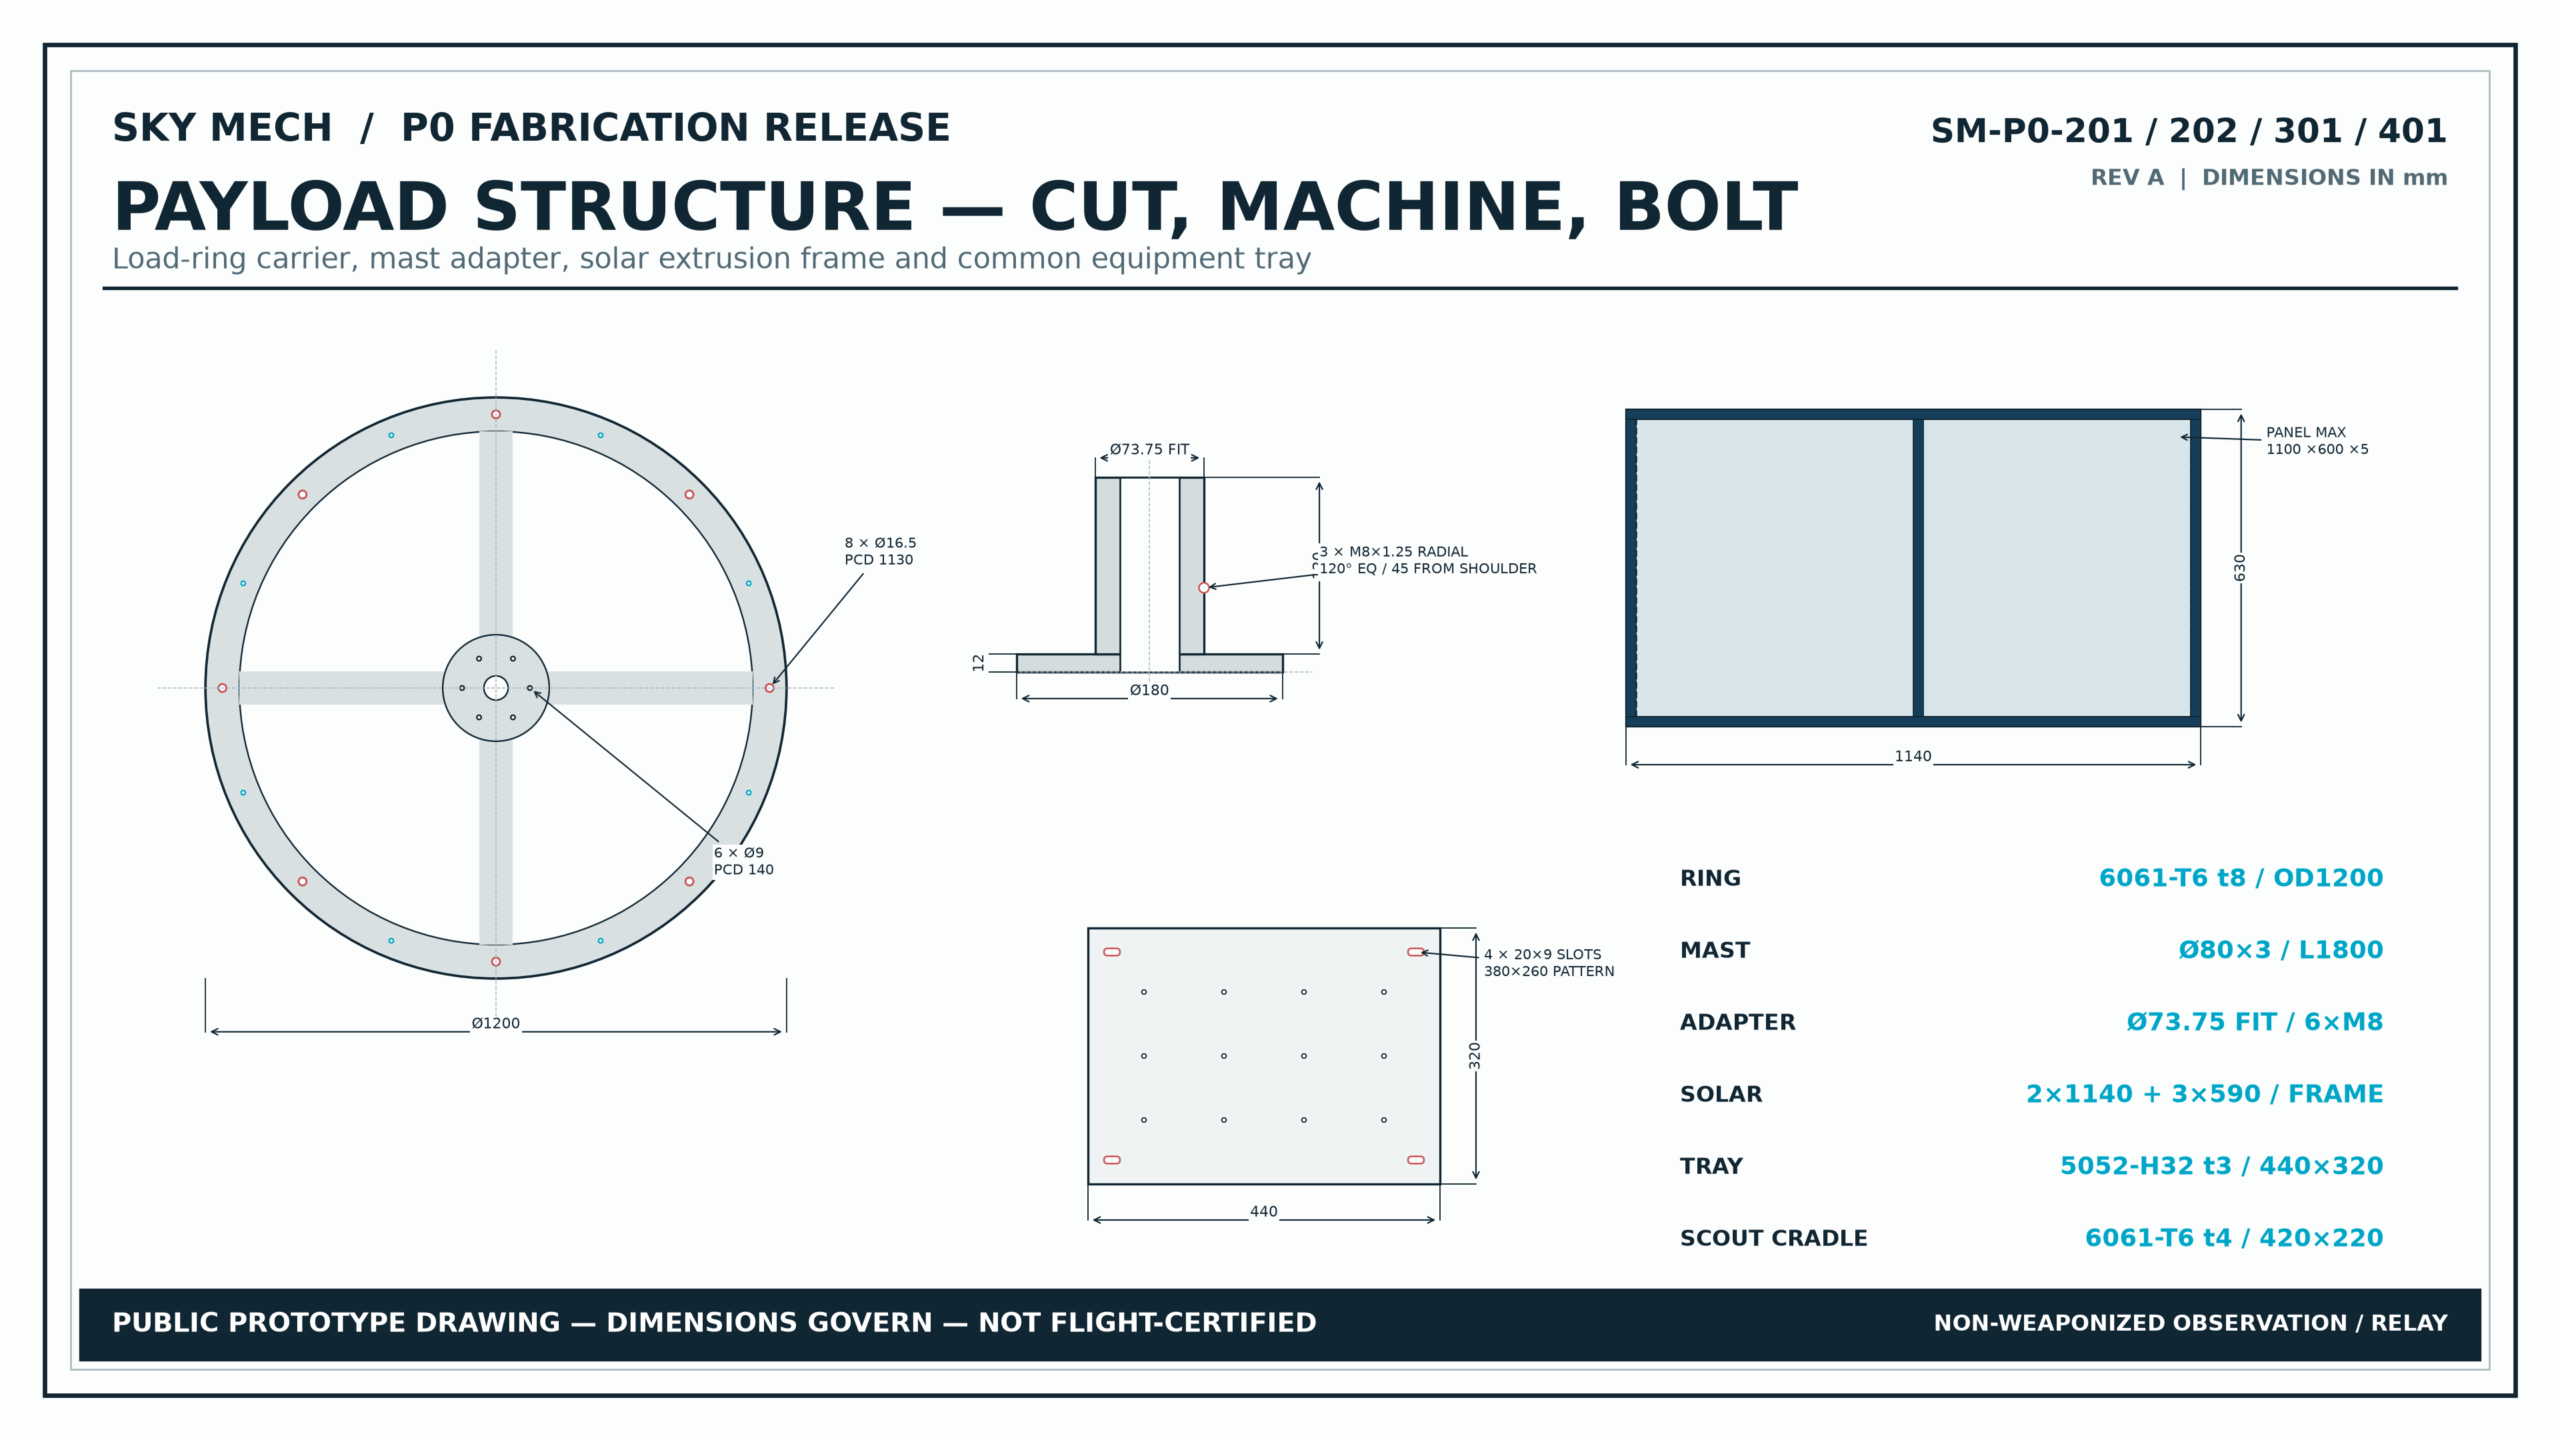
Replaceable structure and power carrier
Ø1200 mm 6061-T6 ring geometry, Ø80 × 3 mm center mast, modular payload interfaces and four removable solar carriers.
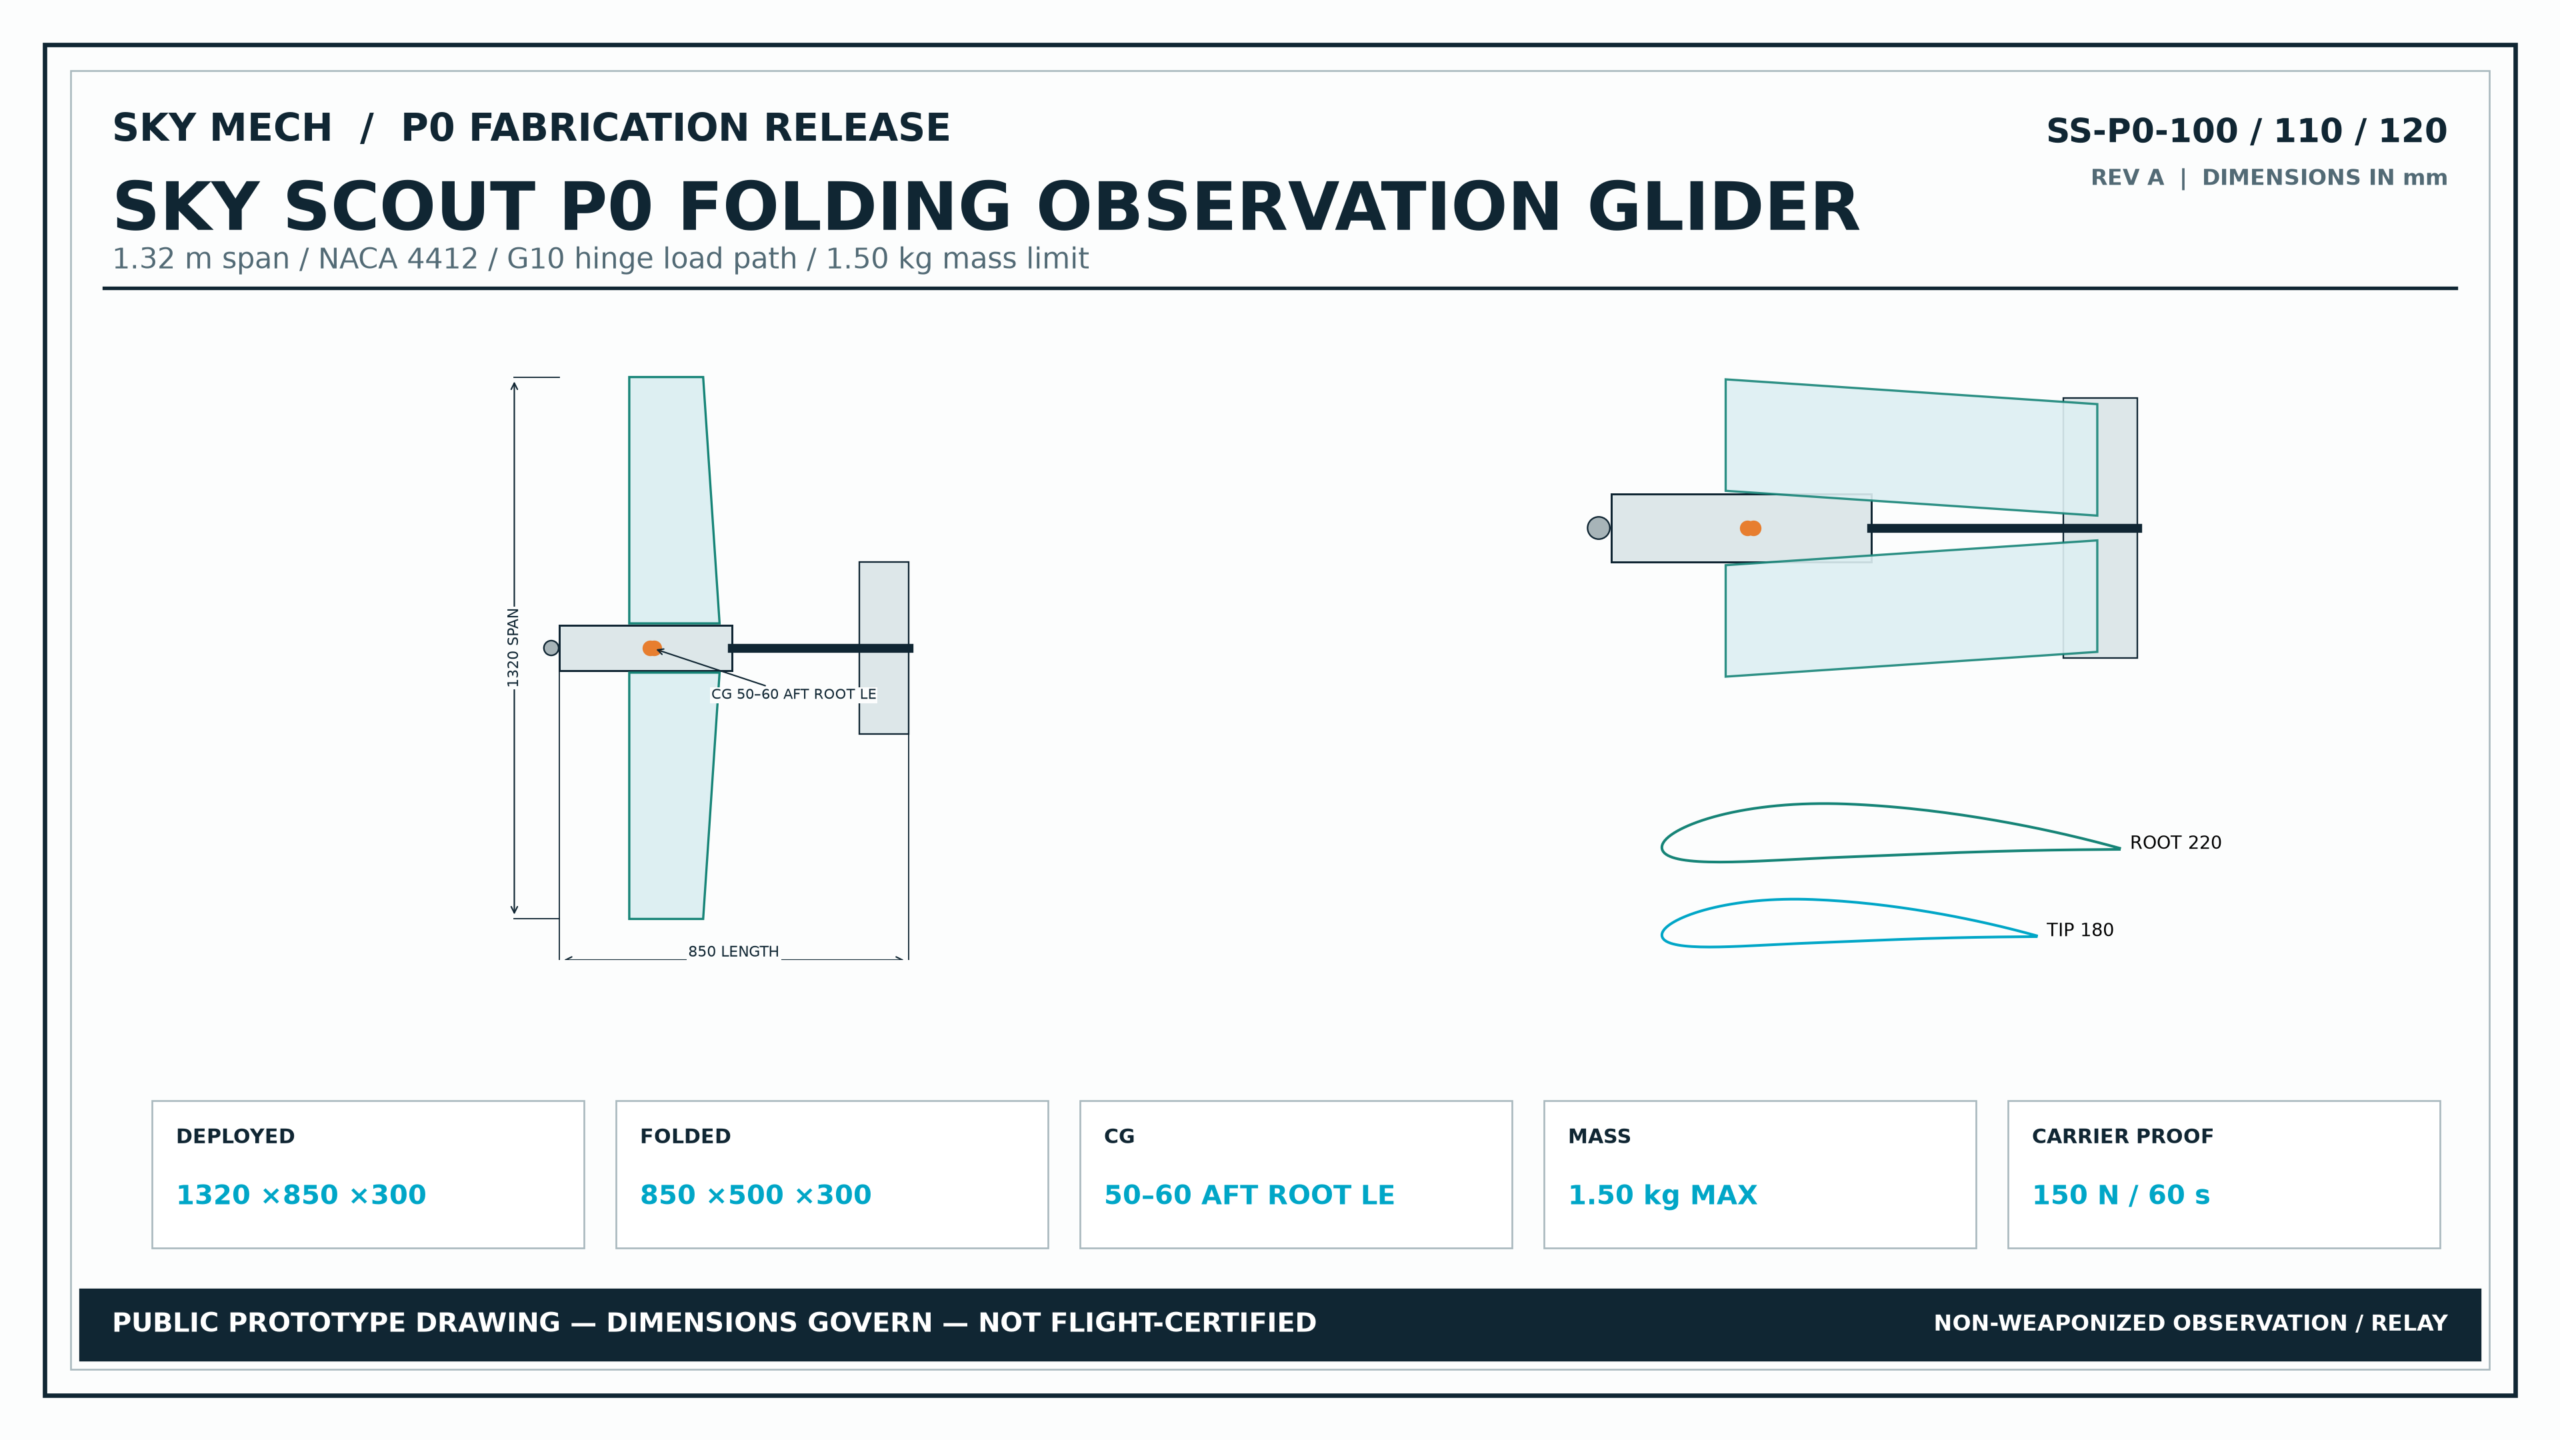
Foldable visible-light observation glider
1.32 m span, 1.35 kg design mass, fold/deploy geometry, structural frame and avionics envelope. The flight release actuator remains outside P0.
PROTOTYPE FABRICATION RELEASE — CAPTIVE/TETHERED ENGINEERING POC · PERSONNEL LIFTING PROHIBITED · NON-WEAPONIZED OBSERVATION AND RELAY CONFIGURATION.
The node and the network
Small units. Shared mission state.
A SKY MECH unit provides a high vantage point, local communications, sensing, and a small reserve of unmanned capacity. SKY MESH emerges when several units share state, relay traffic, divide search space, and substitute for a lost node.
The valuable asset is not the balloon. It is the time, line of sight, and future options stored at altitude.
Tactical economics
Impose a response cost larger than the node.
The economic objective is a distributed node cheap enough to replace, but valuable enough to force an adversary to reveal, maneuver, launch, or expend a costlier interceptor.
| Public cost anchor | Published figure | How to read it |
|---|---|---|
| NOAA radiosonde release | About US$200 | A bare lower-bound anchor for a simple balloon and weather instrument—not a SKY MECH quote. |
| Baoqi SKY MECH planning envelope | US$5k–25k per sensor/relay balloon prototype; US$30k–150k with six small UAVs and ground support | Internal concept range pending RFQ, recovery concept, payload, regulatory, and endurance trades. |
| FY2025 F-22A reimbursable rate | US$56,397 per flight hour | Official U.S. reimbursement rate; not a full combat sortie cost. |
| FY2025 AIM-9X procurement average | About US$533k per missile | US$193.1M divided by 362 missiles; program average, not marginal engagement cost. |
These are cost anchors, not apples-to-apples system quotes. The website will replace Baoqi planning envelopes with supplier RFQs and measured lifecycle cost as the program matures. Sources: NOAA/NWS and U.S. DoD FY2025 public documents.
Mission effects
Use stored altitude without building a giant aircraft.
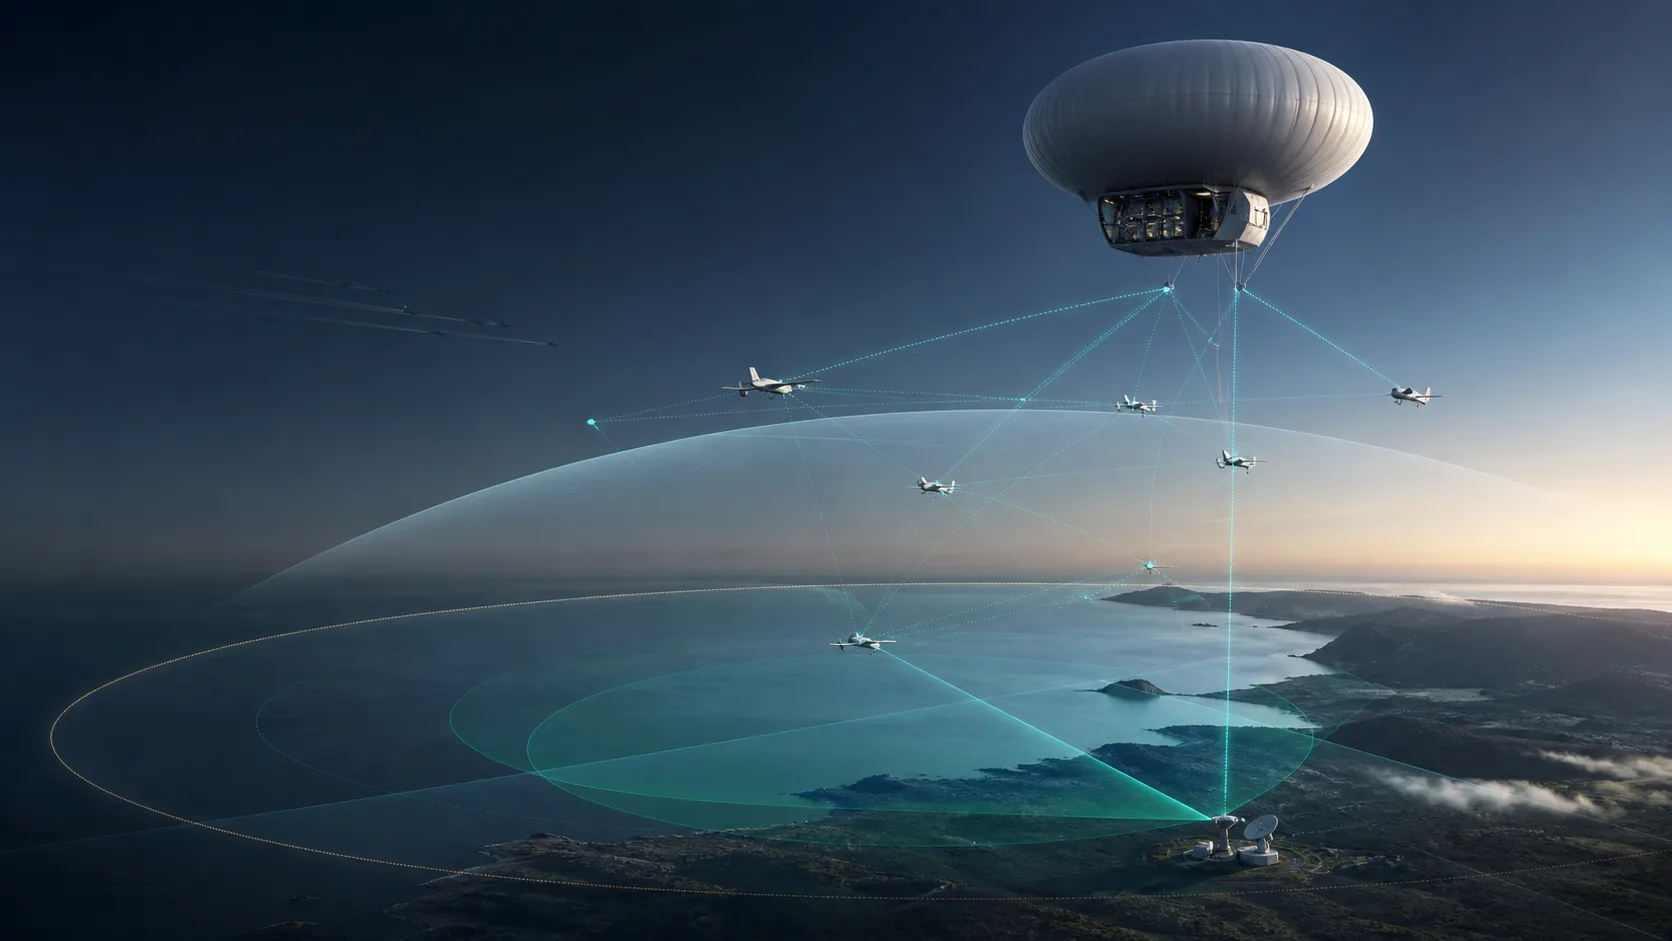
Sense early. Assign the right layer. Preserve reserve.
SHEEPDOG classifies mission state, assigns sensing, relay, observation, and reserve roles, and replans after node or link loss.
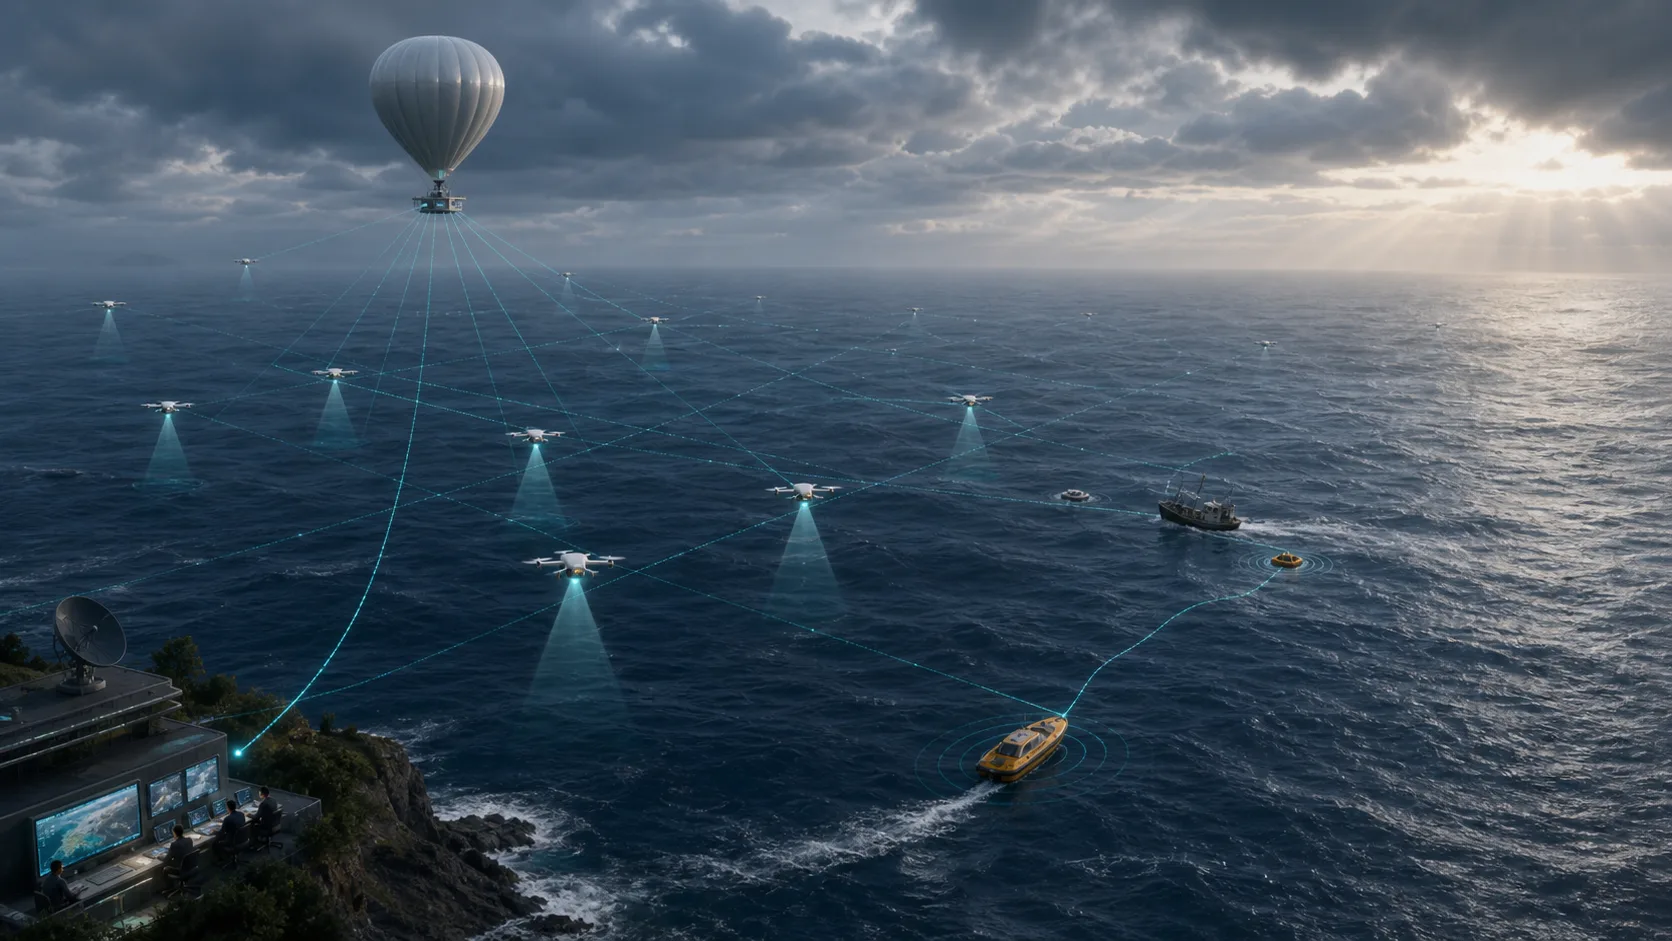
Turn a wide area into a coordinated search matrix.
Partition the grid, overlap observations, fuse detections, and hand confirmed locations to USV or rescue teams.
Verify the event before committing a larger asset.
Visible-light scout gliders and relay nodes support vessel identification, drifting-object observation, search-area confirmation and communications extension.
P0 excludes weapons, engagement guidance, certified flight release actuators and operational employment procedures.
Recover the mission picture, not just the link.
When a unit degrades, SHEEPDOG evaluates which observations and connections matter most, reallocates another balloon or UAV, and records the consequence.
How SHEEPDOG governs the mesh
Every unit joins through a capability passport.
Altitude, endurance, lift, sensing, links, UAV inventory, health.
Time-to-task, energy, replacement cost, reserve, future options.
Assign bounded sensing, relay, observation, or reserve roles.
Release leases and reallocate after balloon, UAV, or link loss.
Replay the trigger, alternatives, authorization, outcome, and recovery.
Prototype boundary
Fabrication geometry is released. Flight evidence is still pending.
P0 provides supplier-reviewable structure, cutting geometry, interfaces, BOM and first-article checks. The next proof points remain physical weighing, envelope pressure testing, load-path proof testing, communications testing, controlled tethered operation, lawful airspace approval and platform integration.
Current boundary
SKY MECH P0 is a non-weaponized, captive/tethered engineering POC for fabrication and validation work. Personnel lifting is prohibited.
Research partnership
Help turn the cost envelope into measured evidence.
We are seeking high-altitude platform, communications, sensing, recovery, lawful test-range, maritime, and public-safety partners.