Research context
Research library
Preserved research and engineering material, organized by its source page.
Explore the engineering foundations of ZERO × ALAYA × BABYLON: mission prediction, heterogeneous coordination and resource configuration. The collection connects design records, research methods and reusable mission knowledge.
Hardware research prototypes
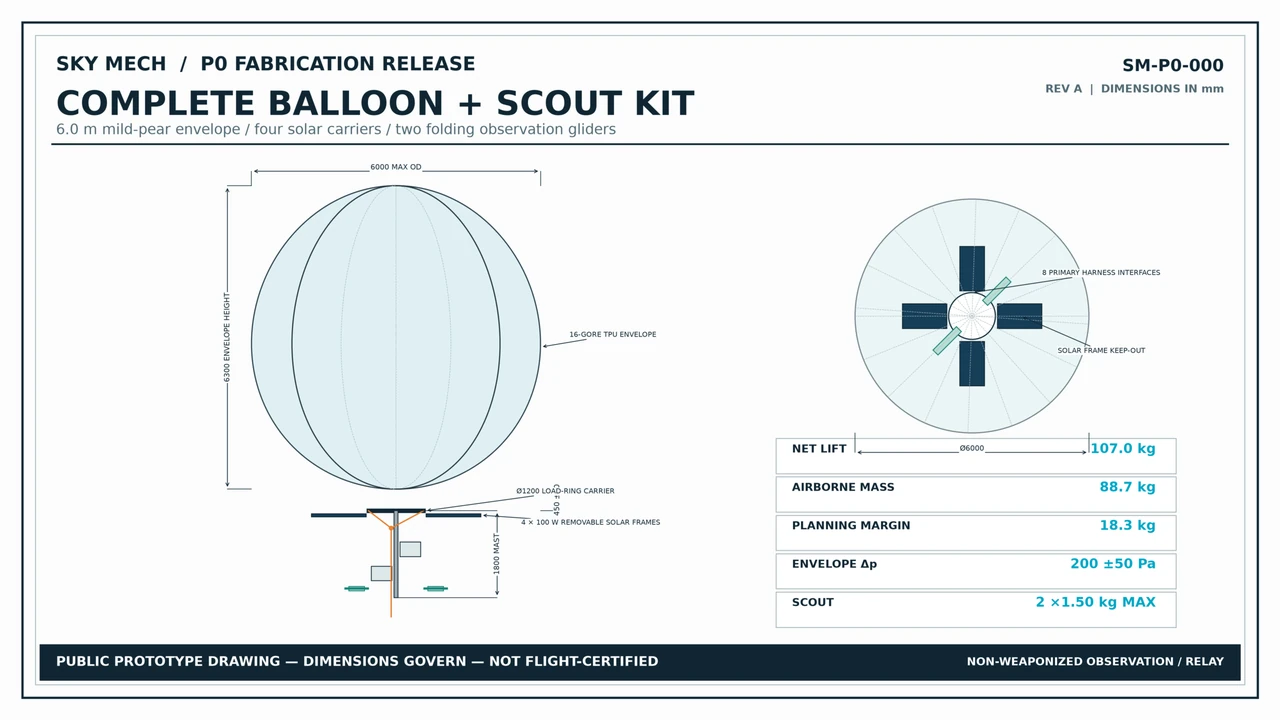
SKY MECH is a node. SKY MESH is the network many nodes form.
Both are hardware research tracks behind ZERO and ALAYA. They stay here with the research records; the product line is ZERO decides, ALAYA executes, BABYLON equips.
Research & Insights
Red–Blue AI Foundry, coordination and probabilistic search. 研究與洞察 · 研究とインサイト。
English

繁體中文

日本語

HOME · Archived research and engineering
Research and engineering records from the original program.
Mission autonomy · sensor to decision to action
One mission brain. A closed, reviewable loop.
SHEEPDOG keeps Sense → Understand → Decide → Assign → Act → Assess connected, while the five decision views below make intent, opposition, operator load, system behavior, and deployment constraints replayable before any platform is placed at risk.
→
→
→
→
Actual product · English interface
One simulator stack. Two operational views.
Runtime captures · not concept art
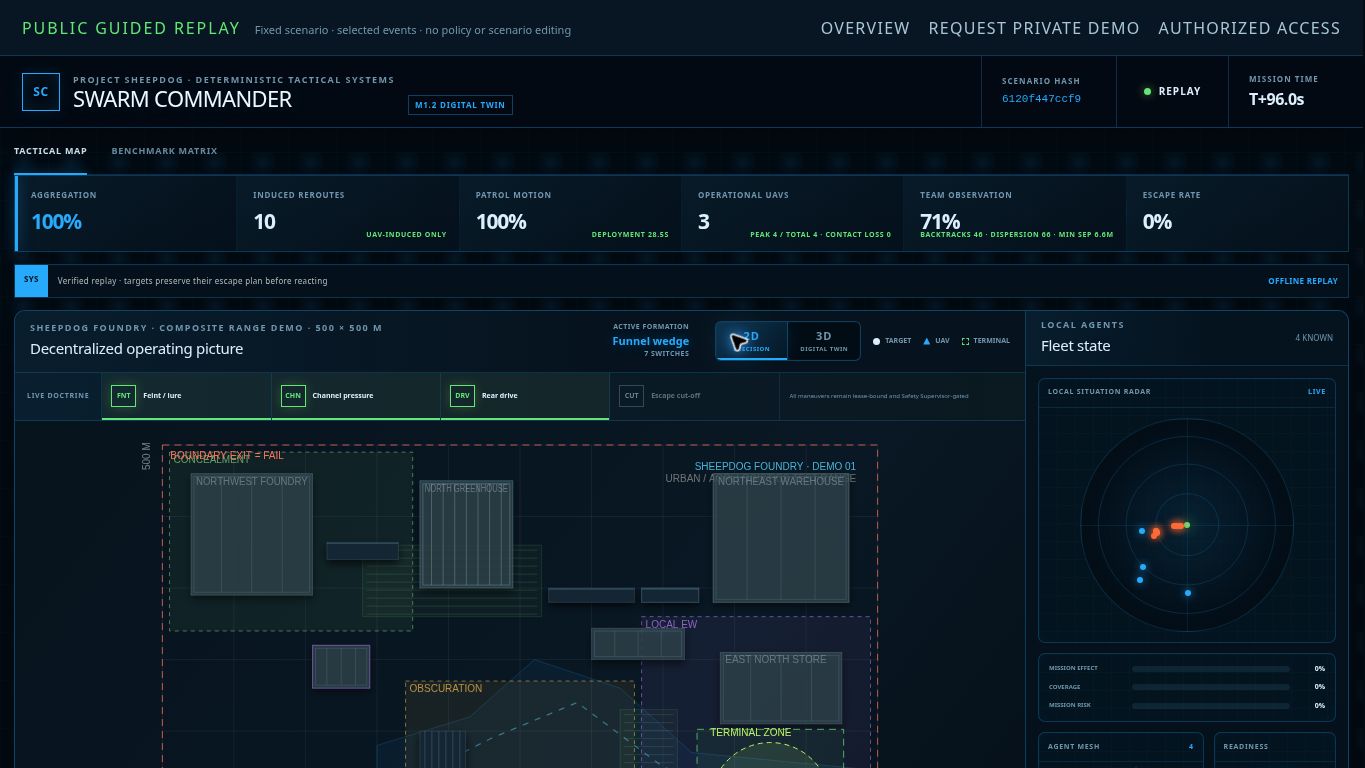
Planar command view
Exact paths, zones, KPIs, fleet state and deterministic replay evidence in one operator screen.
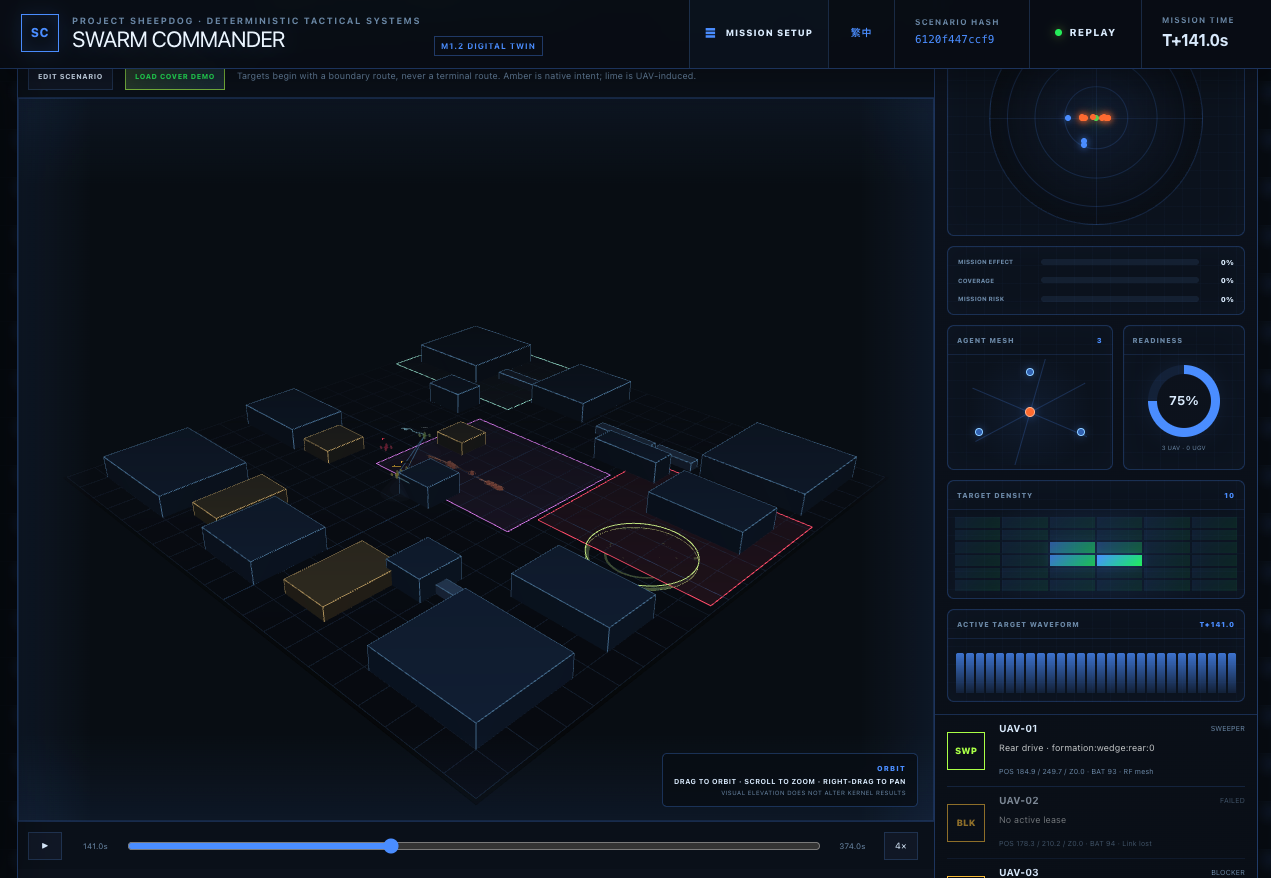
Spatial mission view
Altitude, terrain, buildings, line-of-sight context and asset separation rendered from the live simulation state.
Both views come from the working SHEEPDOG simulator and support repeatable mission replay—use 2D for precision analysis and 3D for spatial understanding.
Tactical pattern library
What SHEEPDOG evaluates in simulation.
In Defender AI Lab V0, deterministic BLUE candidates are tested against a fixed RED stress portfolio with separate training and holdout cases. Large-model candidate generation is Milestone 01 work.
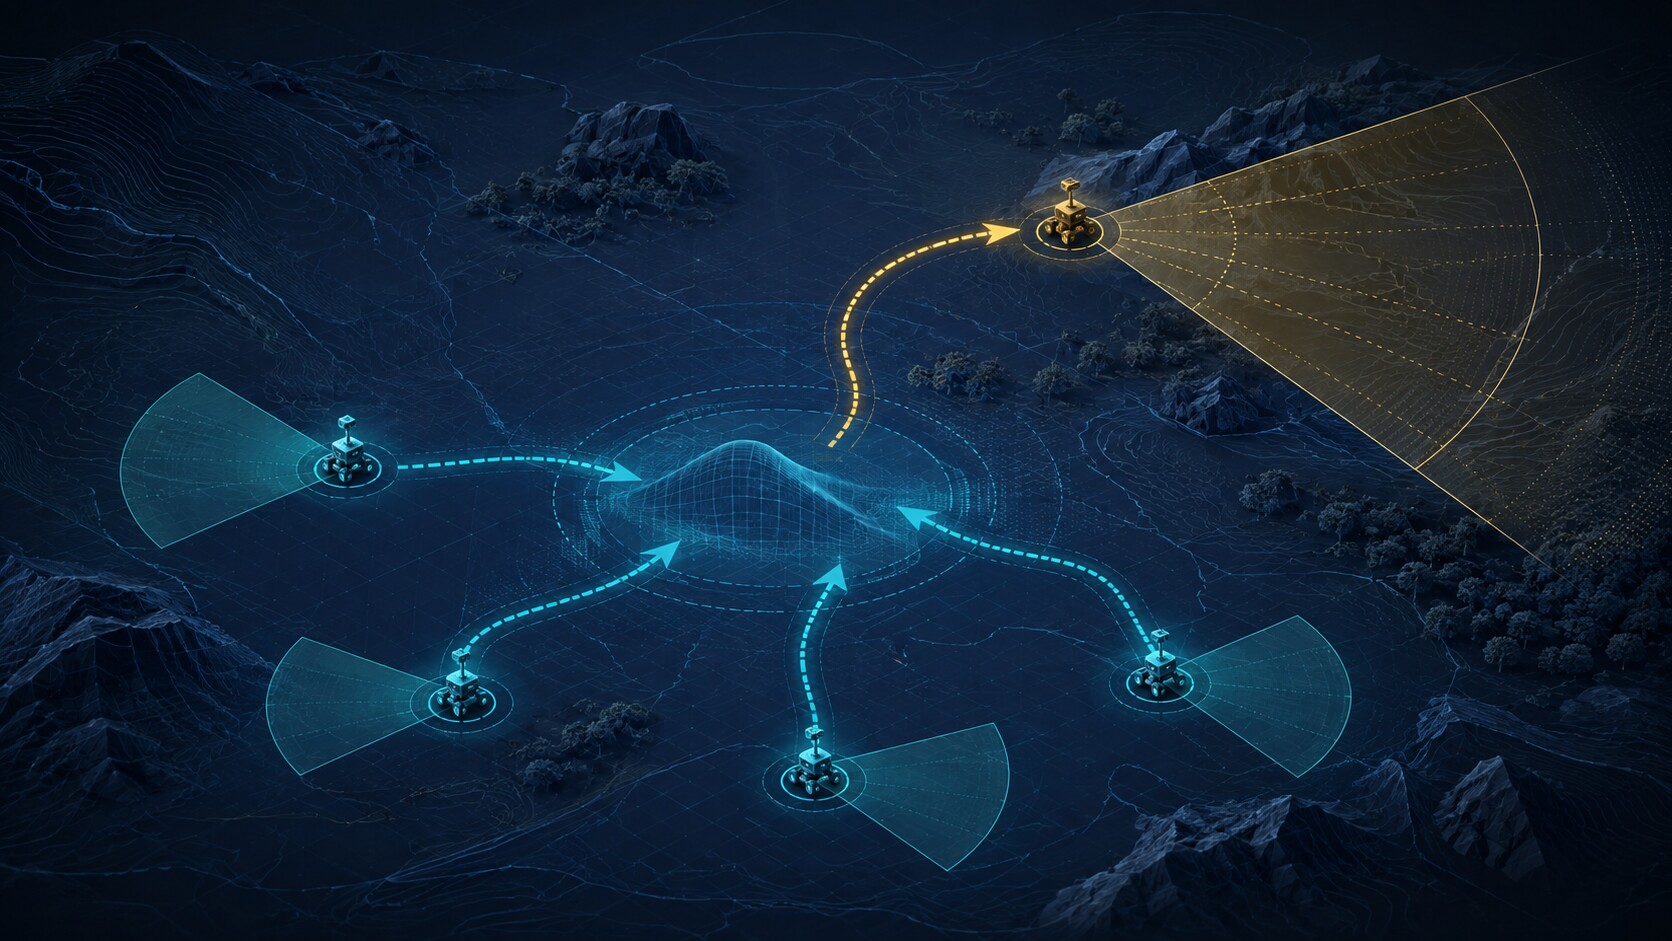
Shift attention. Reassign the mission.
A forward element draws commitment while the rest of the team preserves coverage, changes roles or completes the primary objective.
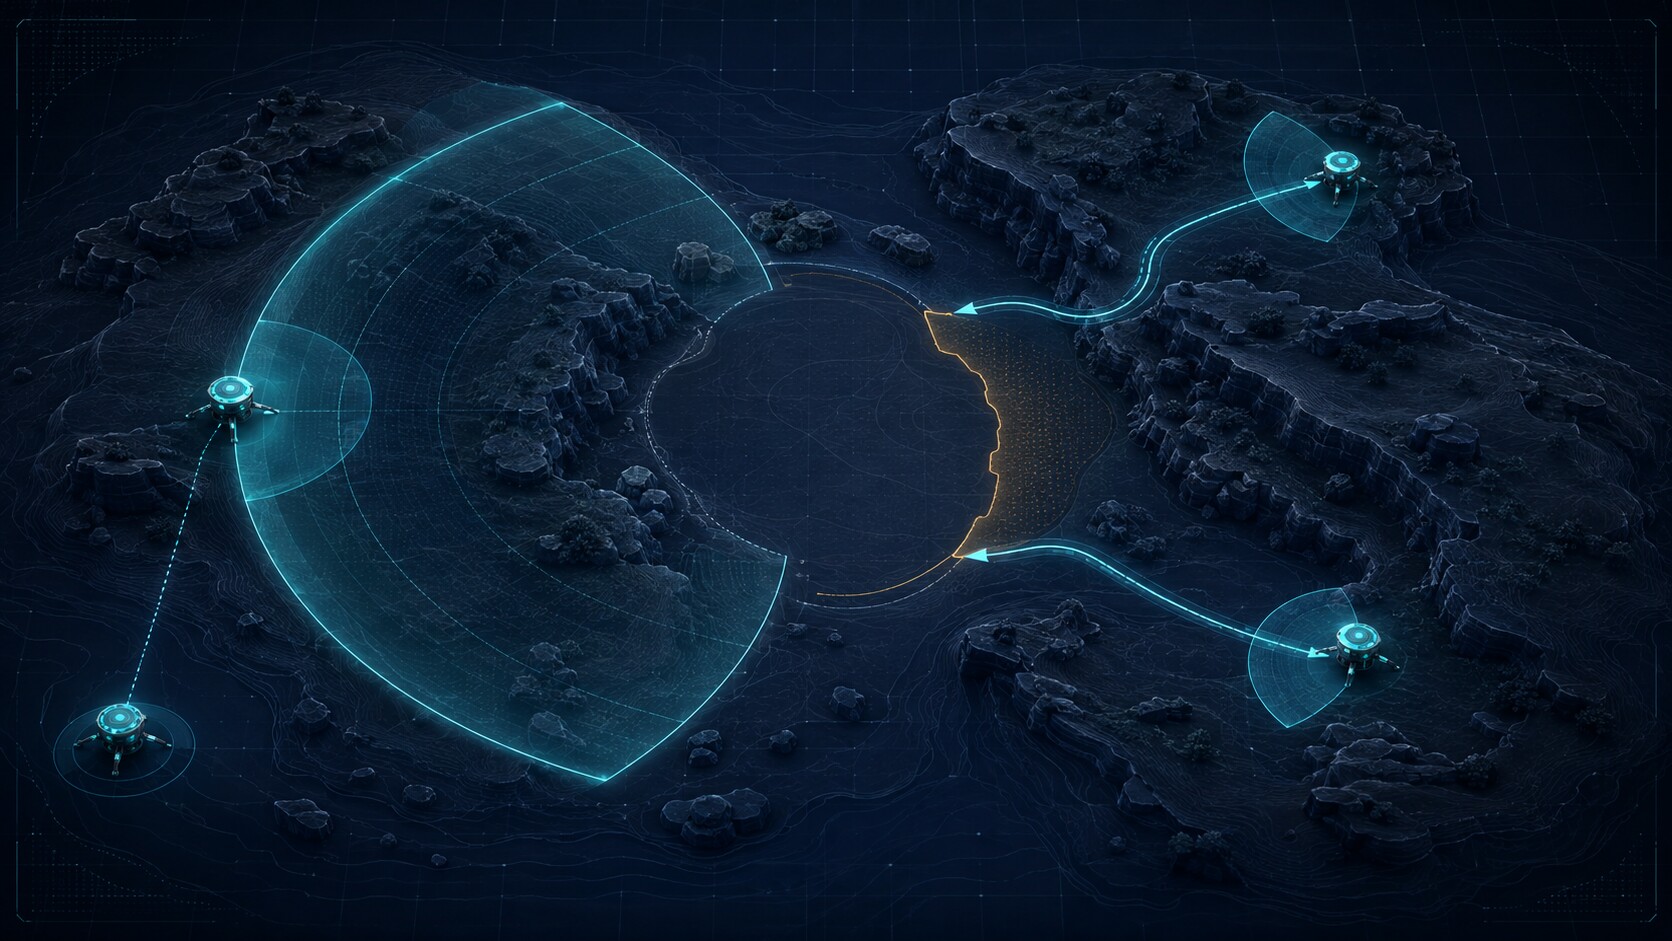
Shape the space. Close the gap.
One element maintains containment while other agents occupy alternate routes, close a coverage gap and preserve fallback capacity.
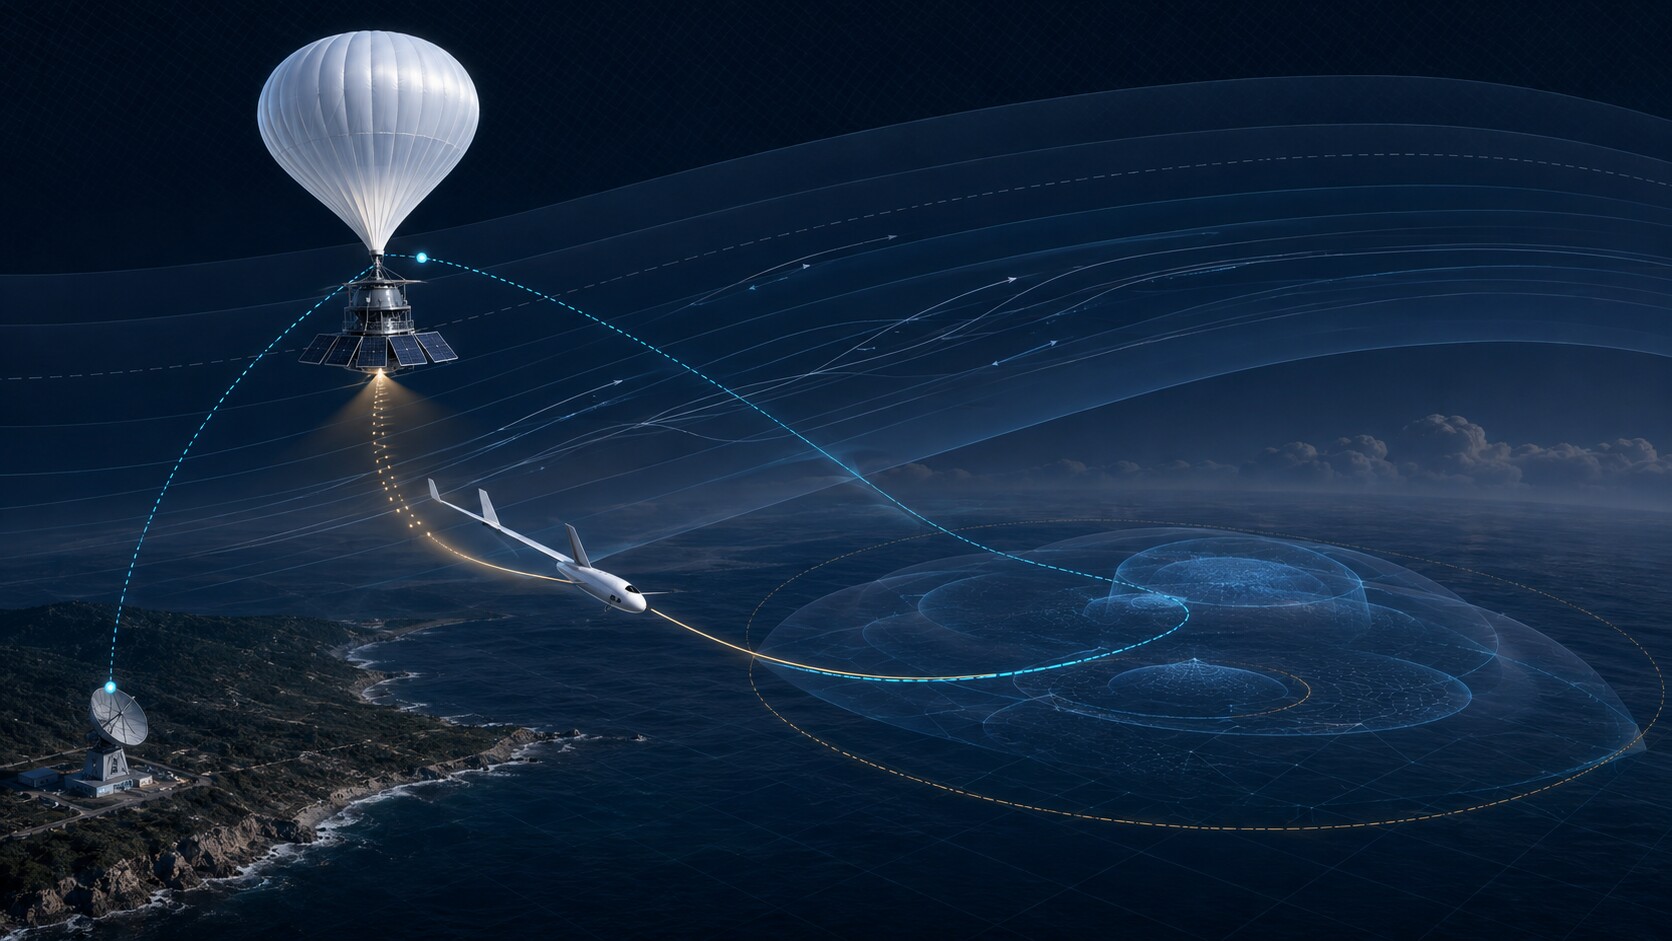
Use altitude as an energy budget.
A high-altitude relay releases a non-weaponized scout into gravity-assisted glide while simulation evaluates curved routing, link continuity and stability.
System map · one intelligence layer
Different machines. One mission model.
SHEEPDOG tests how heterogeneous platforms should coordinate, what each should preserve and when a human must intervene.
Partner platforms retain flight-control authority. SHEEPDOG supplies tested mission logic, bounded recommendations and decision evidence.
Governed AI value · human authority retained
Keep human authority. Give the machine the synchronization burden.
Human GO / NO-GO, pause and return authority frames ALAYA’s synthetic mission replay. The multi-vehicle scenario shows rule-based role reassignment, separation and decision evidence. Separate synthetic studies model wind, communications, coverage, reserve and cost.
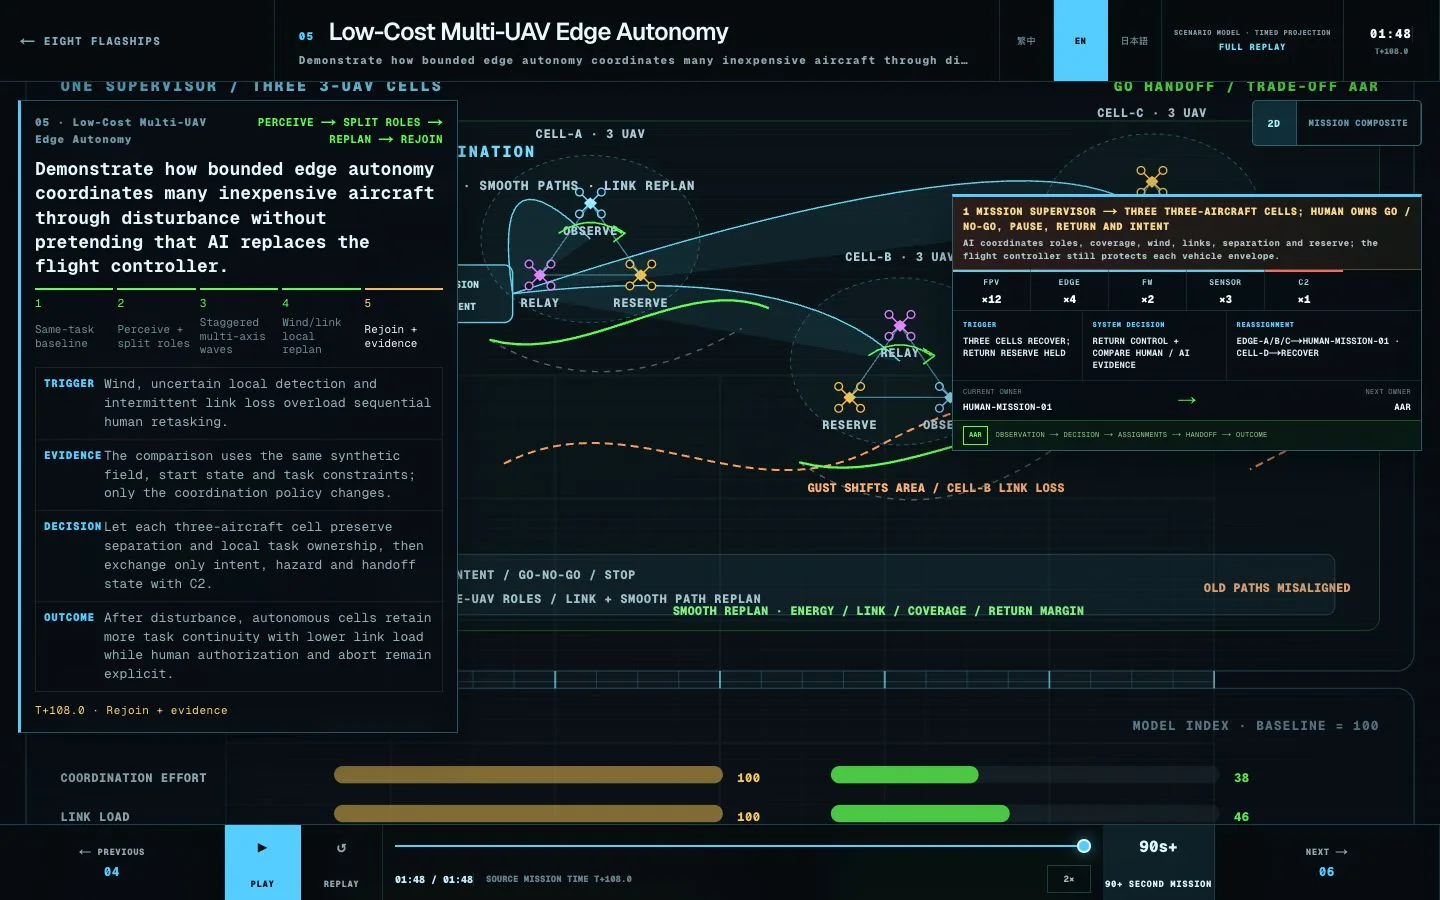
Humans set mission intent. Synthetic replay shows role reassignment and separation.
Within a defined scenario, deterministic rules recalculate role assignments and separation status. Edge execution on aircraft remains an integration and validation milestone.
The release specification requires named human review of proposals, with amendment, rejection and appeal paths. Policy and model promotion require holdout evaluation and regression checks. Pay, merit and version decisions require human authorization.
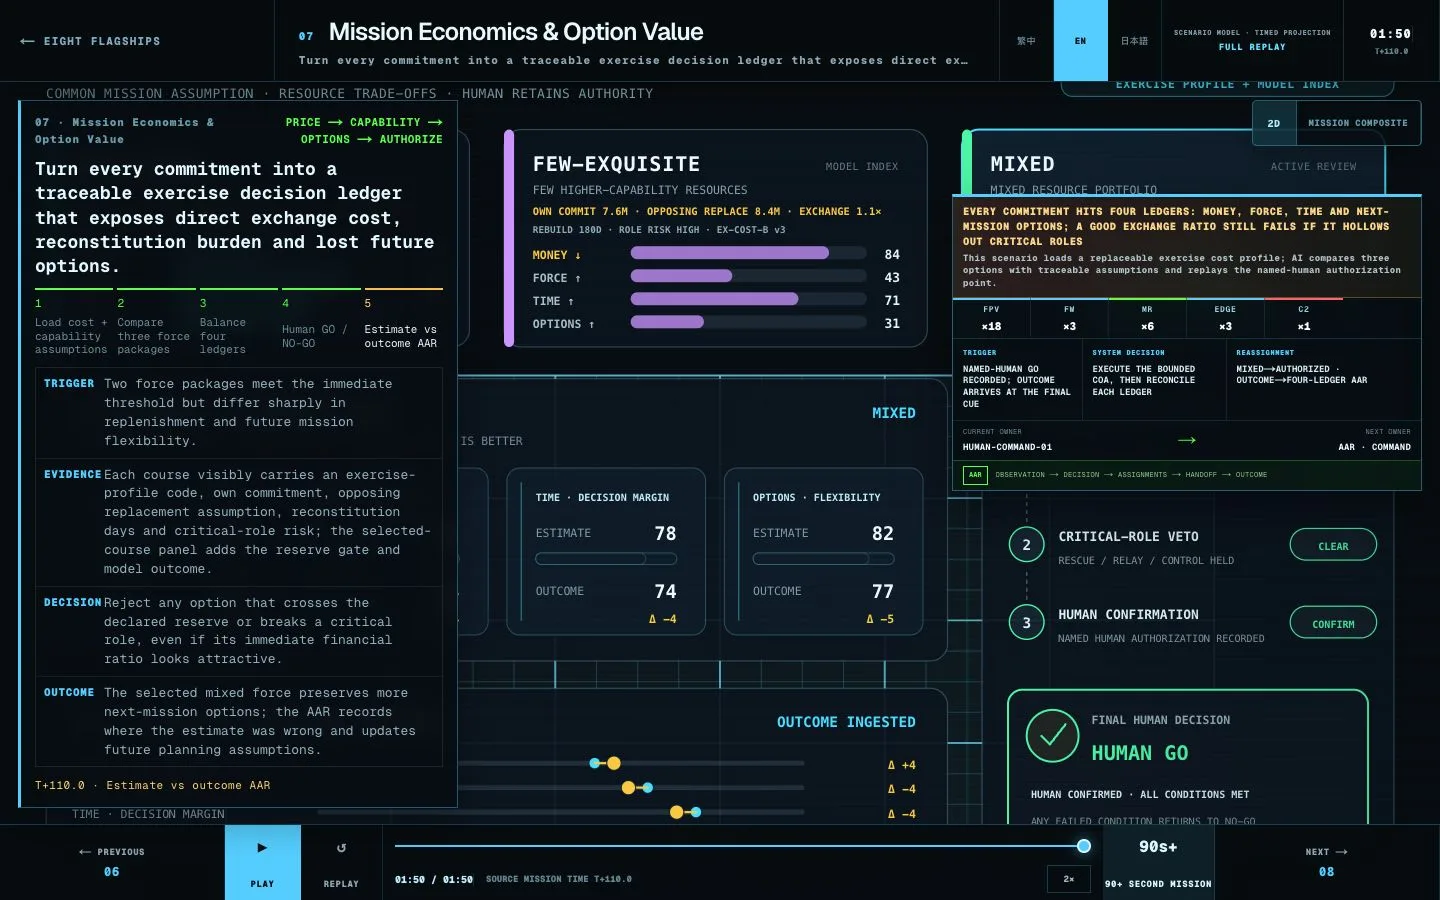
Account for this win and the force that remains for the next mission.
Money, force, rebuild time and future options are shown separately, exposing plans that look inexpensive but consume scarce roles, reserves or the ability to abort and re-task.
The release specification requires named human review of proposals, with amendment, rejection and appeal paths. Policy and model promotion require holdout evaluation and regression checks. Pay, merit and version decisions require human authorization.
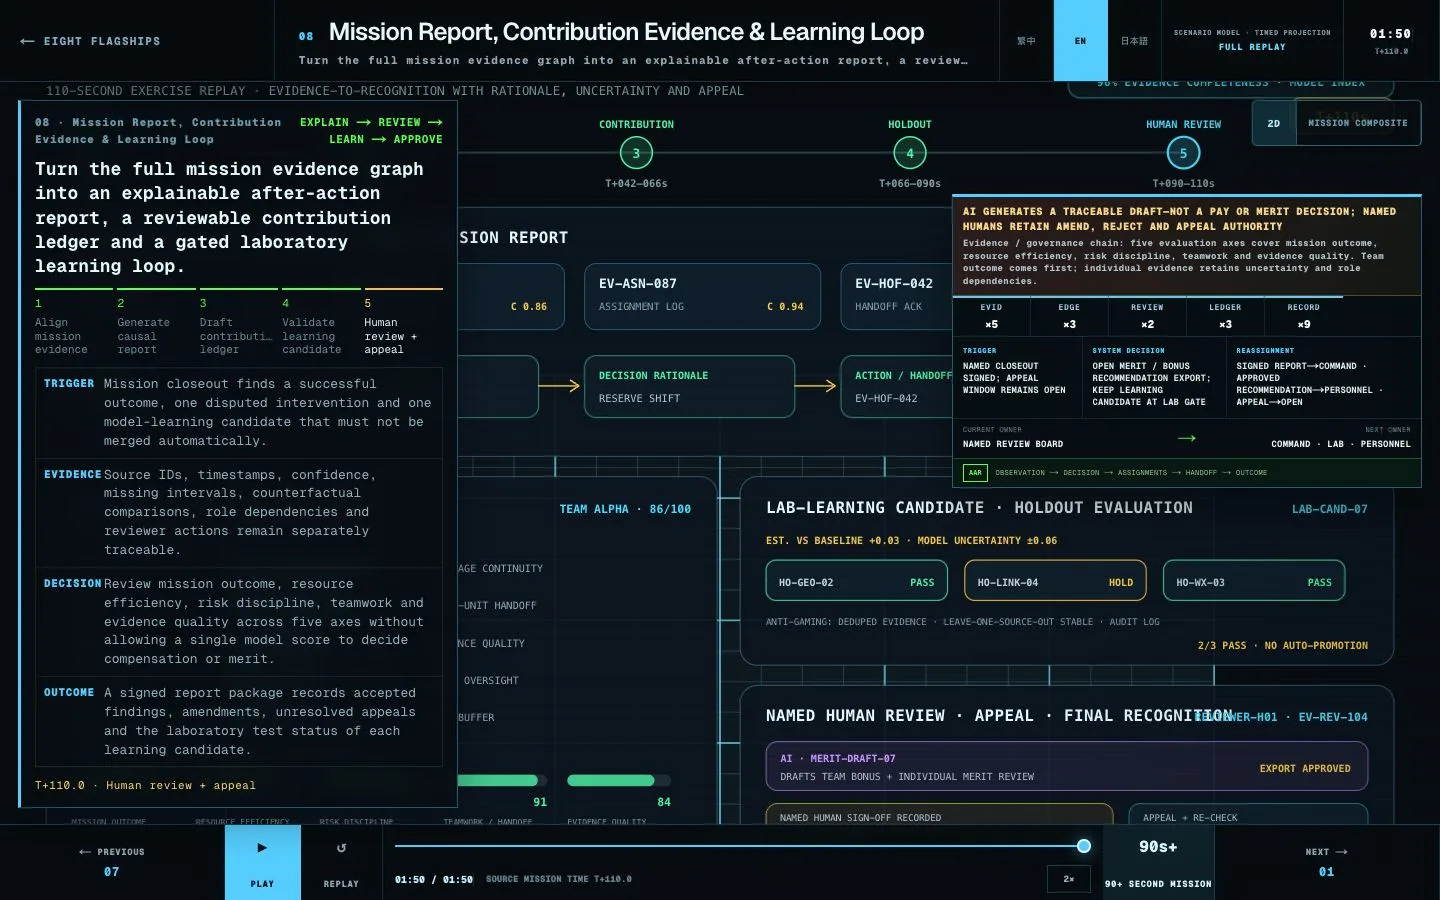
Turn every decision into reviewable, appealable evidence.
Observations, decisions, re-tasking, handoffs and outcomes are aligned into one causal record. Team-first contribution drafts and learning candidates remain behind a laboratory governance gate.
The release specification requires named human review of proposals, with amendment, rejection and appeal paths. Policy and model promotion require holdout evaluation and regression checks. Pay, merit and version decisions require human authorization.
Research insights · deterministic synthetic studies
See the coordination problem before reading it.
Three visual studies make handoff, uncertainty and maritime belief directly inspectable.
Keep Moving, Keep the Track
Transfer sensing only after dual-FOV overlap, bank-limited turn feasibility and obstacle clearance agree.
The Center Moves with Uncertainty
Stage where information need remains highest while preserving a minimum reserve and avoiding oscillation.
Coast the Belief, Not Hidden Truth
Current and wind propagate visible probability branches until reacquisition—or an honest LOST state.
Evidence, not slides
Engineering assets across the mission stack.
Working software, reproducible research and engineering releases remain visibly separated.
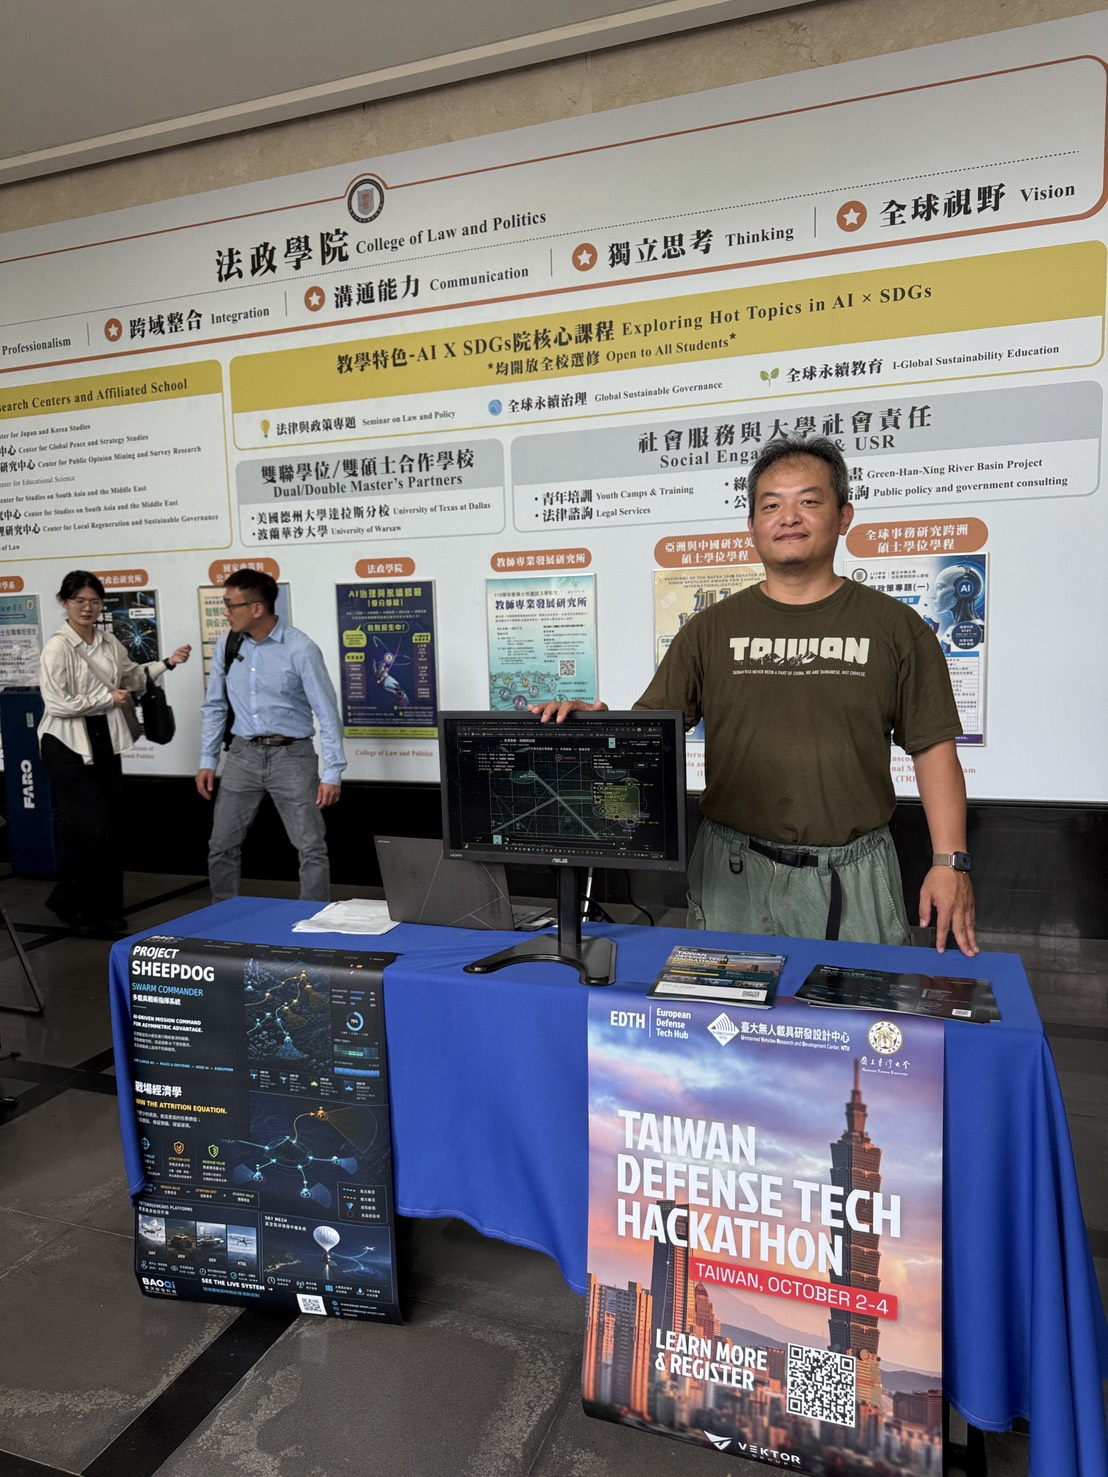
In the Field / Updates ·
SHEEPDOG at the Taiwan Unmanned Systems Strategy Forum
Baoqi Smart demonstrated its mission intelligence platform at National Chung Hsing University in Taichung.
Collaboration ecosystem
Built with partners who move ideas into the field.
Baoqi Smart works across defense innovation and system integration—connecting mission intelligence to organizations that can help validate, integrate and deploy.
Hardware · research · integration
Connect your platform to ALAYA.
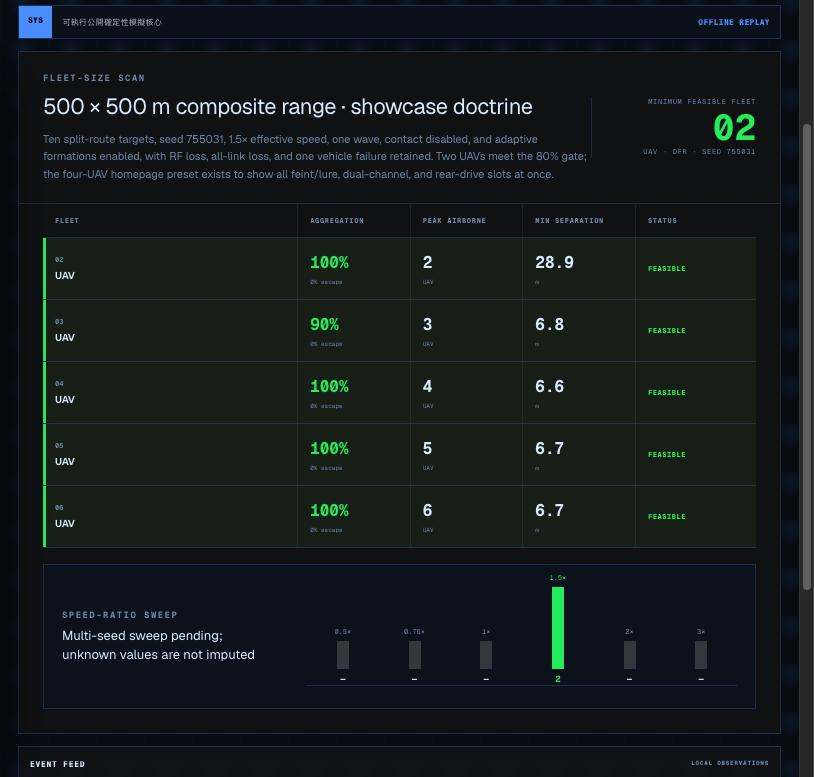
Bring a mission, operating constraints and a capability profile. We will turn them into a repeatable scenario, a minimum-feasible fleet question and measurable evidence.
SHEEPDOG · Archived research and engineering
Research and engineering records from the original program.
Initial Tactical Application: One Operator + Three UAVs
One operator. Three affordable aircraft. One bounded tactical team.
Our initial product target is one operator supervising three affordable, replaceable aircraft through a portable control interface, with measurable role assignment, operator load, degraded-link recovery, and replayable decision evidence.
The three-aircraft team is the initial demonstration objective. Software, SIL, HIL and platform integration require separate validation before a physical integration pilot.
Initial validation gate
Why start here?
A narrow cell is large enough to expose interoperability, operator-load, failure-recovery, and evidence problems while remaining small enough for repeatable SIL, HIL, and physical testing.
Product demo
See the mission brain make—and explain—a decision.
Watch the two-minute product walkthrough, then open a fixed, curated replay with selected events and benchmark results. Scenario controls, raw logs, policy search, and the full tactical laboratory remain available only through authorized access.
Product demo · 2:00 · English narration and subtitles.
Red–Blue AI Foundry
Milestone 01: from deterministic policy search to bounded edge evaluation.
Defender AI Lab V0 tests deterministic BLUE candidates against a fixed RED stress portfolio with training/holdout separation, ranking, and Model Cards. Milestone 01 plans large-model Red–Blue exploration and evaluated policy capsules for the edge.
Large-model scenarios and candidate patterns.
Matched Red–Blue synthetic trials.
Minimum feasible fleet and Pareto ranking.
Unseen seeds, replay, and safety gates.
Compact edge policy under human authority.
One evidence chain for both sides
BLUE and RED agents keep separate objectives, observations, messages, and model interfaces. Matched seeds, holdout replays, Model Cards, and Safety Supervisor gates preserve a traceable path from broad exploration to bounded policy. No large model directly controls a vehicle.
See what each side actually knows
Separate ground truth from every agent’s world.
The evaluator can inspect full scenario truth while BLUE and RED agents act only on the tracks, sensors, messages, and confidence available to them. Detection, handoff, deception resistance, and recovery become measurable—not theatrical.
Red–Blue agent control
Separate agents control each side. Hidden units remain visible to the evaluator while BLUE detection efficiency is scored against the same ground truth.
Per-vehicle sensor views
Inspect what each UAV or autonomous platform sees: field of view, live feed, track confidence, link state, assigned role, and handoff history.
Natural-language scenarios
Confirm an address and terrain, then describe BLUE and RED initial conditions and objectives separately. Side-specific APIs allow external AI models to join the same evidence protocol.
Order of Battle composer
Import vendor capability data; compose both BLUE and RED with their own UAVs, UGVs, human ground units, mobile C2 node, quantities, protected assets, mission dependencies, and configured lost-C2 fallback.
From simulation story to reusable doctrine
Record both sides. Extract the pattern. Reproduce the evidence.
Two synchronized chronicles preserve what BLUE and RED observed, which responses they considered, what they chose, why they chose it, what happened, and how they adapted. The complete story remains linked to deterministic replay instead of becoming an untraceable summary.
- Observed track confidence falling near FOV boundary
- Decided initiate overlapping handoff and preserve reserve
- Result custody retained; recovery recorded
- Observed BLUE sensor geometry and response delay
- Decided change route and test the coverage seam
- Result counter-response and outcome recorded
Dual decision history
Observation, options, action, rationale, outcome, and adaptation for each side.
Reproducible tactics
Trigger, assumptions, sequence, counterexample, confidence, and replay references.
Machine-readable guidance
Export machine-readable guidance candidates for human review and later edge evaluation.
Export the whole story
Package scenario identity, both logs, replay, patterns, doctrine, metrics, and provenance.
Mission mechanisms
Keep moving. Keep the track. Preserve the reserve.
SHEEPDOG evaluates continuous reconnaissance, second-view confirmation, overlapping field-of-view handoff, probabilistic reacquisition, capability-aware assignment, dynamic re-tasking, reserve positioning, degraded links, and loss recovery within the same replayable mission state. Decision Logs and AAR preserve why assignments changed and what happened next.
Fly through the track
Transfer custody before the target leaves the current sensor footprint.
Coast through uncertainty
Maintain a probability distribution when a ground or maritime track disappears.
Move the center
Reposition uncommitted assets as the searched area and risk field change.
Coverage Gap N-1
Test whether the mission can continue after a vehicle or link is lost.
Respect the airframe
Curved routes include fixed-wing turn time, energy, obstacles, and link continuity.
Gate every re-plan
SafetySupervisor and authorized human roles bound recommendations and recovery.
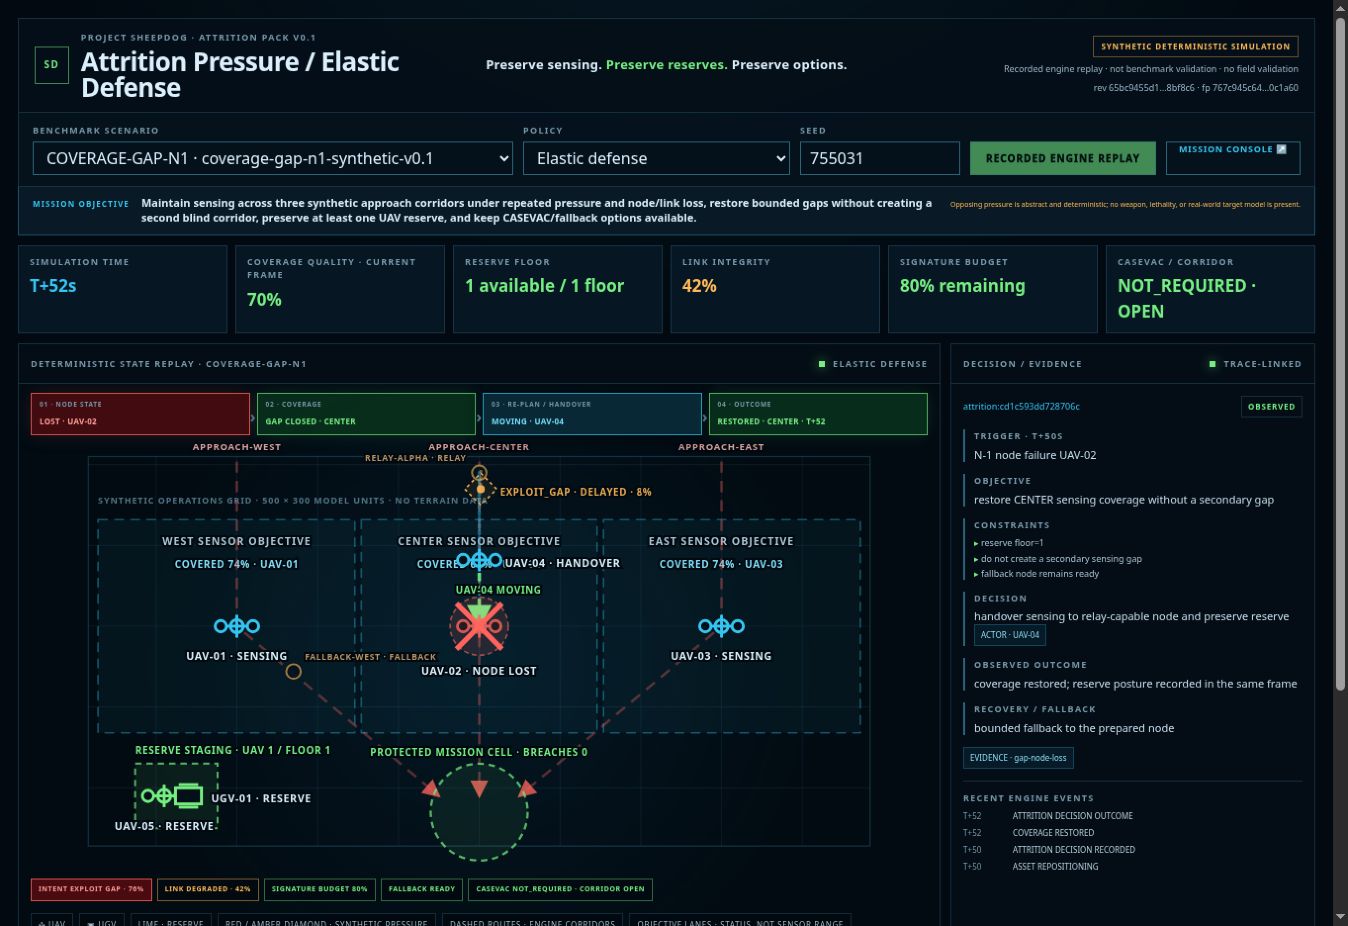
Build status
A complete mission-intelligence stack—above approved vehicle control.
Through ROS2, MAVLink, and vendor SDK adapters, sensors and vehicles expose capability, telemetry, health, and control boundaries to a mission layer above approved vehicle control. Current software combines Red–Blue agents, observer truth, capability passports, capability-aware assignment, task leases, probabilistic tracking, second-view confirmation, dynamic reserve positioning, degraded-link recovery, SafetySupervisor gates, Decision Logs, deterministic replay, AAR, and structured decision evidence.
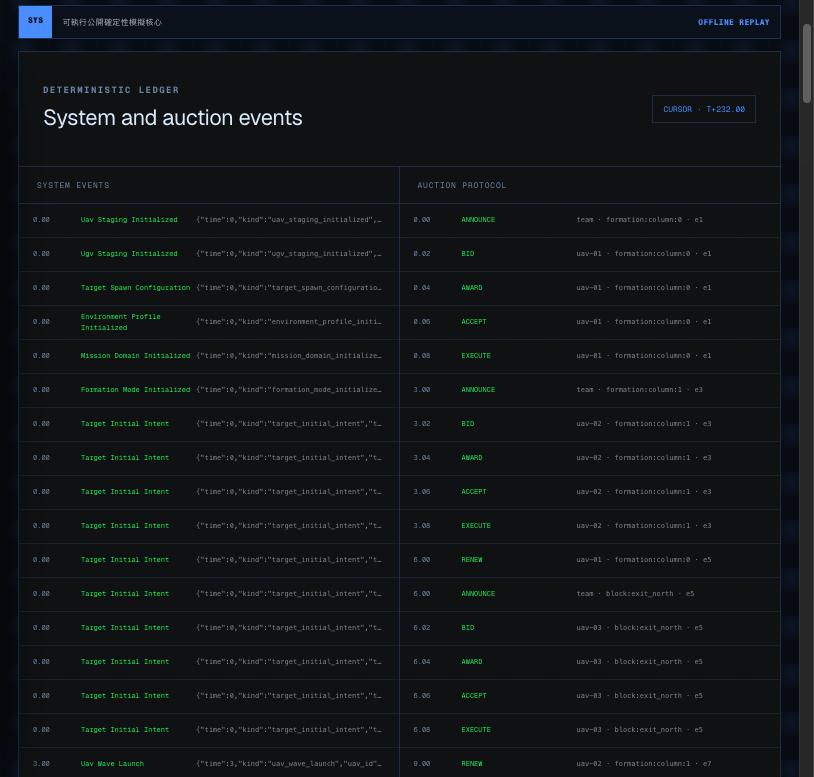
Platform integration partnership
Bring your airframe. We will bring the mission layer.
Baoqi Smart is actively seeking trusted UAV manufacturers and system integrators—especially non-PRC supply-chain partners in Taiwan and allied markets—to provide programmable multirotor, fixed-wing, or VTOL platforms for SHEEPDOG integration and joint validation.
Our starting tactical application is one operator coordinating a three-aircraft team through a portable control interface. Broader cooperative search and heterogeneous missions are later expansion directions, with platform integration validated separately. We welcome joint demos, funded R&D, adapter development, and international collaboration.
Mission workshop
Bring us a mission, not a shopping list.
We turn operating constraints into testable scenarios, integration contracts, minimum-feasible fleet questions, and measurable evidence.
PLATFORMS · Archived research and engineering
Research and engineering records from the original program.
Capability passport
Every asset joins through the same questions.
What can it do?
Mission roles, sensors, payload class, mobility, and control boundary.
What constrains it?
Endurance, weather, airspace, terrain, communications, and safety.
What changed?
Health, battery, link, position, confidence, inventory, and latency.
What is it worth now?
Time-to-task, energy, replacement cost, reserve value, and future options.
SHEEPDOG
The mission and evidence layer.
Mission graphs, capability-aware assignment, bounded role leases, degraded-link rules, reserve rotation, deterministic replay, and Tactical Digital Twin Core primitives are implemented in the current research software.
Red–Blue AI Foundry
From large-model competition to a compact edge policy.
Defender AI Lab V0 uses deterministic BLUE policy search against a fixed RED stress portfolio, with training/holdout evaluation, ranking, and Model Cards. Multi-large-model Red–Blue co-training and compact edge policy distillation are Milestone 01 work.
Propose scenarios and candidate patterns.
Stress Red and Blue across matched trials.
Rank feasible, non-dominated candidates.
Holdout replay and safety gates.
Compact policy capsule for the edge.
Build boundary
Defender AI Lab V0 currently provides deterministic BLUE policy search against a fixed red stress portfolio, training/holdout separation, ranking, and Model Card output. Multi-large-model co-training and edge distillation remain Milestone 01 work.
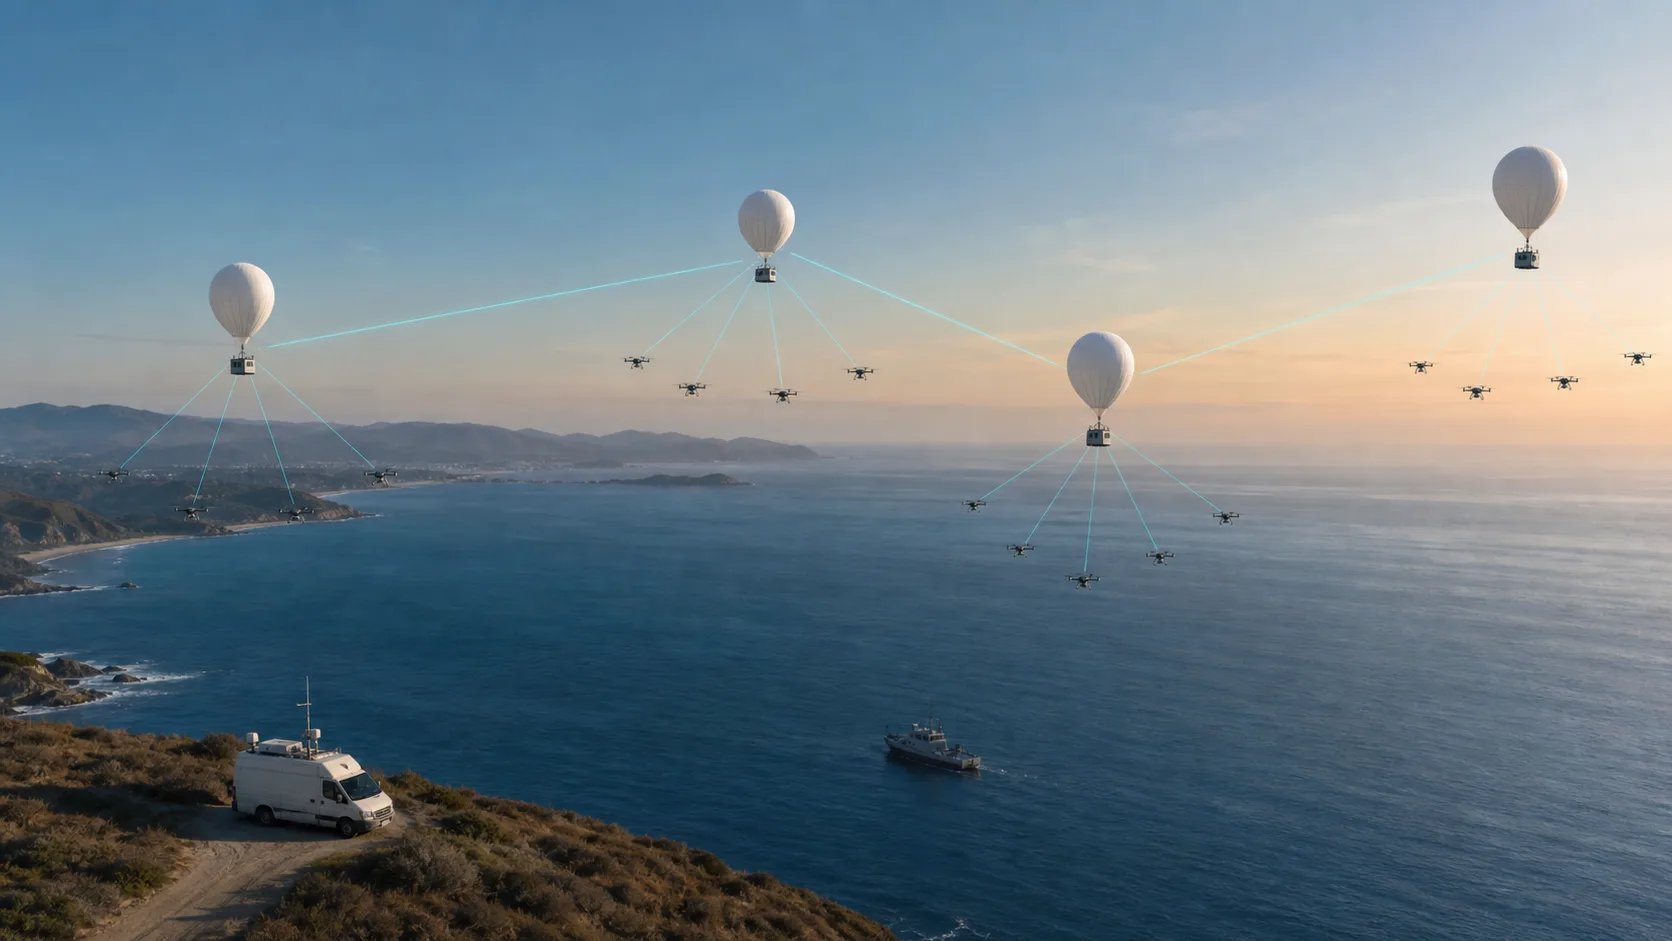
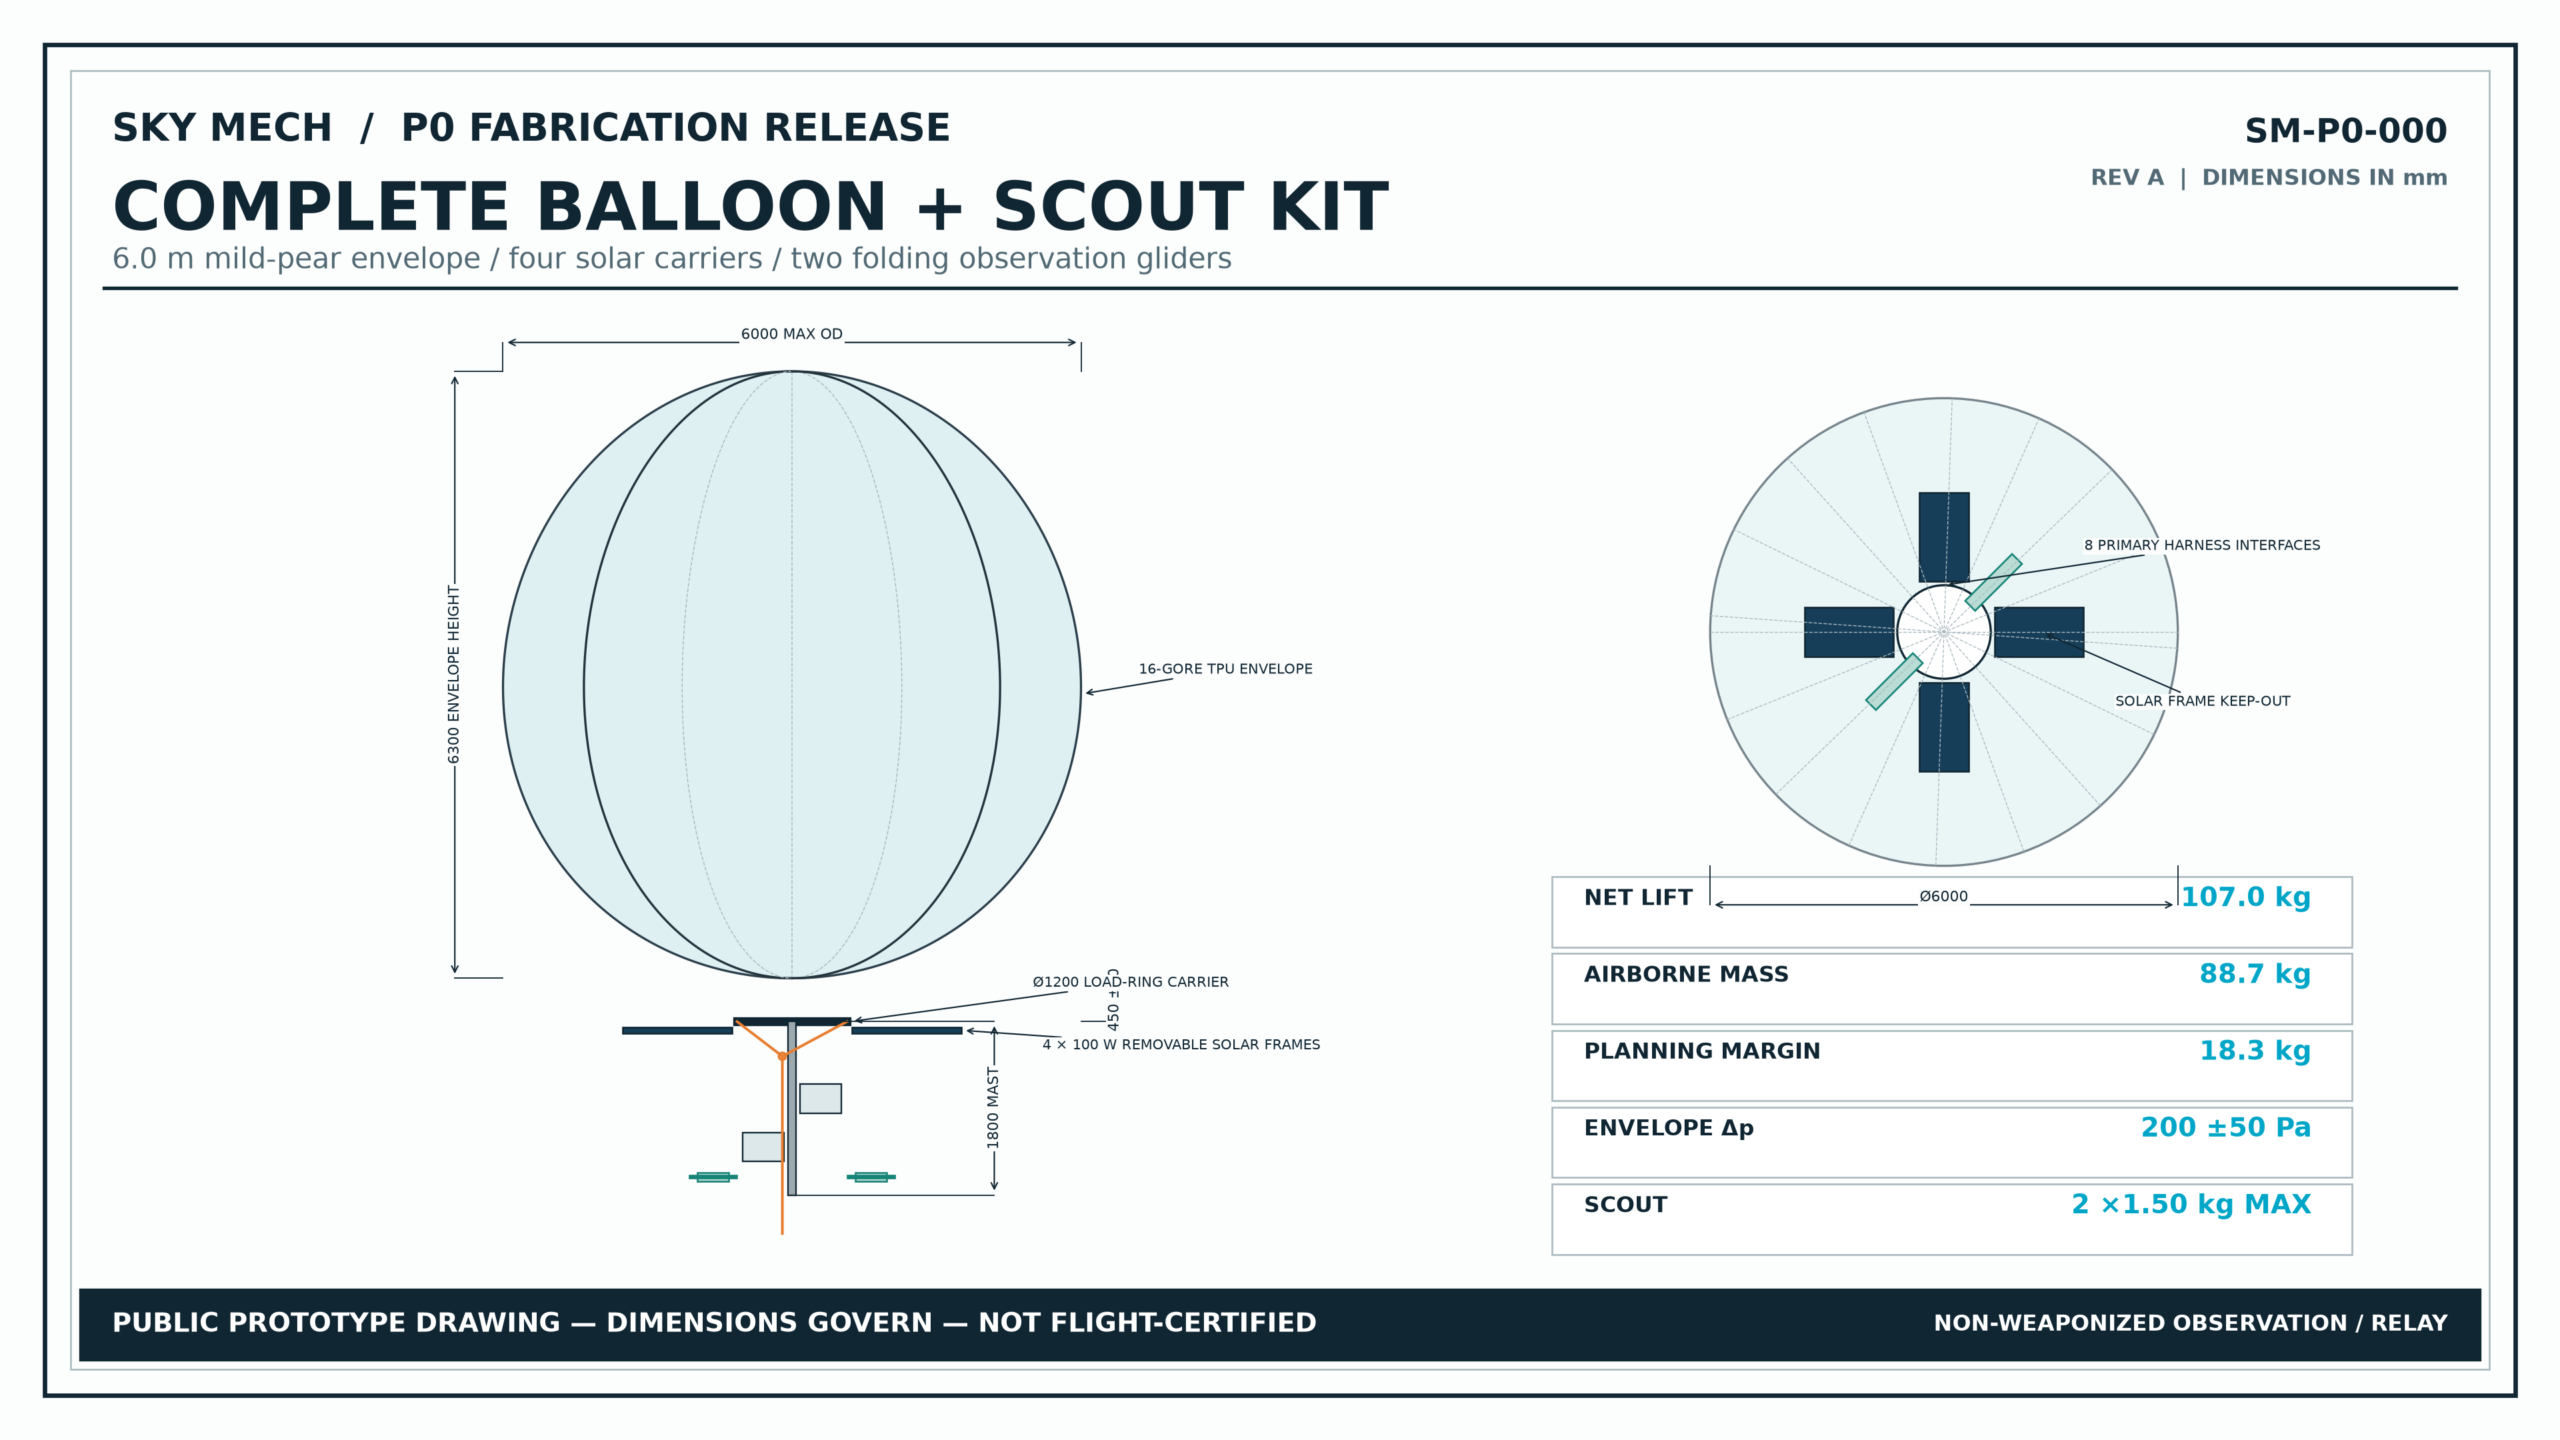
SKY MECH / SKY MESH
SKY MECH has a supplier-reviewable P0 CAD and fabrication package; it has not been fabricated, flown, or validated. SKY MESH multi-node operations remain a modeled concept.
UAV
Rapid reach, three-dimensional routing, aerial sensing, mapping, classification, relay, and mission response.
USV
Persistent surface presence, maritime sensing, confirmation, relay, patrol, and rescue handoff.
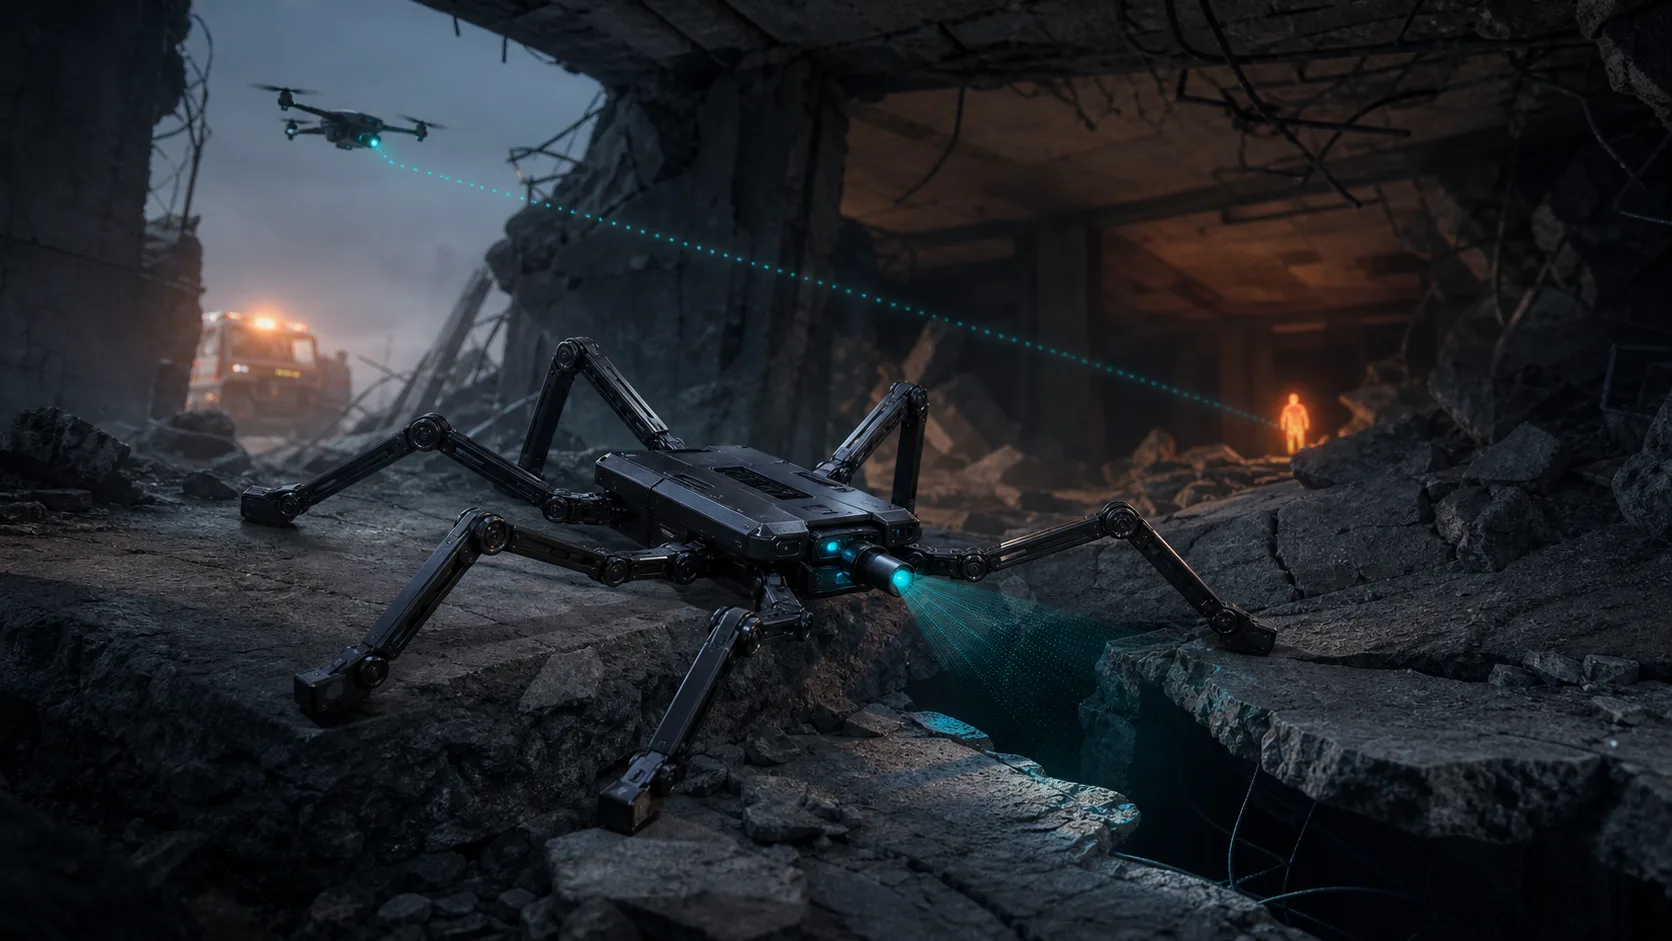
Jumping Spider
Low-profile access, gap crossing, interior and underground search, close inspection, hazard confirmation, and temporary sensing.
Jumping Spider · show the work
A hardware program with drawings, interfaces, and validation gates.
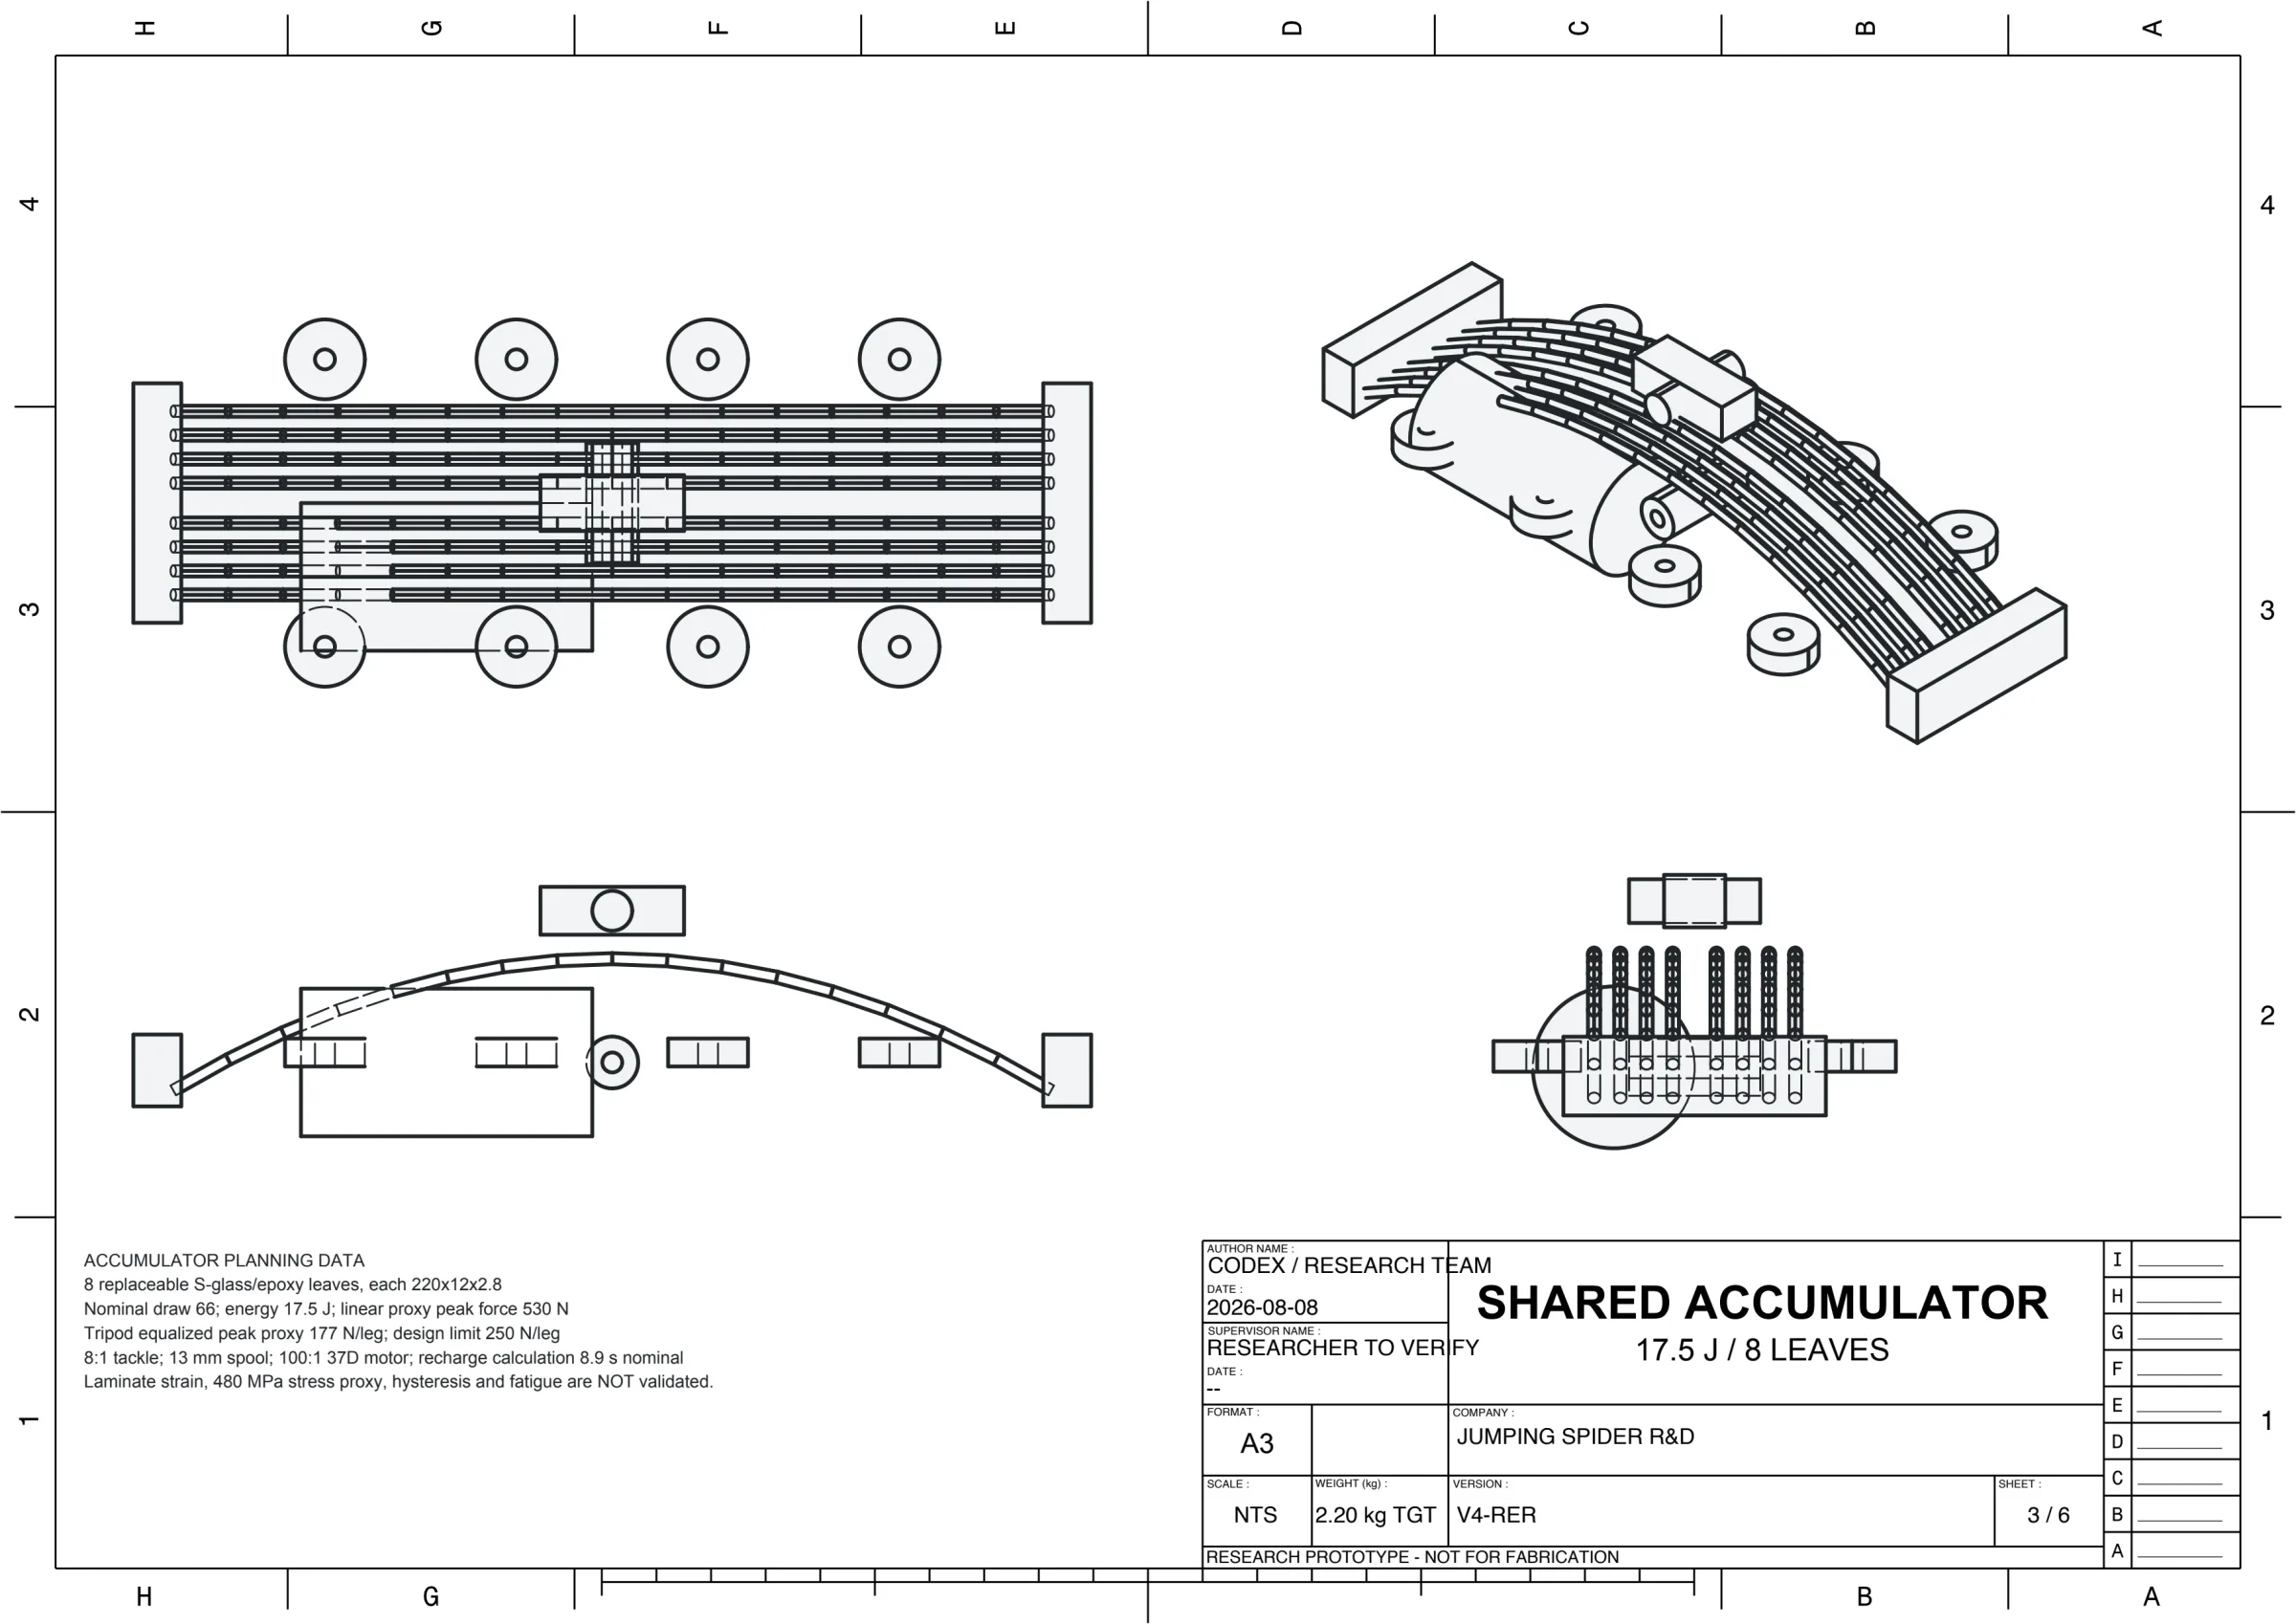
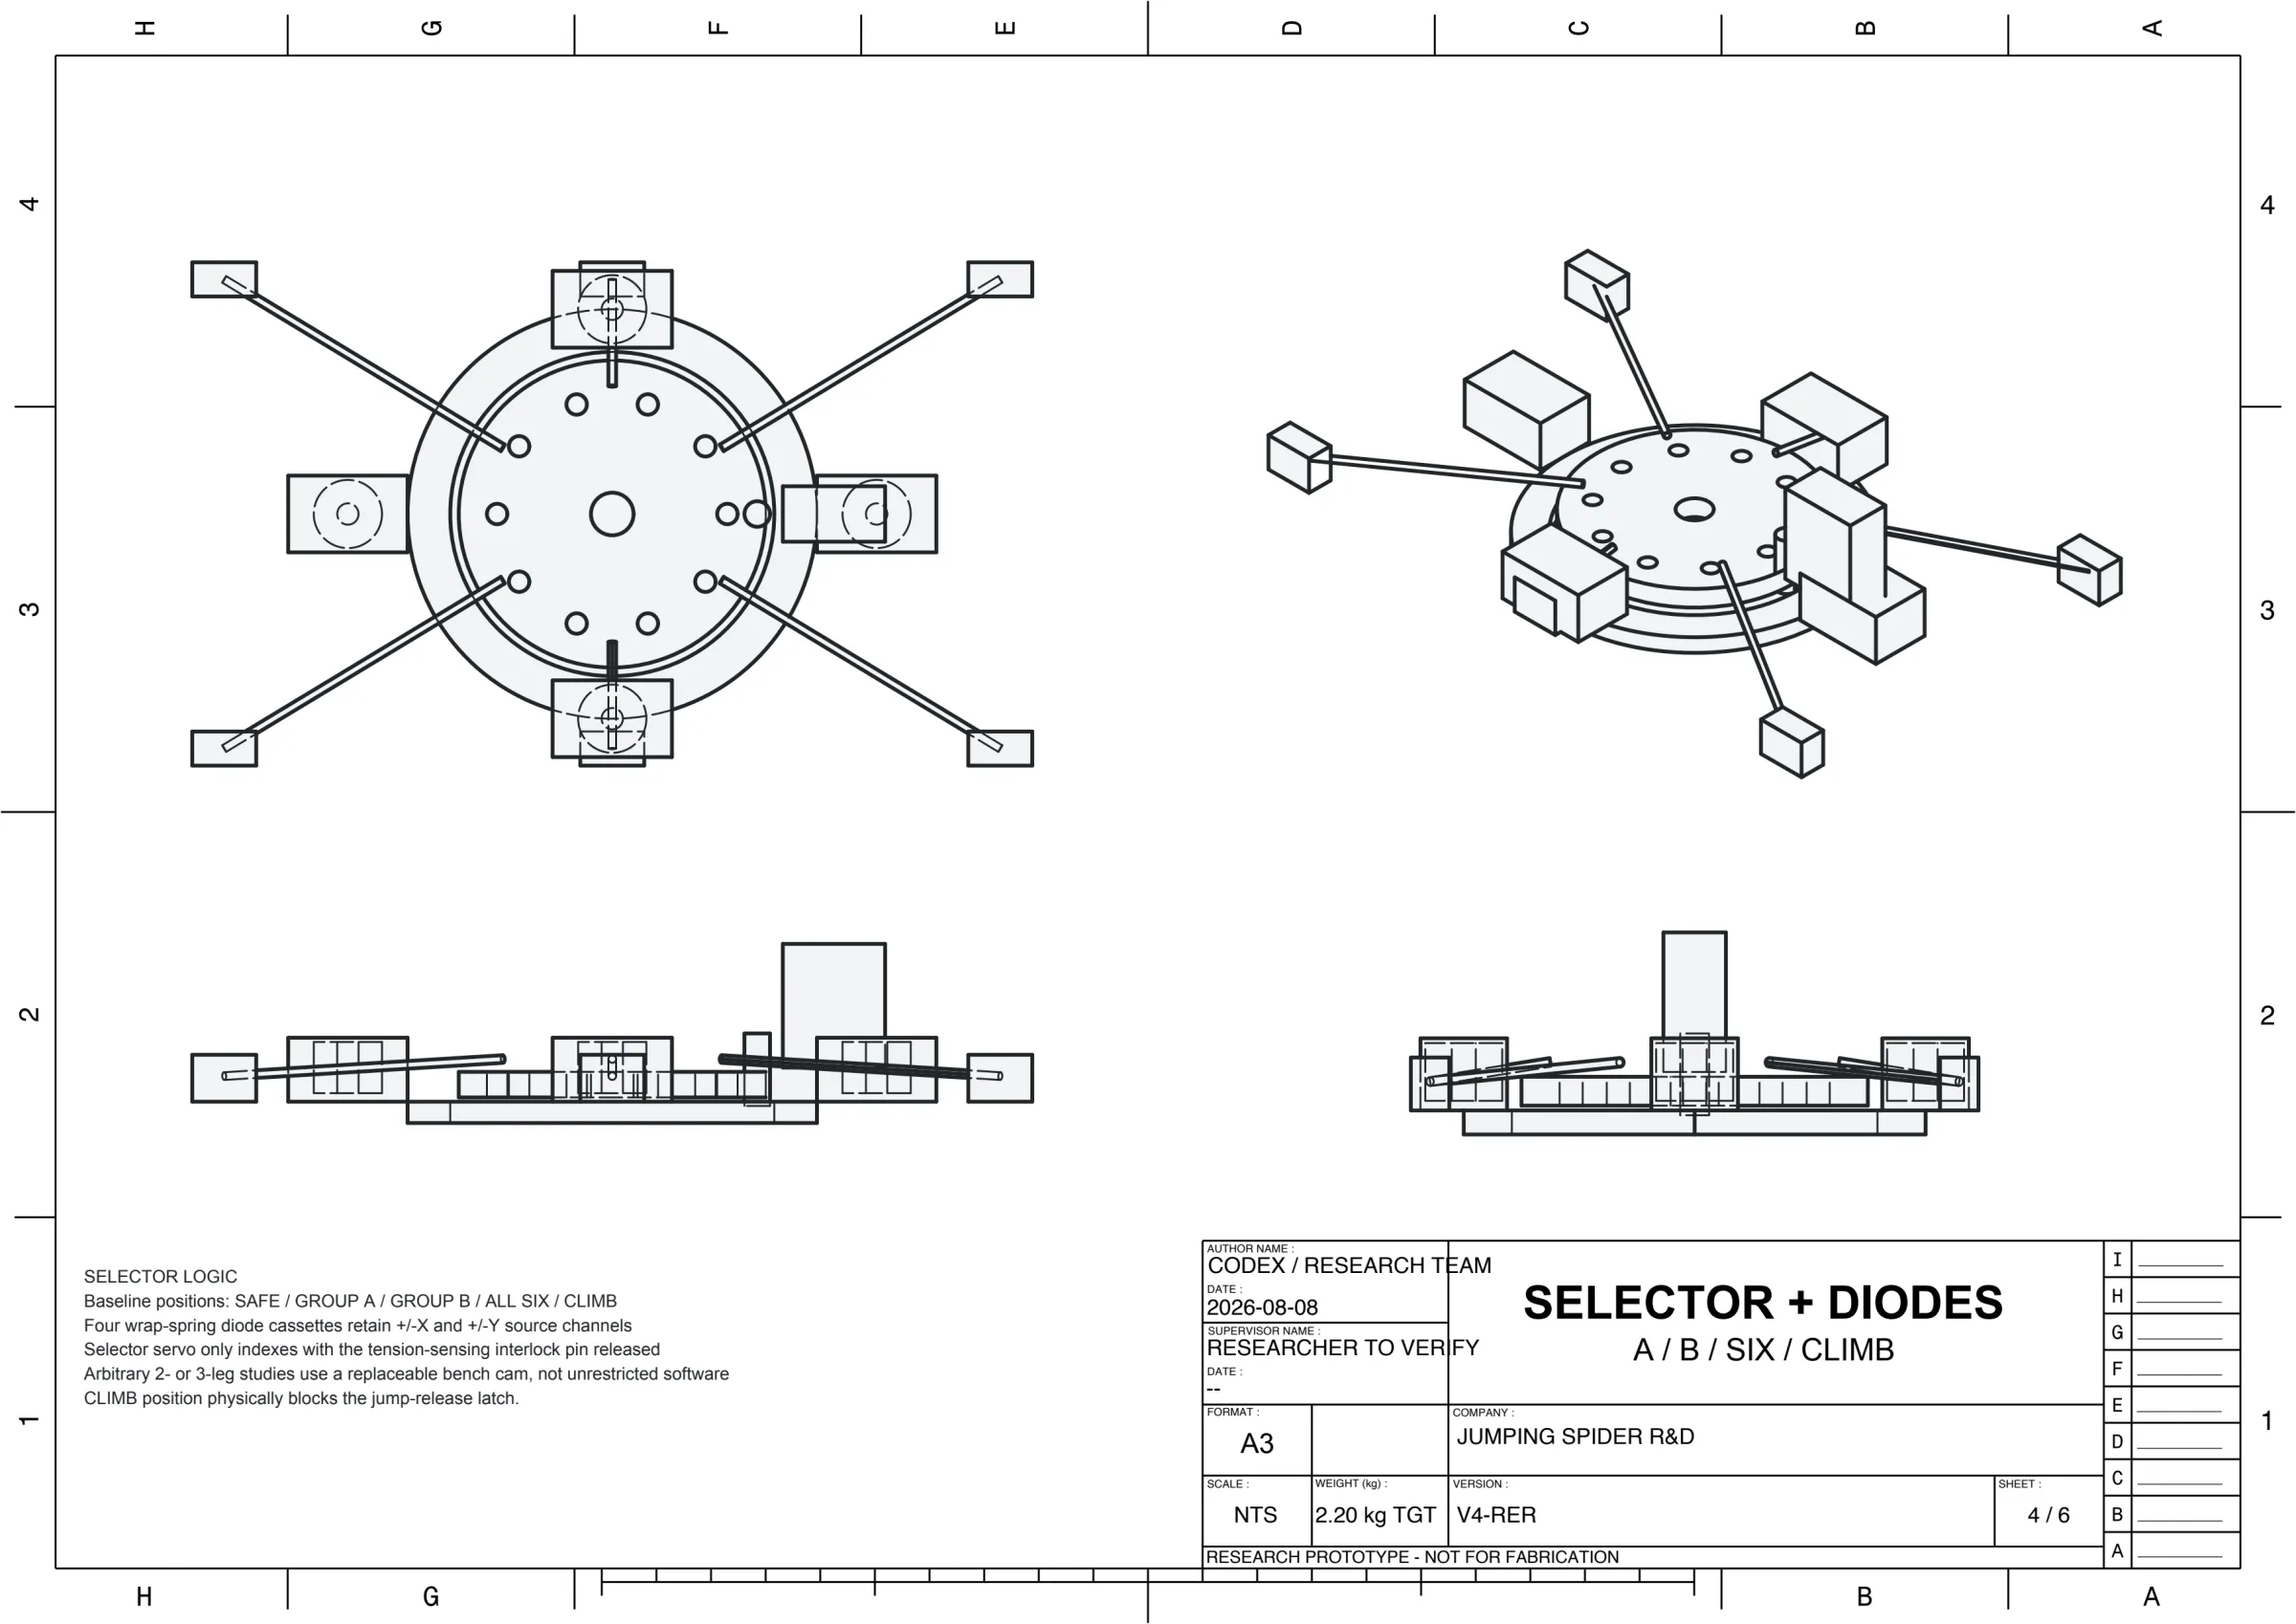
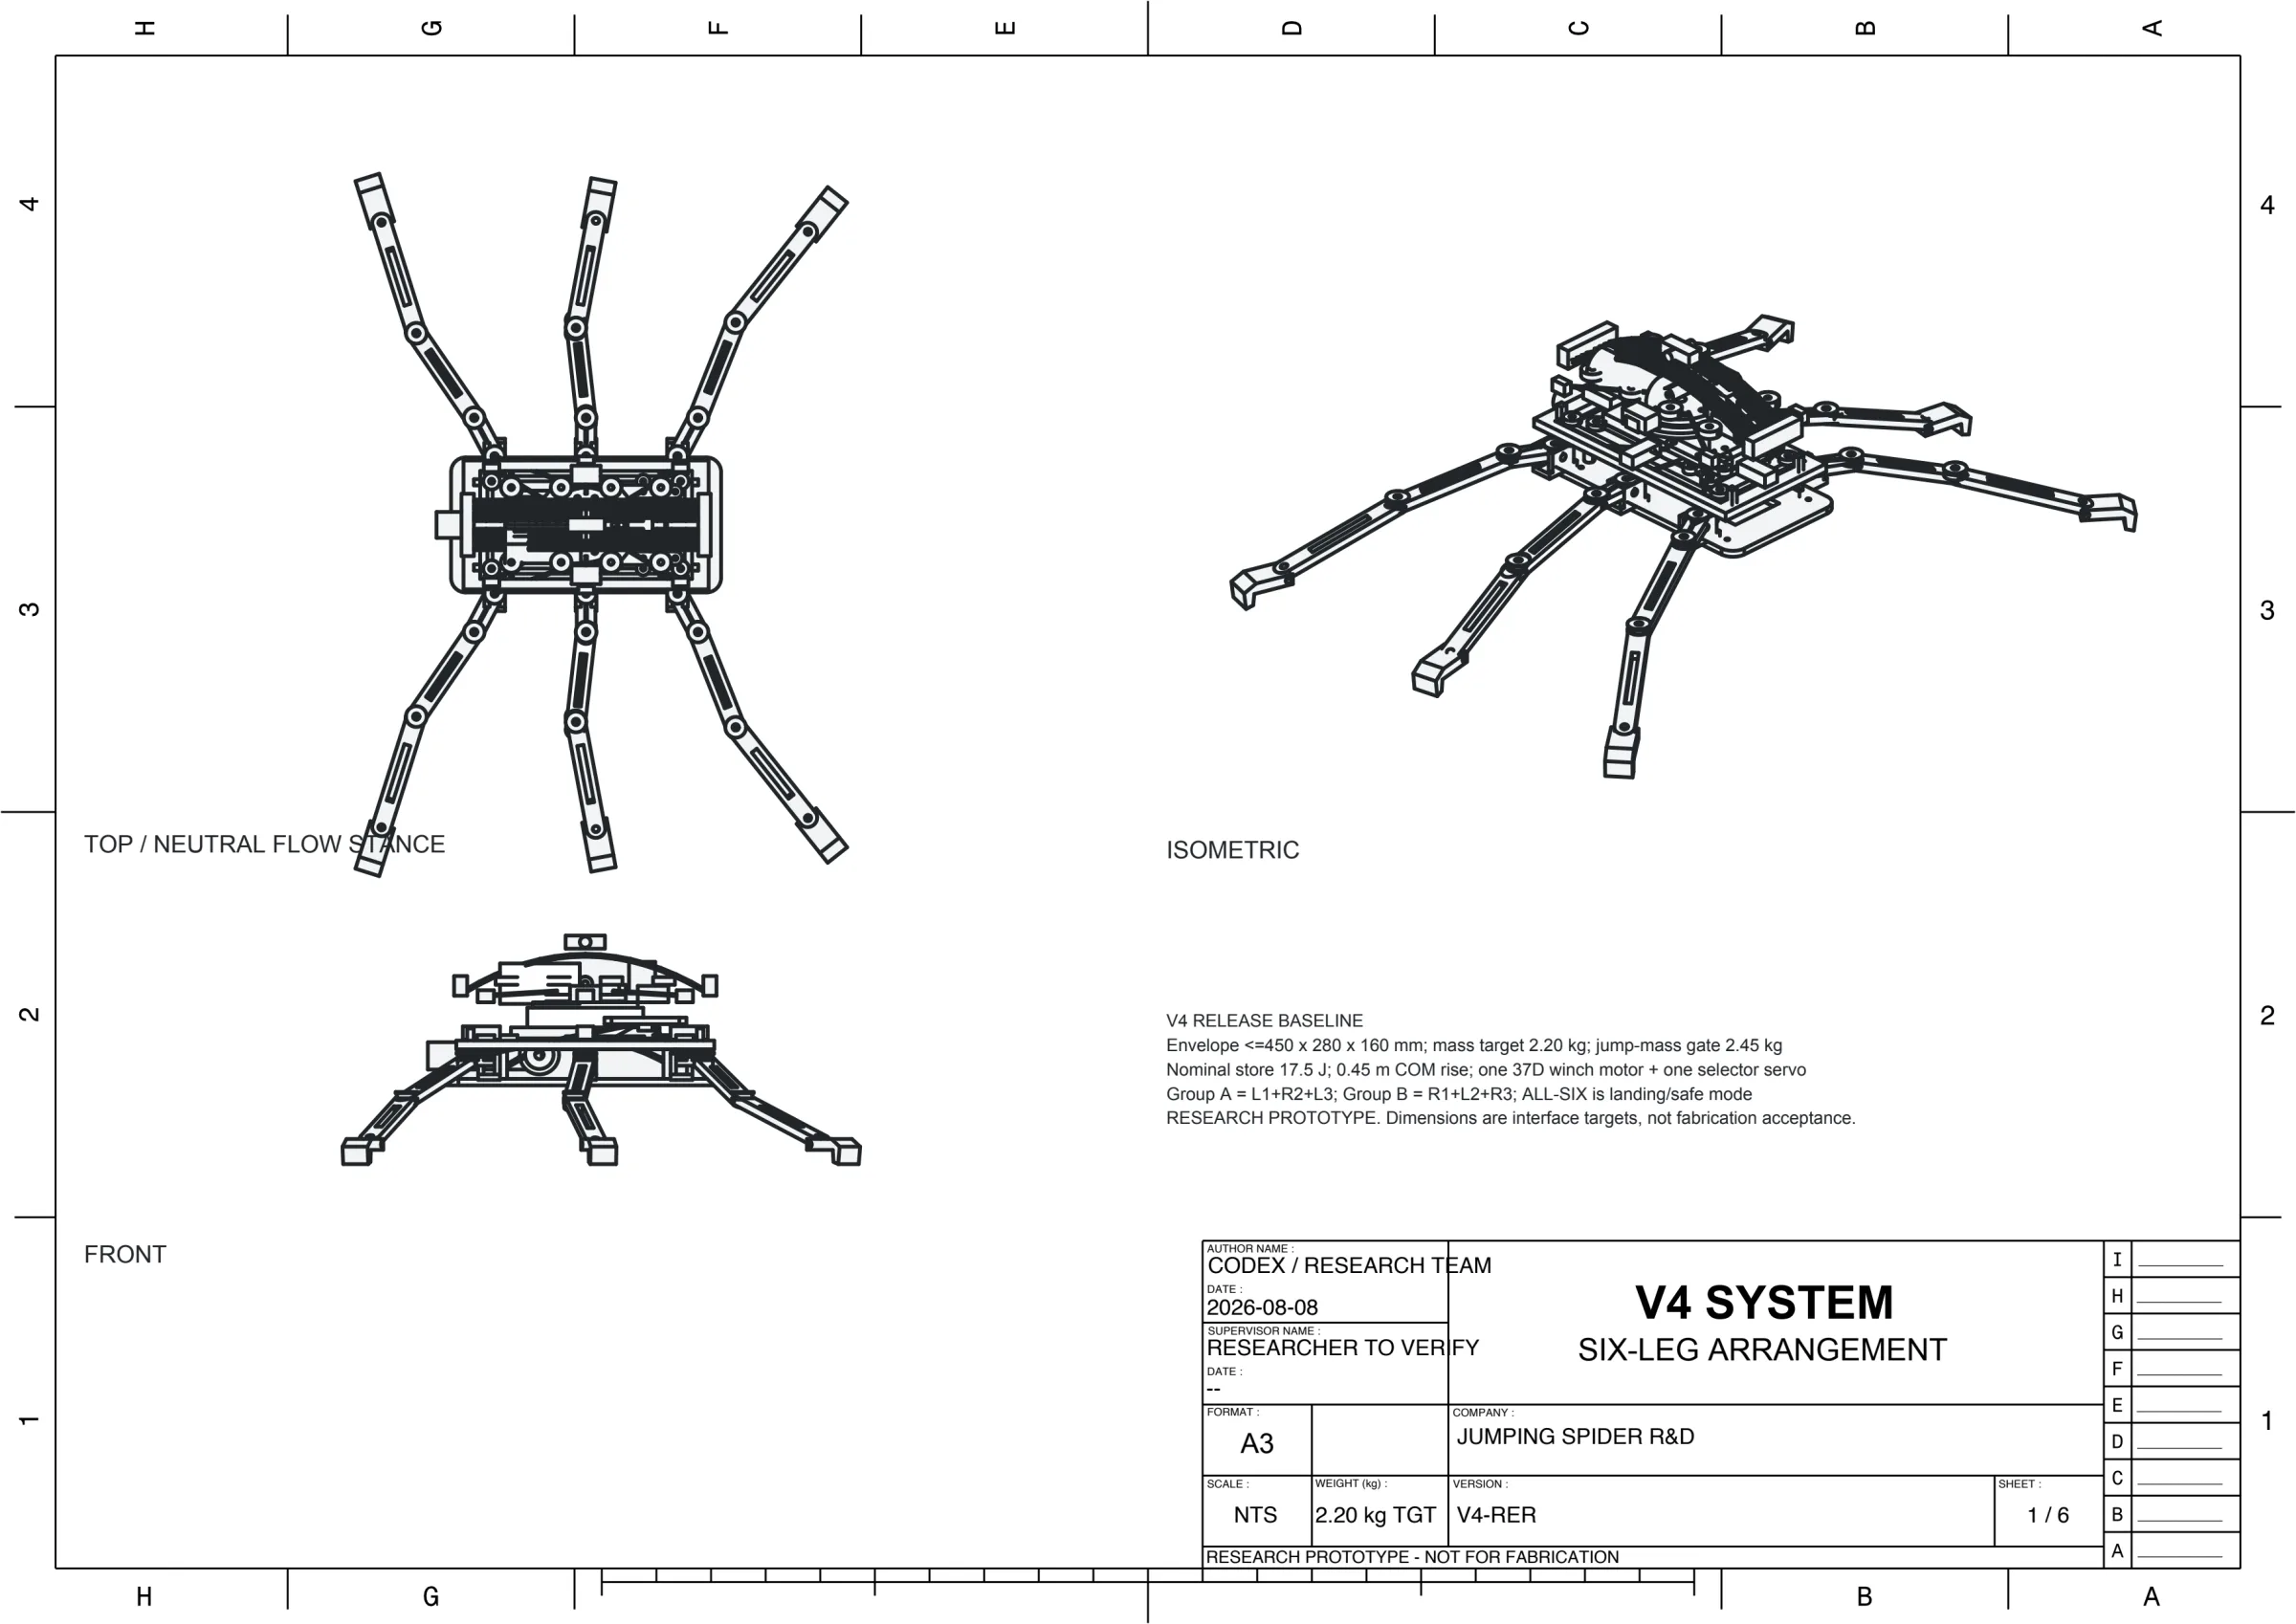
V4 engineering work packages: material characterization, nonlinear FEA, tolerance stack, fabrication approval, guarded proof testing, calibration and inventor acceptance.
Integration
Expose the capability. Keep control where it belongs.
SHEEPDOG keeps the Sense → Understand → Decide → Assign → Act → Assess loop and its evidence coherent across platforms. Flight, motion, actuation, and low-level safety remain with each vehicle and its approved control stack.
COMPANY · Archived research and engineering
Research and engineering records from the original program.
Why Baoqi Smart
The mission brain is the system.
Founder Wenteng Chang’s background spans semiconductors, networking, computer-vision products, product management, company building, and Taiwan’s hardware ecosystem. Across those fields, the recurring constraint is not one more machine—it is turning fragmented sensing into a shared mission picture, deciding which asset should act, dynamically re-tasking as reality changes, and preserving an explainable Decision Log and AAR.
Build sequence
Build the brain. Distill the reflex. Integrate the limbs.
Deterministic simulator
Capability-aware assignment, role leases, failure injection, safety gates, replay, and audit evidence.
Red–Blue AI Foundry
Generate, compete, select, verify, and distill robust scenario-specific policy candidates.
Edge integration
Autopilot integration, SIL, HIL, edge hardware, degraded links, and closed-field validation.
Heterogeneous demonstrator
Unify approved air, sea, and ground assets through capability passports and bounded role leases.
Evidence before claims
Software, hardware and network architecture.
SHEEPDOG
Executable simulator, benchmark, deterministic replay, and operator evidence.
Jumping Spider V4
System layout, STEP, TechDraw, BOM, and staged validation gates.
SKY MESH
Distributed-node architecture, mission models and cost comparisons for SKY MESH.
Mission workshop
Bring us a mission, not a shopping list.
We turn constraints into testable scenarios, minimum-feasible fleet questions, and measurable evidence.
USE-CASES · Archived research and engineering
Research and engineering records from the original program.
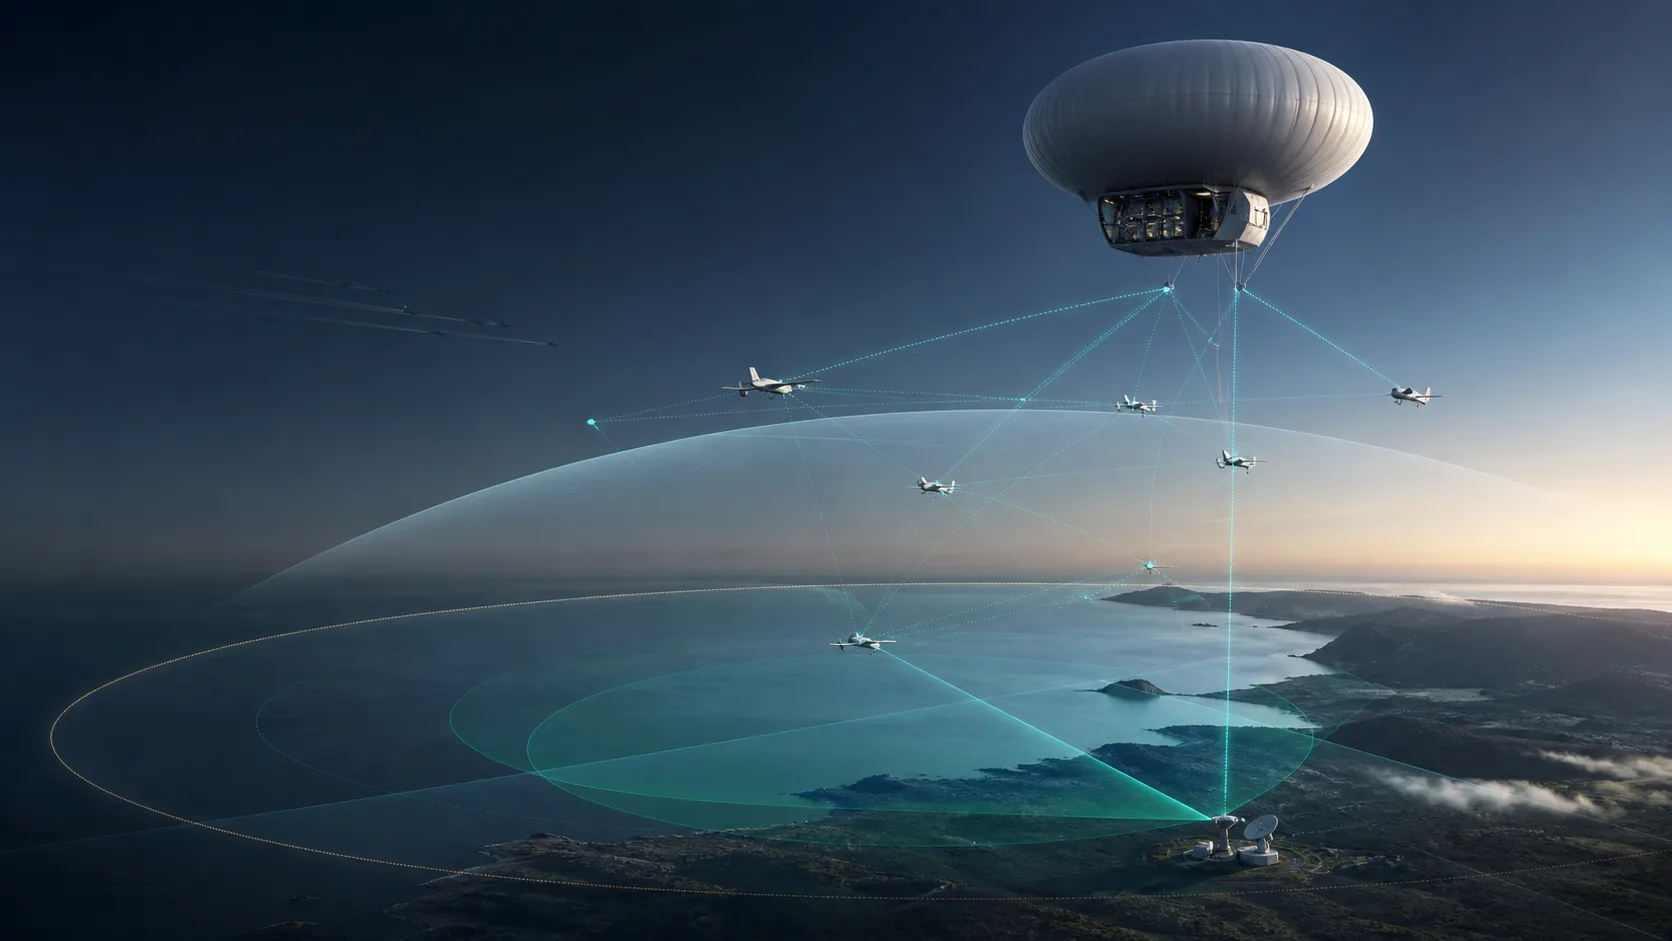
Layered airspace defense
Assign the right layer without spending every reserve.
Pre-position sensing and communications, classify the mission state, assign bounded roles, and recover when a node or link is lost.
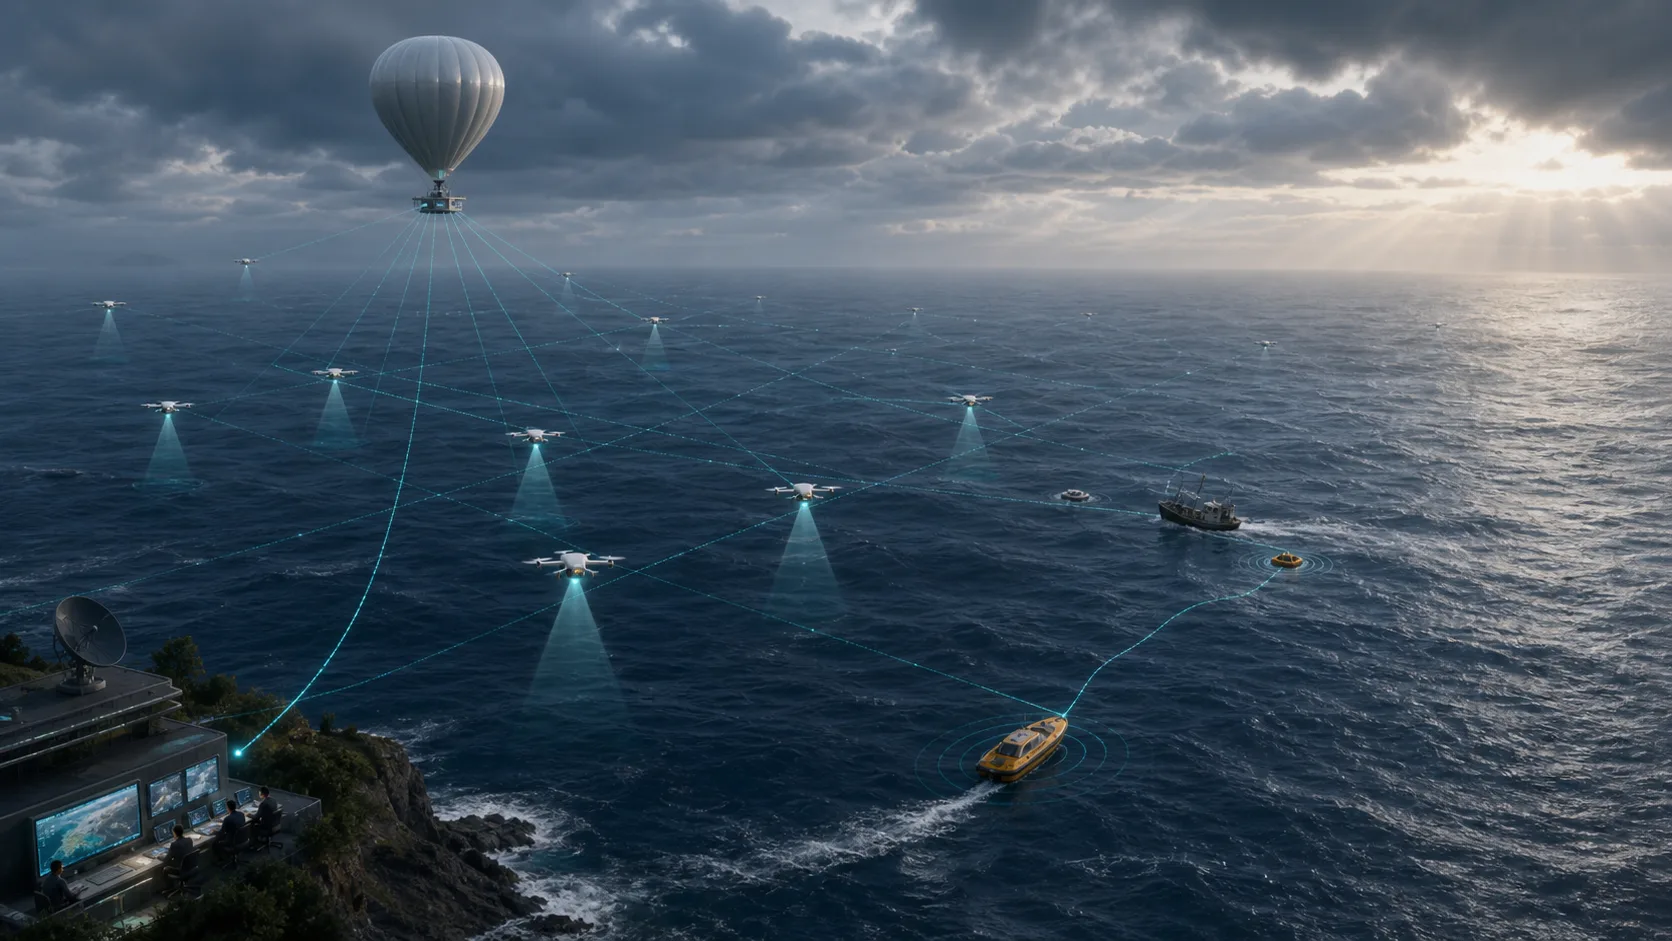
Maritime search and rescue
Turn a wide search area into coordinated evidence.
SKY MECH establishes the frame, UAVs divide the area into overlapping cells, detections are fused, and confirmed coordinates are handed to a USV or rescue team.
Urban search and rescue
Send the right sensor into the space the operator cannot enter.
UAVs map the exterior. A low-profile six-legged robot enters voids and unstable interiors, returning thermal, visual, location, communications, and health evidence.
Sensing and relay
Keep the mission picture alive when the network degrades.
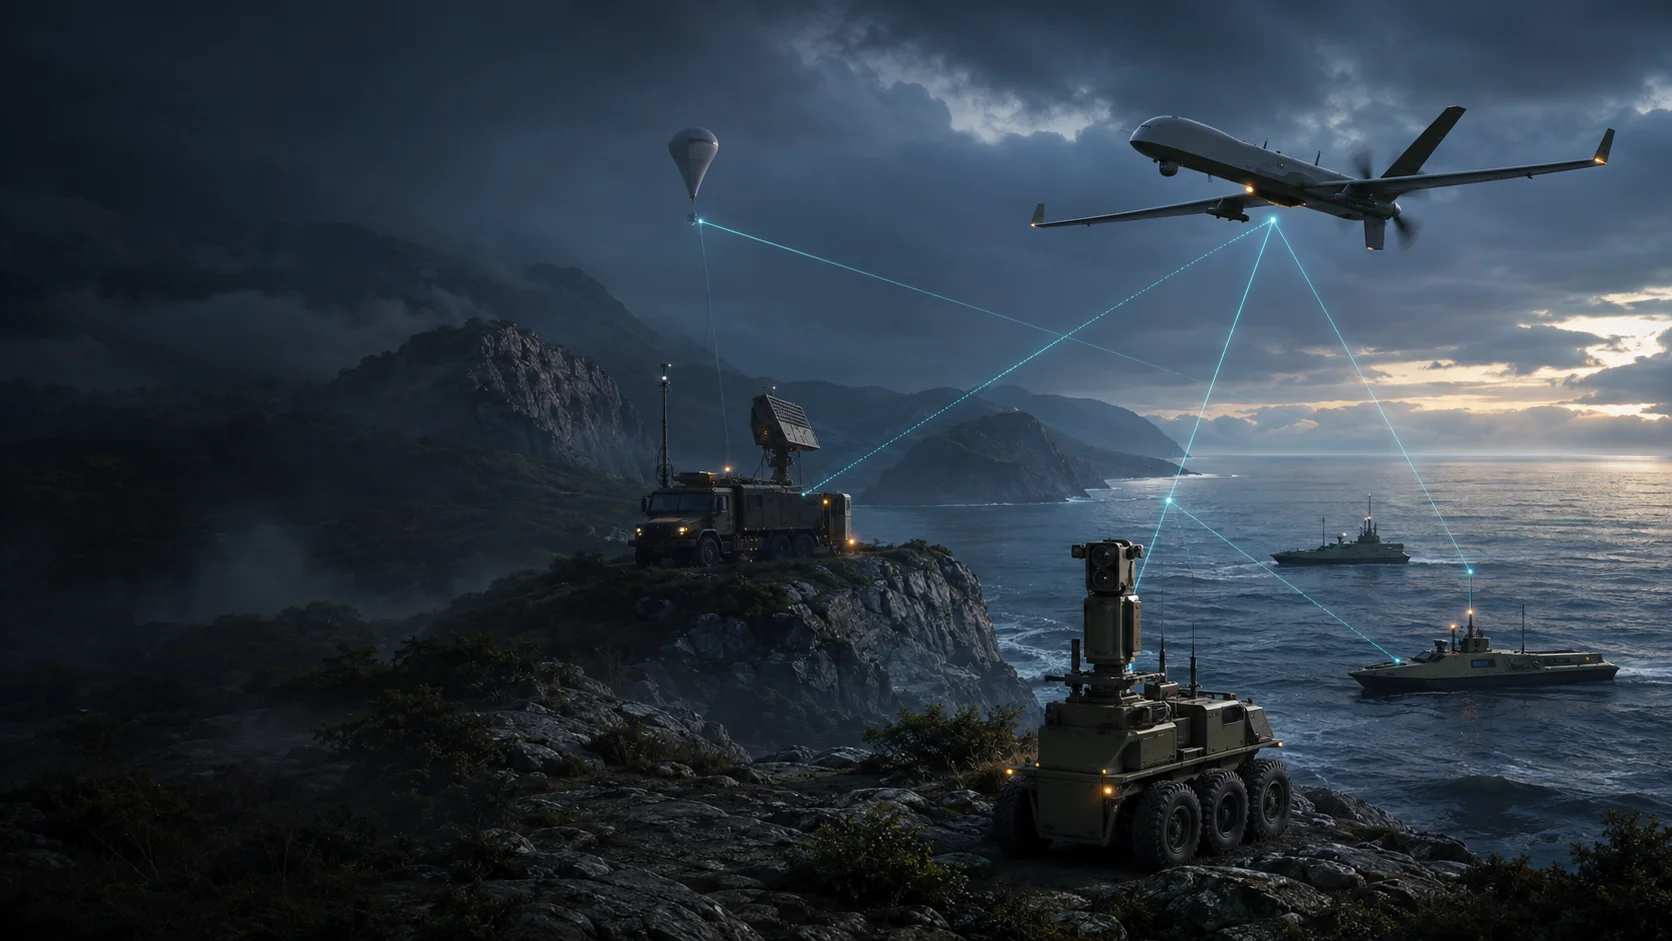
Communications, sensing, and positioning are mission roles. When one SKY MECH or relay weakens, another balloon, UAV, USV, or ground node can preserve the most valuable part of the mission picture.
Scenario workshop
What is the minimum fleet that still meets your gate?
Bring the mission objective, constraints, and failure cases. We will turn them into a deterministic scenario and measurable evidence.
ZH · Archived research and engineering
歷史研究與工程資料;各項計畫依原文標示的驗證階段解讀。
任務模型 · 從意圖到 Edge
一個任務,五個相互連結的決策。
在任何載具進入風險環境之前,SHEEPDOG 先把作戰意圖轉換成可看見、可重播、可檢驗的決策鏈。
→
→
→
→
實際產品 · 英文操作介面
同一套模擬器,兩種任務視角。
實際執行畫面
平面指揮視角
在同一個操作畫面中檢視精確航線、區域、KPI、機隊狀態與確定性重播證據。
空間任務視角
從即時模擬狀態呈現高度、地形、建物、視線條件與載具間距。
兩種視角都來自可運作的 SHEEPDOG 模擬器,並支援可重現的任務重播:2D 用於精密分析,3D 用於理解空間關係。
戰術模式資料庫
SHEEPDOG 在模擬中評估政策候選。
Defender AI Lab V0 以固定 RED 壓力案例測試確定性 BLUE 政策候選,分開記錄訓練與留出結果,輸出排名與 Model Card。大型模型候選生成與 Edge 政策驗證列為 Milestone 01。
轉移注意力,重新分配任務。
前方單元吸引對手投入,其餘團隊維持覆蓋、調整角色或完成主要目標。
塑造任務空間,關閉覆蓋缺口。
一個單元持續圍控,其他載具占據替代路線、補齊覆蓋缺口並保留復原能力。
把高度當成可運用的能量預算。
高空中繼節點釋放觀測滑翔載具,利用重力輔助飛行,同時評估曲線航路、鏈路連續性與穩定度。
稀缺感知任務編組 · 異質機隊
戰爭不會等待理想機隊到齊。
真正可用的,往往是不同廠牌、感測器、續航、鏈路與可信度的剩餘資產。SHEEPDOG 先識別每一架載具能做什麼,再依任務價值、成功機率、耗損風險與戰時替代成本進行編組、保留與重派。
面向戰時稀缺與異質機隊的無人載具任務編組:使用當下存在的能力、保留無法快速取代的資產,並讓每一次重新分派都可以被解釋。
AI 的剛性價值 · 可治理的協同優勢
不是把飛手換掉,而是把人類難以同步的協同變成可治理能力。
在 ALAYA 合成任務推演中,GO/NO-GO、暫停與返航由人員授權;多機情境呈現依規則重派角色、間隔與決策證據。風場、通訊、覆蓋、預備與成本由其他合成研究情境分別模擬。
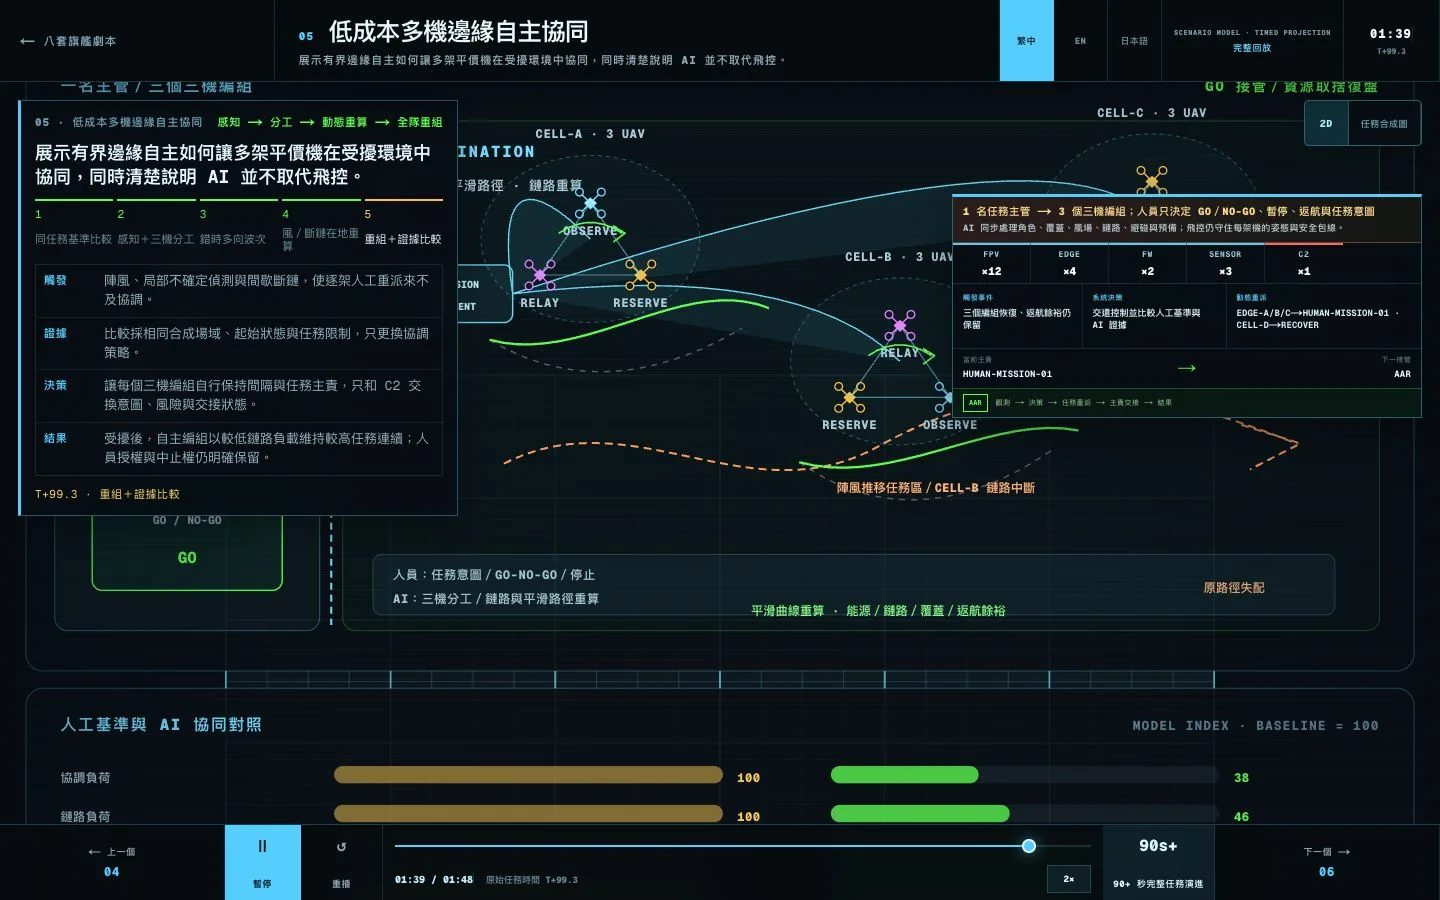
人員決定任務意圖;合成回放呈現角色重派與間隔。
既定情境以確定性規則重算角色分派與間隔狀態;載具端執行仍待整合與實測驗證。
發佈規格要求具名人員複核建議,並提供修正、退回與申訴流程;新策略升版前須通過留出驗證與回歸檢查。獎金、戰功與版本決策由人員授權。
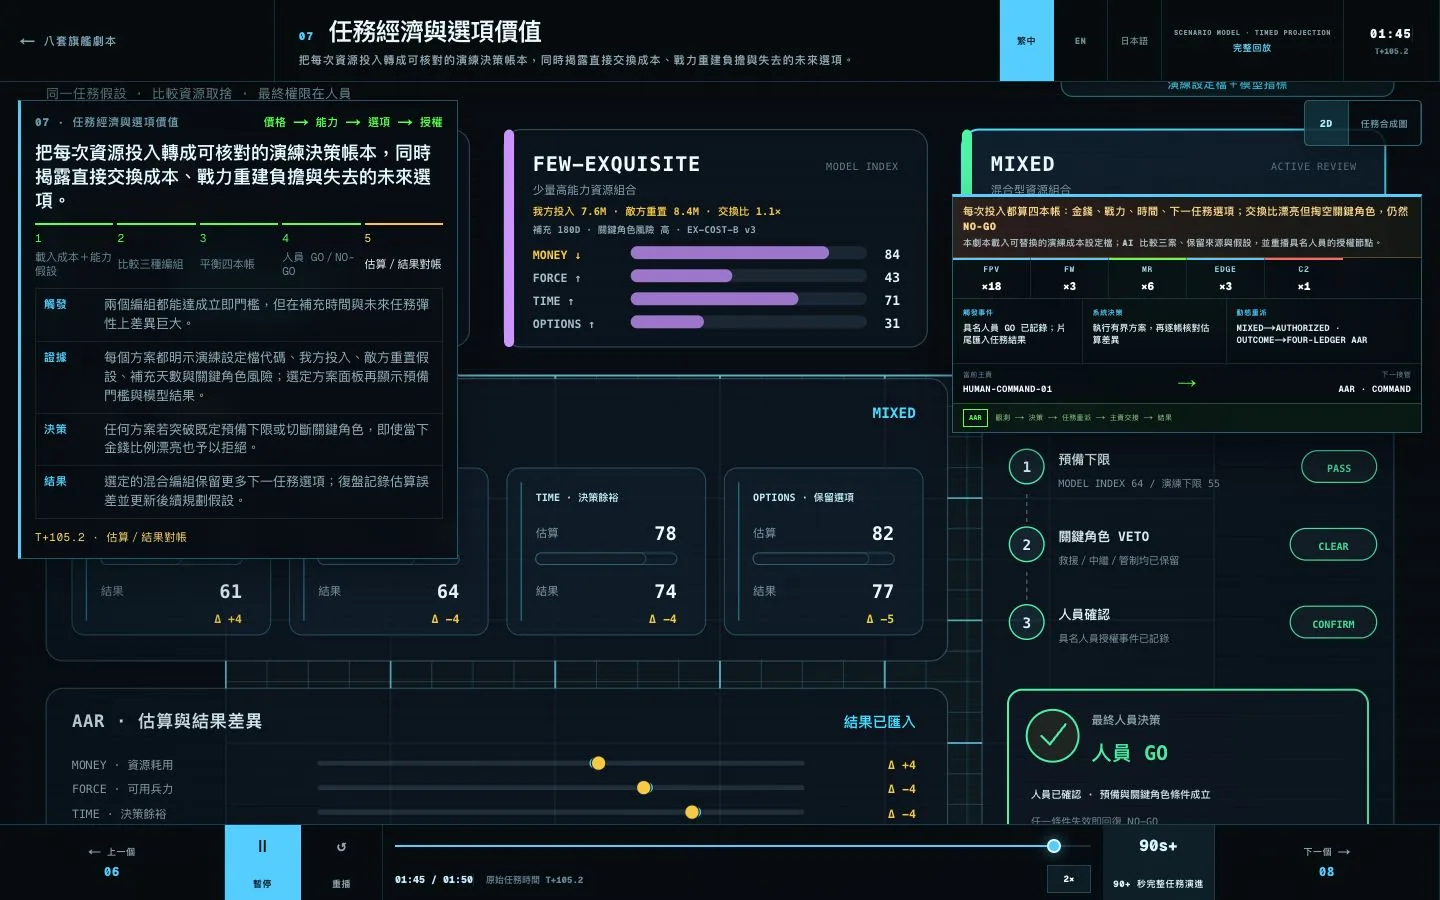
打完仗還要能打下一場。
同時核算金錢、戰力、重建時間與下一任務選項,辨識看似便宜卻掏空關鍵角色的方案,保留預備與中止選項後再交人員授權。
發佈規格要求具名人員複核成本與方案建議,並提供修正、退回與申訴流程;規則更新前須通過留出驗證與回歸檢查。獎金、戰功與版本決策由人員授權。
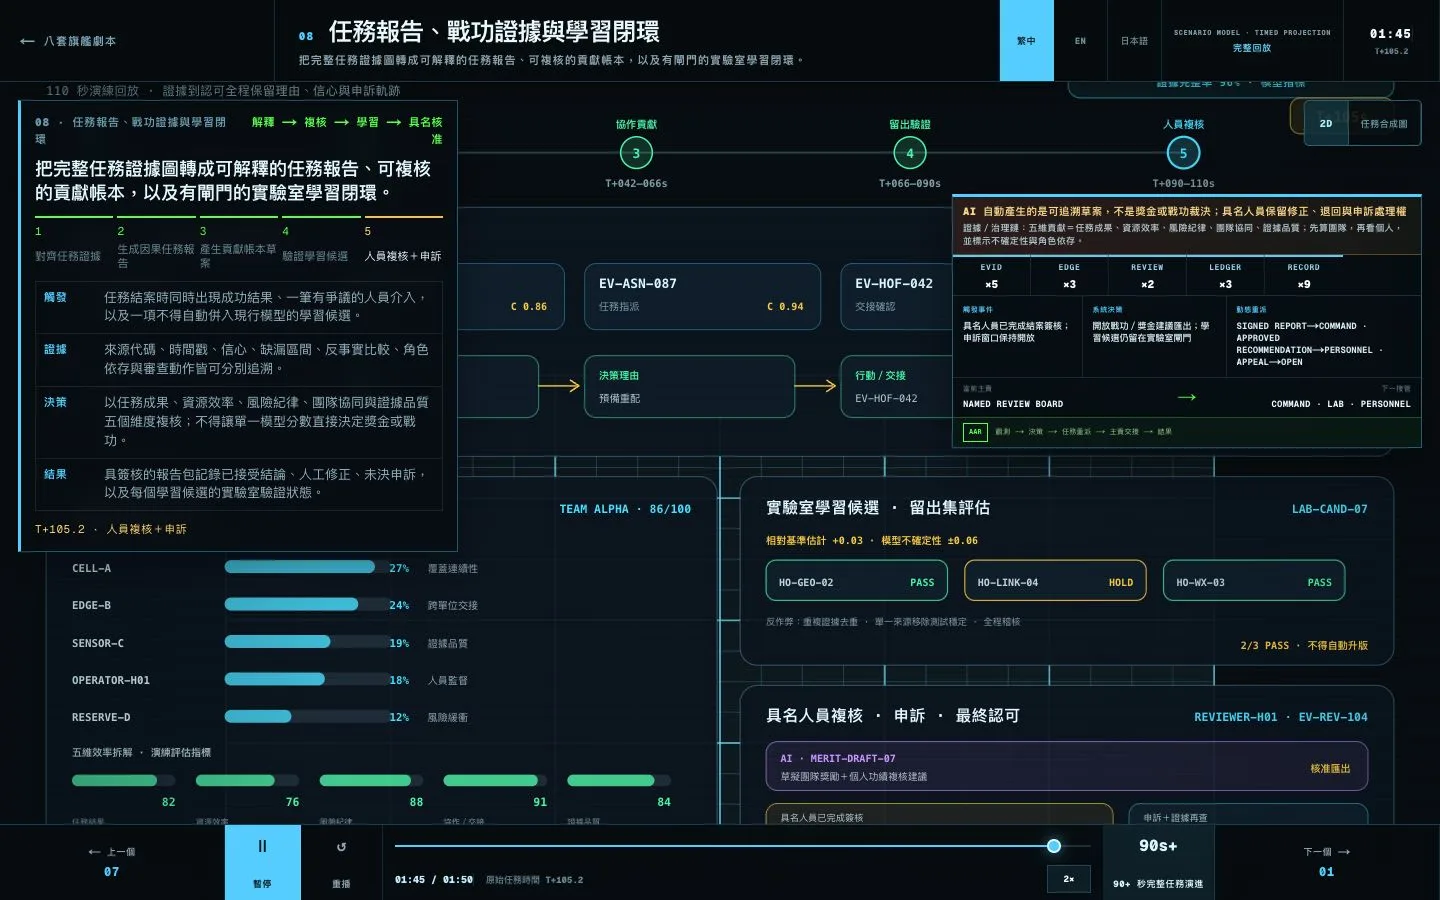
把每次決策變成可檢討、可申訴、可進化的證據。
自動對齊觀測、決策、重派、交接與結果,產生團隊優先的五維貢獻草案,並把學習候選隔離在實驗室治理閘門。
發佈規格要求具名人員複核報告與貢獻草案,並提供修正、退回與申訴流程;學習候選升版前須通過留出驗證與回歸檢查。獎金、戰功與版本決策由人員授權。
可執行證據
每一個成熟度關卡都有對應證據。
可運作軟體、可重現研究與工程釋出,以清楚的成熟度層級分別呈現。
EDTH TAIWAN 2026 · 協辦夥伴
寶淇智慧擔任 EDTH Taiwan 協辦與臺灣企業合作窗口。
本活動由 European Defense Tech Hub 與國立臺灣大學無人載具研發設計中心共同主辦,將於 2026 年 10 月 2–4 日在臺北舉行。寶淇智慧負責企業與產業合作協調、技術生態連結及合作材料整合。
ZERO × ALAYA × BABYLON: Turn resources into mission capability.
ZERO anticipates situations and compares options. ALAYA coordinates heterogeneous teams and turns mission outcomes into reusable experience. BABYLON composes platforms, components and supply options around the mission. Together, they connect prediction, coordination and configuration—so every mission strengthens the next.
Open the 10 mission demonstrations · Discuss a mission or platform integration